Related Experiment Video
Updated: Sep 27, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Feasibility Evaluation of a Novel Bilateral Hand and Finger Training Device in Patients with Hand Dysfunction: A
Gaku Watanabe1,2, Yukiyo Shimizu3, Kei Takehara1,2
1Doctoral Program in Medical Sciences, Graduate School of Comprehensive Human Sciences, University of Tsukuba, Tsukuba 305-8575, Ibaraki, Japan.

Abstract:
Background/Objectives: The Synchronized Hand Interface for Neurorehabilitation and Innovation (SHINI) is a mechanical device that uses voluntary movement of the unaffected or less affected upper limb to generate synchronized bilateral hand and finger movements without biological signal detection or electronic control. This exploratory study evaluated SHINI's technical operability and practical limitations during a single supervised session. Methods: Seven participants with hand dysfunction of varied etiologies attempted one 10 min session. Completion status was categorized as completed without therapist intervention, completed with therapist intervention, or not completed; no quantitative acceptability threshold was prespecified. Secondary outcomes were adverse events, overall perceived exertion and upper-limb fatigue assessed using the modified Borg Scale, exploratory pre- and post-session modified Ashworth Scale scores, and participant and therapist feedback. Results: Three participants (42.9%) completed the session without therapist intervention, three (42.9%) completed it with therapist intervention, and one (14.3%) did not complete it. Hand or forearm displacement affected four participants (57.1%), including the participant who discontinued. No adverse events occurred. Perceived exertion and upper-limb fatigue were generally low, no consistent direction of change in modified Ashworth Scale scores was observed, and feedback emphasized the need for improved fixation and adjustability. Conclusions: SHINI showed preliminary technical operability during a single supervised session, but the findings do not establish feasibility for independent or semi-supervised use. With improved fixation and adaptability, SHINI may offer a simple mechanical approach to repetitive bilateral hand training. Repeated-use studies are required to evaluate usability, safety, and clinical effectiveness.
More Related Videos
 03:55
A Flexible Wearable Supernumerary Robotic Limb for Chronic Stroke Patients
Published on: October 27, 2023
 07:34
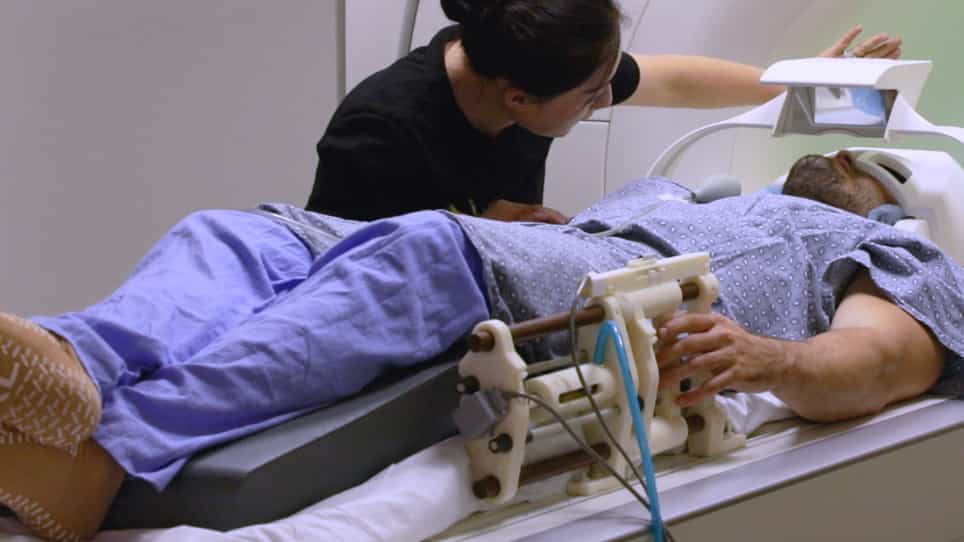
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019