Related Experiment Video
Updated: Sep 27, 2026


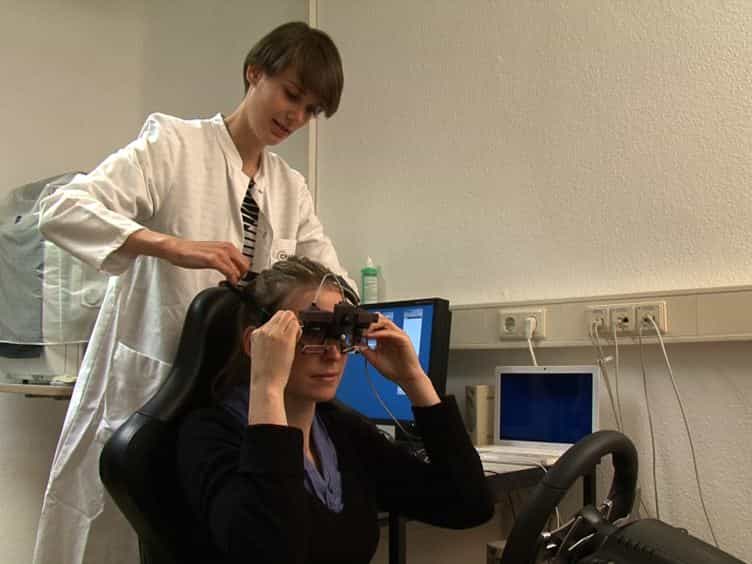
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Explaining Driver Behavior in Sim Racing with Shannon Entropy and LLM Feedback
Tomaz Nunes1, Morsinaldo Medeiros1, Marianne Silva2
1Graduate Program in Electrical and Computer Engineering, Federal University of Rio Grande do Norte, Natal 59078-970, Brazil.

Abstract:
In some scenarios, motorsport simulators have been used to enable the controlled acquisition of dense telemetry with high similarity to real-world data, reducing cost when assessing driving performance. However, although popular, performance analyses traditionally treat human control as deterministic and overlook the stochasticity of driving behavior. In fact, existing coaching methods which improve driving performance have to deal with two distinct outcomes: a driver who restructures his race control strategy and a driver who merely repeats it faster. This article presents a Behavior-First framework for interpretable driver behavior analysis that separates them. We characterize control signals with two information-theoretic descriptors: Jensen-Shannon divergence, which quantifies distributional distance from a proficiency-matched reference and whose square root satisfies the triangle inequality, and Permutation Entropy to measure the ordinal complexity of the input sequence. A deterministic, physics-informed heuristic layer then identifies kinematic performance gaps and emits structured tokens that a Large Language Model translates into natural-language coaching narratives. We evaluated the framework in an exploratory case study. The three beginners who received generated coaching messages and the single uncoached comparison participant exhibited different lap-time and information-theoretic trajectories. Because the groups were small and non-randomized, these observations describe within-driver evolution and do not estimate a causal coaching effect.
More Related Videos

Related Concept Videos
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:30
Introduction to Limits
 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:19
Root-Locus Method
This system can be represented by a block diagram,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...