Related Experiment Video
Updated: Sep 28, 2026
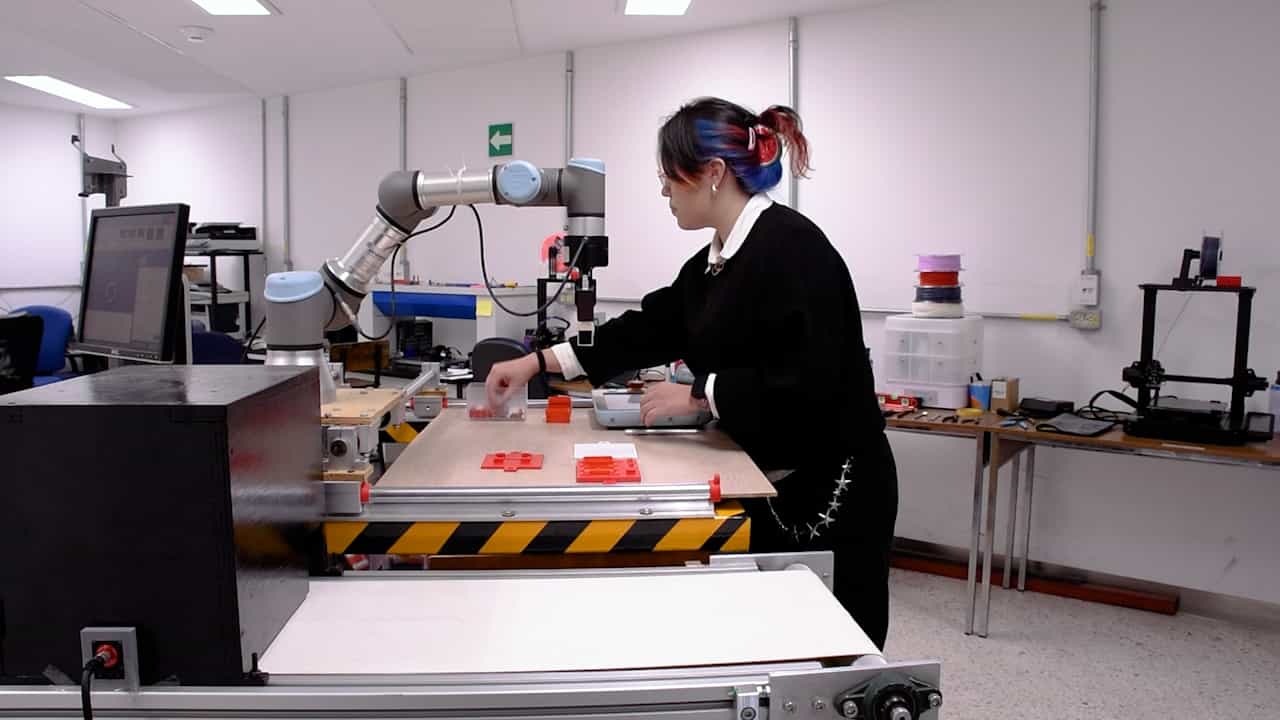

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Research on Optimization and Dynamic Environment Adaptation of Intelligent Robot Inspection System Based on
1College of Mechanical and Transportation Engineering, China University of Petroleum (Beijing); penghe@cup.edu.cn.

Abstract:
This paper proposes an optimization framework based on multi-sensor deep fusion and adaptive decision-making for intelligent inspection robots, addressing limited perception reliability, low path-planning efficiency, and poor environmental adaptability in dynamic scenarios. The robot platform is equipped with LiDAR, a vision camera, an infrared thermal imager, and an IMU to build a robust perception model for obstacle recognition and pose estimation. We designed a dynamic weight-DWA fusion algorithm for path planning and an online learning module to update environmental features. Multiple tests are conducted in industrial plants and substations under varying lighting conditions and in the presence of moving obstacles. Compared with baseline methods, including the Kalman filter, DNN, and A*+DWA, the system achieves a positioning error of ±1.5 cm, a 98.7% obstacle recognition rate, and a replanning delay of below 0.8 s, with 32% higher inspection efficiency and 9.8% lower energy consumption (p < 0.01). The system delivers improved robustness under the tested dynamic industrial conditions.
