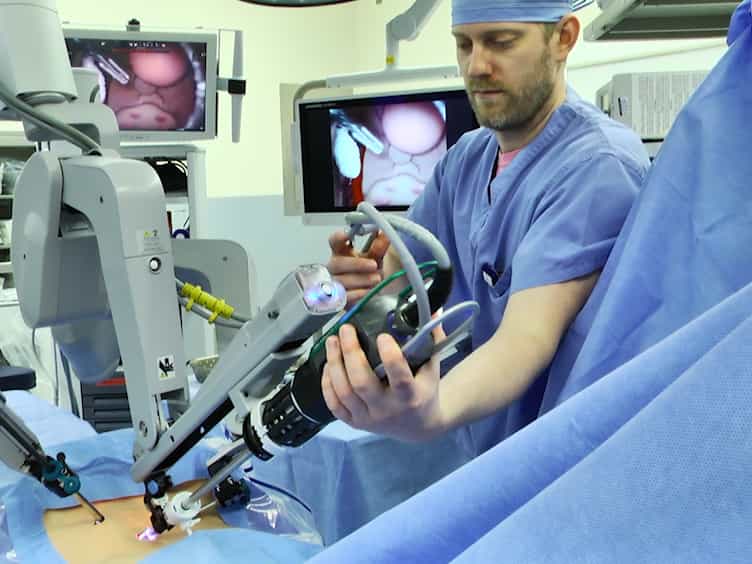
Related Experiment Video
Updated: Sep 30, 2026


Automatic Surgery in Transcatheter Aortic Valve Replacement Using Augmented Reality
Published on: August 9, 2024
An Expertise Transfer Framework For Autonomous Surgical Assistance
Yuan Gao1,2,3, Guangdi Chu4, Wei Jiao4
1Institute of Medical Robotics and Intelligent Systems, Tianjin University, Tianjin, China.

Abstract:
Autonomous surgery holds the potential to transform operative practice by enhancing procedural safety and consistency. While substantial progress has been made on episodic sub-tasks, achieving autonomy for long-horizon tasks that span the entire procedure remains challenging. Current logic-based heuristics and end-to-end learning approaches, though effective for short-term actions, struggle to adapt to the evolving dynamics of complete surgical workflows. To address this gap, an expertise transfer framework is introduced to achieve procedure-spanning autonomous view assistance by emulating expert logic. Specifically, the framework instantiates situational awareness via a novel hierarchical granularity perception network that jointly captures surgical workflow and fine-grained instrument-tissue interactions; models attention allocation for inferring assistance needs by systematically characterizing surgeon visual attention patterns; and encodes decision-making logic for actionable behaviors by formalizing expert assistance policies as a heterogeneous knowledge graph. Equipped with this architecture, the proposed framework successfully enables autonomous view assistance in vivo animal trials throughout complete nephrectomy procedures, while demonstrating improved visualization quality compared to human assistance. This expertise transfer paradigm provides a promising pathway toward trustworthy autonomy in clinical applications, advancing the shift toward procedure-spanning autonomous workflows.