Related Experiment Video
Updated: Sep 30, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
Take-off and landing techniques in snowboard halfpipe based on inertial measurement units and kinematics analysis
Jinglun Yu1,2,3, Qi Li3, Shengnian Zhang3
1School of Exercise and Health Sciences, Xi'an Physical Education University, Xi'an, China.

Background:
The unique characteristics of snowboard halfpipe projects present a research challenge. Inertial measurement units (IMUs) show promise in addressing the prevailing research problems due to their numerous advantages. This study aims to explore the key technical characteristics of the take-off and landing phases in snowboard halfpipe to analyse the key factors that affect the take-off quality and landing stability of athletes at different sport levels.
Methods:
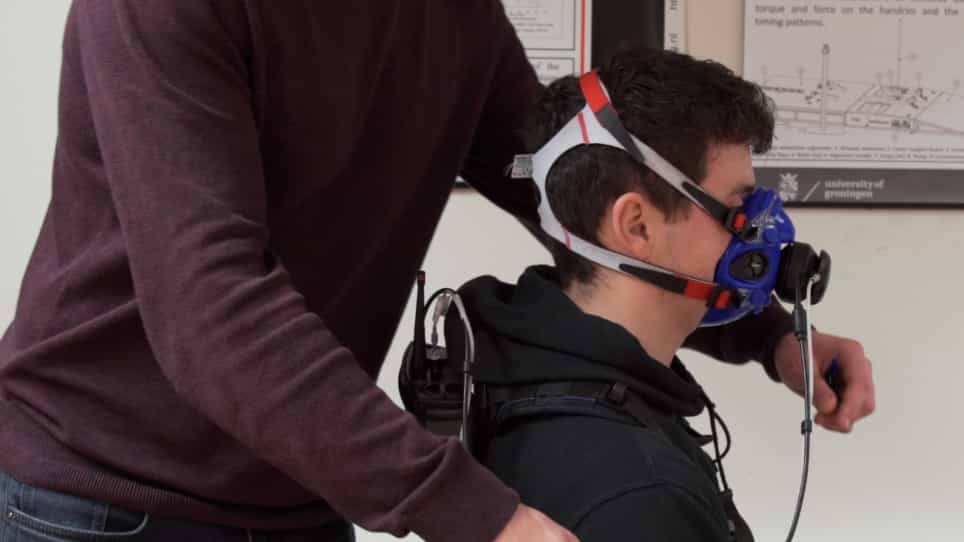
The study used an IMU-based motion capture system combined with high-speed video recording (via Xsens and Fastcam Mini WX100 high-speed cameras) to collect kinematic data from halfpipe snowboarders during their movement process.
Results:
The elite athletes reached the vertical position at approximately 50% of the normalized take-off phase, compared with approximately 60% in novice athletes. The overall speeds achieved by the elite athletes were greater than those of the novice athletes. The elite group demonstrated a lower flexion range of motion and a stiffer landing pattern than the novice group.
Conclusion:
These findings suggest that snowboard halfpipe performance may depend on the coordinated control of take-off timing, snowboard inclination, and landing posture.

Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:15
Determination of Pi Terms
The theorem indicates that the number...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:28
Trigonometric Identities II
 01:30
Derivatives of Inverse Trigonometric Functions
 01:26
Kinematic Equations - I