Related Experiment Videos
Transfer learning-based safe Q-learning for discrete-time nonlinear systems with asymmetric state constraints
Jiaoyuan Chen1, Minglei Zhu2, Shijie Song2
1University of Electronic Science and Technology of China, No. 2006, Xiyuan Avenue, West Hi-Tech Zone, Chengdu, Sichuan, 611731, China.

Abstract:
This article investigates the problem of safe control for discrete-time (DT) nonlinear systems subject to asymmetric state constraints. A novel transfer learning-based safe Q-learning (TL-SQL) algorithm is developed within the adaptive dynamic programming (ADP) framework. To support the proposed TL-SQL algorithm, a novel revived transformation formulation for DT systems is derived, serving as the basis for transferring control policies from unconstrained source systems to constrained target systems. Building upon this foundation, the proposed TL-SQL algorithm improves policy transfer under asymmetric constraints in three aspects. Firstly, unlike traditional state transformation methods, the revived transformation alleviates the adverse impact of state transformation on the optimality of the original system. Secondly, compared with control-barrier-function-based approaches, it avoids complicating the utility function structure. Thirdly, by decoupling policy training from constraint handling, it enables efficient adaptation to changing constraints without retraining. Theoretical analysis ensures stability and safety of the transferred policy. Simulation results validate the effectiveness of TL-SQL under asymmetric constraint scenarios.
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
State Space Representation
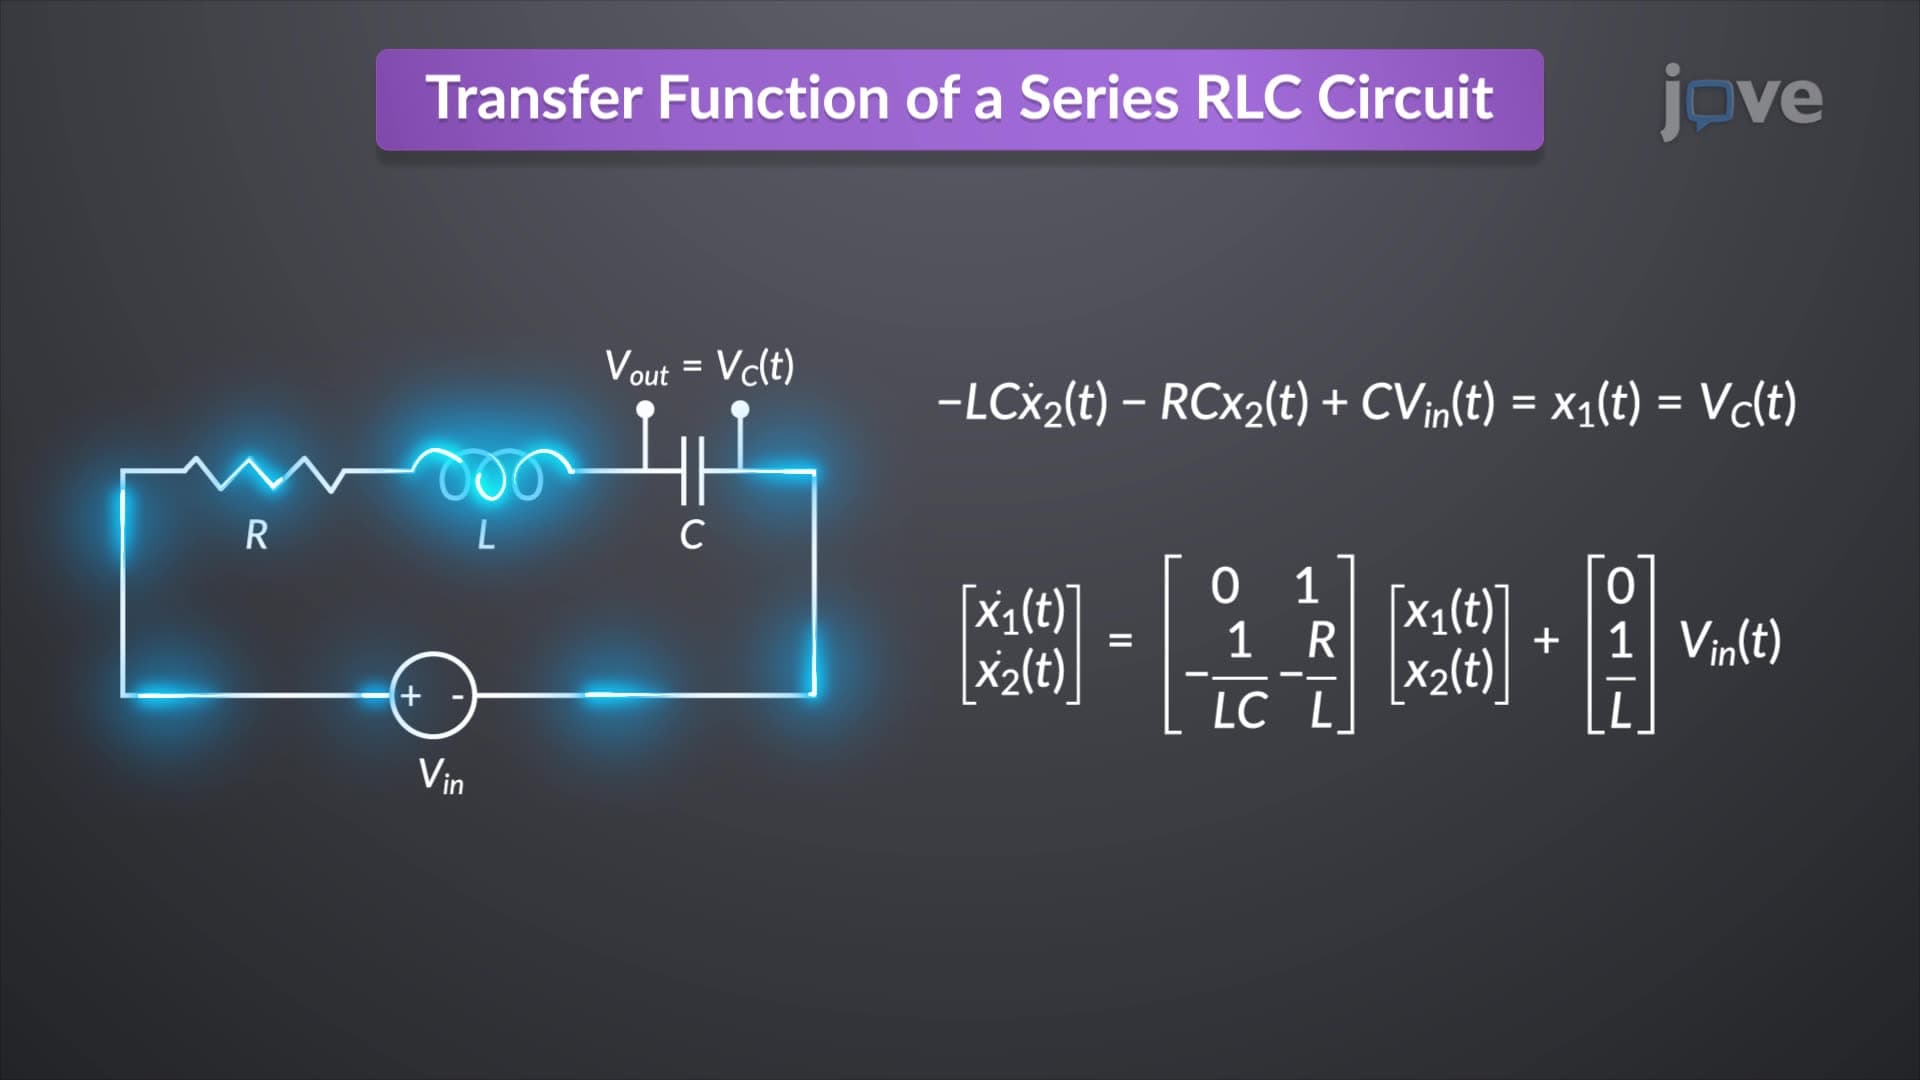
Consider an RLC circuit, a...
 01:23
Transfer Function to State Space
In an RLC...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
State Space to Transfer Function
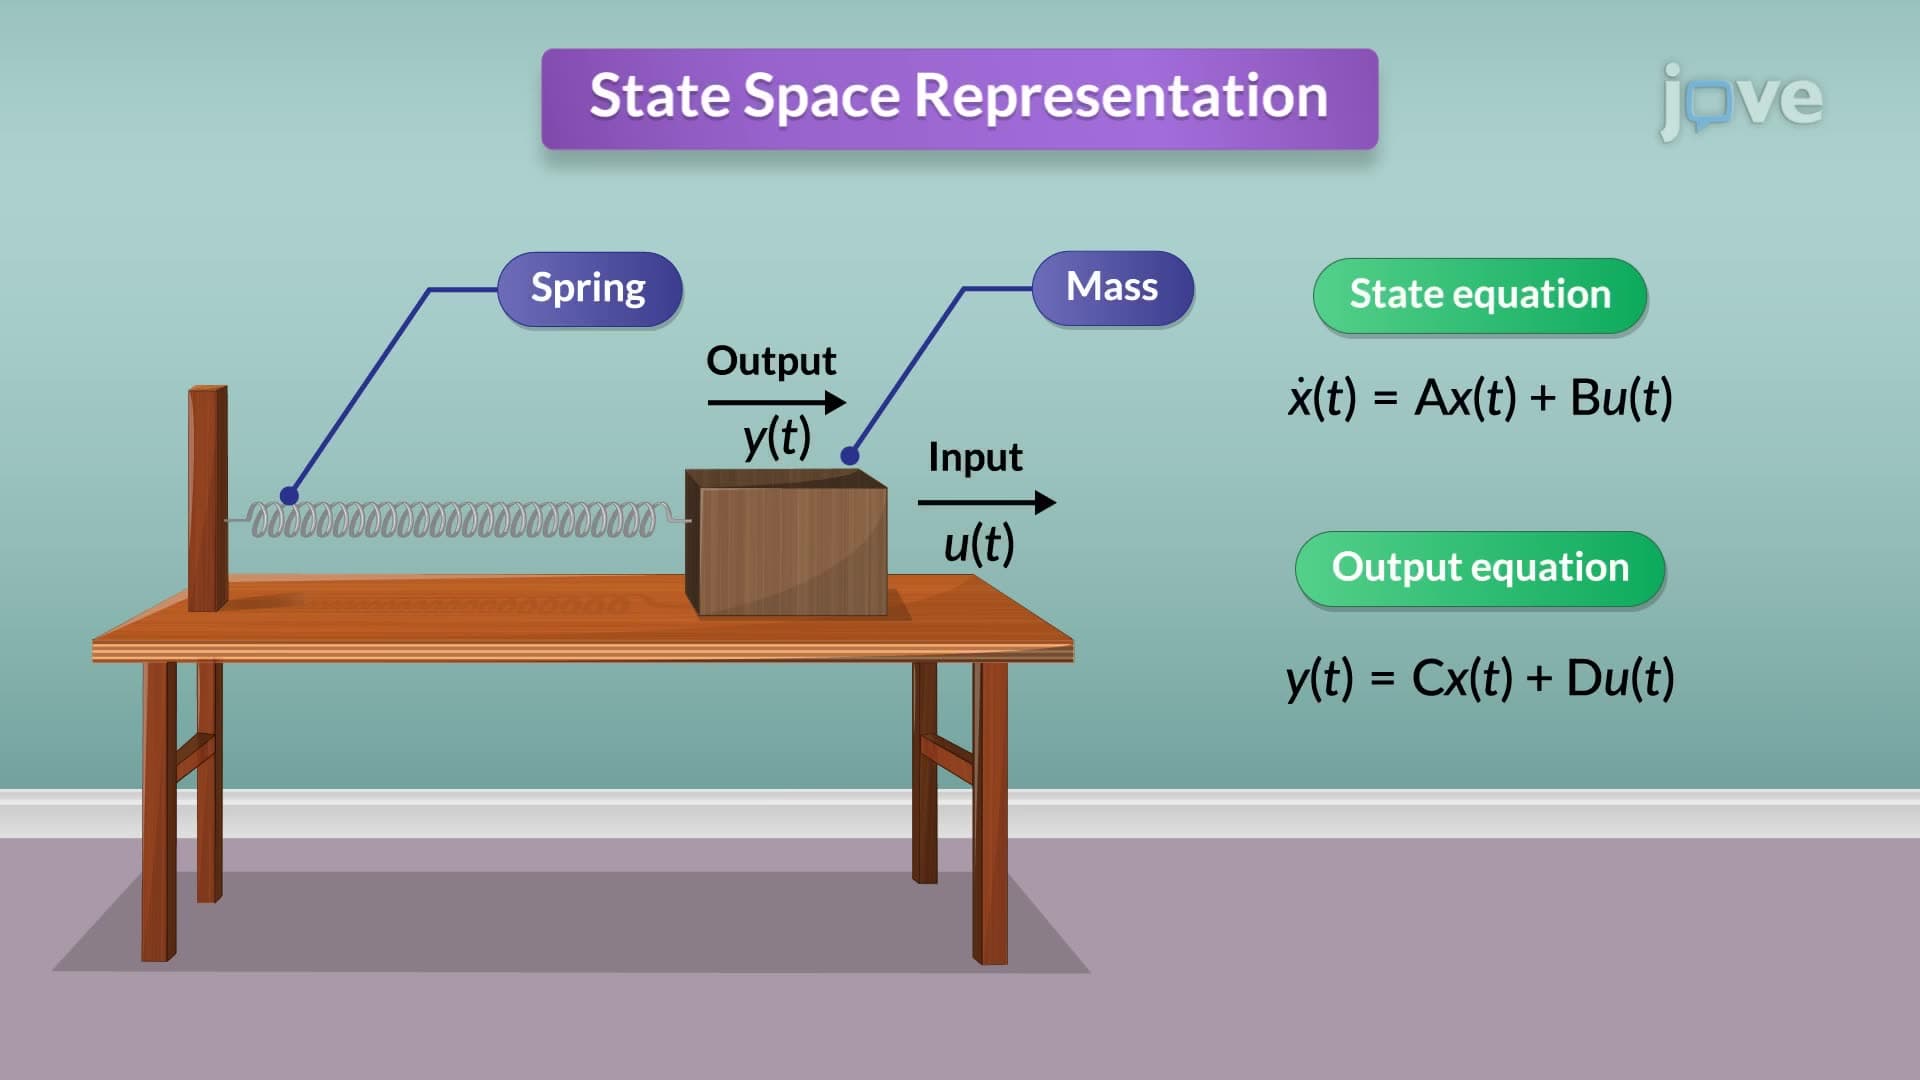
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: