Related Experiment Video
Updated: Oct 2, 2026

Method to Measure Tone of Axial and Proximal Muscle
Published on: December 14, 2011
Same geometry, different dynamics: what uncontrolled manifold (UCM) analysis misses about motor control
Madhur Mangalam1, Nick Stergiou2,3
1Department of Biomechanics, University of Nebraska at Omaha, Omaha, 68182, USA. mmangalam@unomaha.edu.

Abstract:
Uncontrolled Manifold (UCM) analysis separates the variability of multi-joint motion into a part that affects the task goal (task-relevant) and a part that does not (task-irrelevant), using the geometric relationship-the task Jacobian-between joint motion and task outcome. The resulting partition has been interpreted as evidence of neural control strategies that stabilize task goals while permitting flexibility in execution. UCM is conventionally reported as time-averaged variance indices, and this time-averaging step discards the temporal structure of movement variability. Using a three-joint planar reaching model, we generate variability with three temporal structures (periodic oscillation, white noise, and pink noise) matched in spatial covariance, and find that the time-averaged geometric indices-the ratio [Formula: see text] and the [Formula: see text]-transformed synergy index [Formula: see text]-remain statistically indistinguishable for white and pink noise, whereas temporal indices computed on the same trials (lag-1 autocorrelation, detrended-fluctuation scaling, spectral slope) show large effect sizes. This double dissociation confirms that time-averaged summaries remain blind to temporal correlations. The projection operation retains temporal information in the single-trial and time-resolved components, yet the meaning of that information for motor control remains open: the mapping from a temporal property of a projected series to a specific control process is itself unestablished, so applying time-series methods to the projections opens a fresh interpretive problem. UCM therefore identifies whether coordination is structured by task constraints while leaving the generating processes undetermined. Establishing this boundary is the contribution of the present work: geometric partitioning yields a spatial account of coordination whose temporal origins lie beyond the method and call for a dedicated dynamical theory.
Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:18
Hierarchy of Motor Control
 01:20
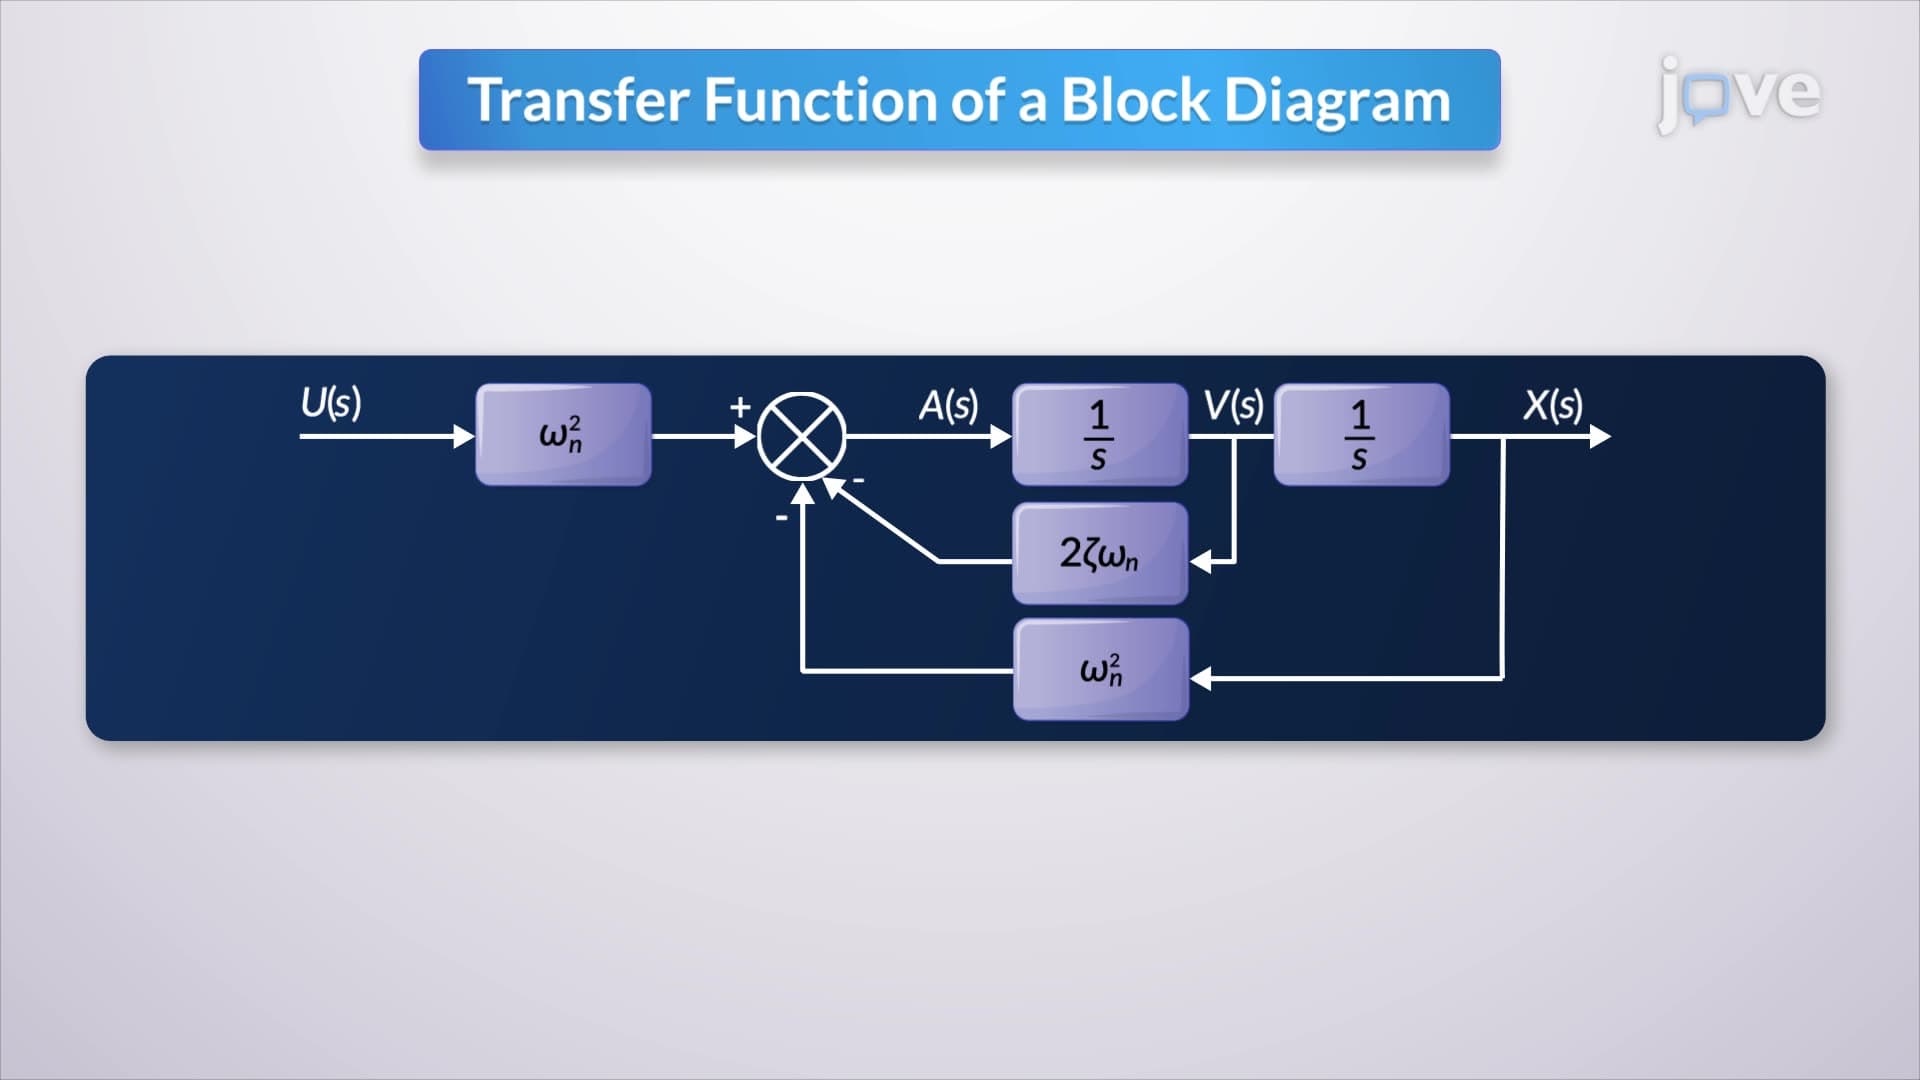
Relation between Mathematical Equations and Block Diagrams
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:27
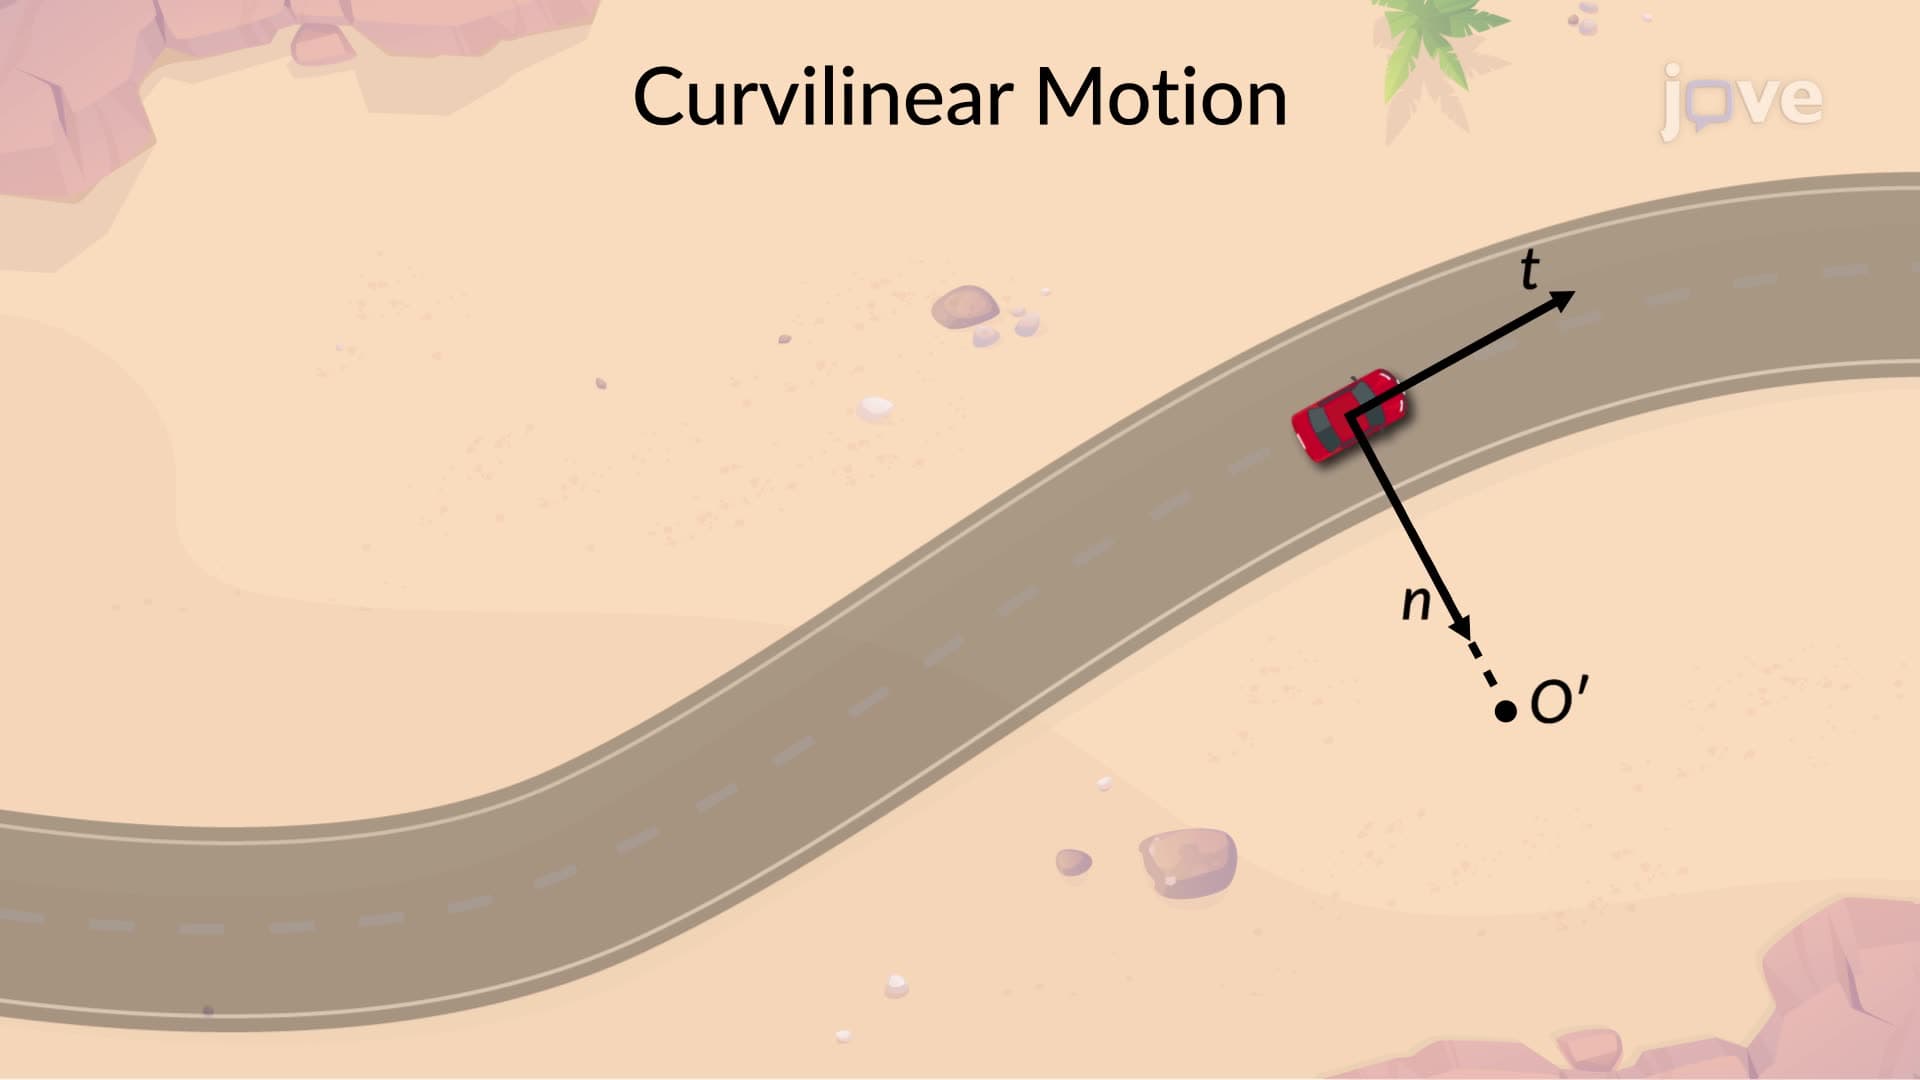
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...