Related Experiment Video
Updated: Oct 2, 2026
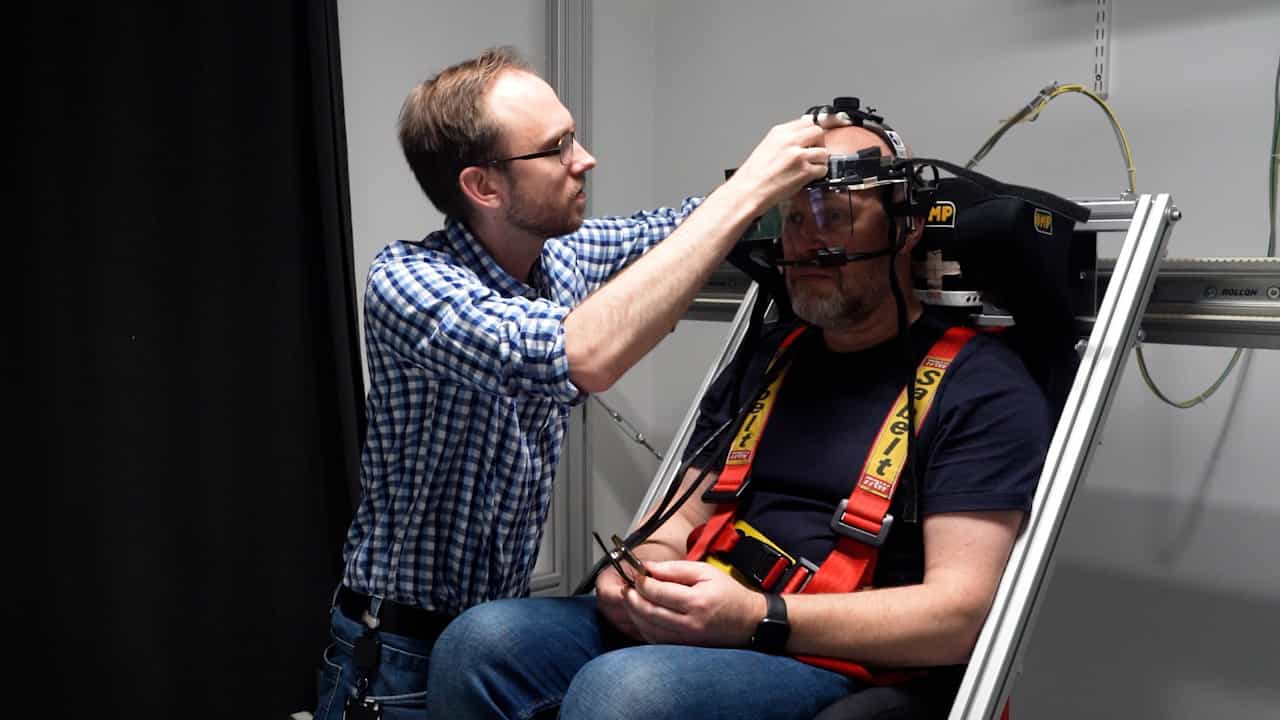

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Exposure-Midpoint Temporal Alignment and Risk-Aware Adaptive Feature Tracking for Stereo Visual-Inertial Odometry
Sucheng Yang1, Qingqing Liu2, Zhihong Zhuang1
1School of Electronic and Optical Engineering, Nanjing University of Science and Technology, Nanjing 210094, China.

Abstract:
Visual-inertial odometry (VIO) on industrial stereo camera-IMU platforms suffers from frame-dependent timing errors and degraded feature tracking under auto-exposure, auto-gain adjustment, and rapid motion. This paper presents Hardware-Synchronized Exposure-State-Aware VINS-Fusion (HS-ES-VINS), a hardware-synchronized, exposure-aware extension of VINS-Fusion. The effective sampling time of each global-shutter image is reconstructed at the exposure midpoint using synchronized trigger timestamps, the camera debounce delay, and the frame-wise exposure duration. An exposure-gain-motion risk model adaptively adjusts feature detection criteria, Kanade-Lucas-Tomasi (KLT) tracking parameters, and correspondence filtering, while IMU-integrated rotation supplies initial predictions for feature tracking. On hardware-synchronized indoor and outdoor datasets with independent ground truth, controlled experiments show that the exposure-midpoint timestamp removes the frame-dependent exposure component of the camera-IMU offset that neither fixed nor online scalar compensation can remove, reducing the ATE RMSE by 28.6% (fixed offset) and 22.7% (online estimation) relative to the exposure-start timestamp under 20 ms low-light exposure. Compared with baseline VINS-Fusion, the complete adaptive front end reduces the ATE RMSE by 16.8% and 12.9% on indoor multi-floor and outdoor cycling sequences, and the risk score explains frame-wise tracking quality (correlation of 0.587 with the inlier ratio). The front end runs faster than the baseline (17.1 ms per frame), confirming real-time operation and improved robustness against variable illumination and rapid motion.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration
 01:26
Orthogonal Trajectories
 01:03
Inertial Frames of Reference