

Beyond Accuracy: A Reliability-Oriented Multi-Dimensional Benchmark of Data-Driven Fault Diagnosis for Liquid Rocket
Mingyang Geng1, Gang Zheng1, Long He1
1Xichang Satellite Launch Center, Xichang 615000, China.

Abstract:
Liquid rocket engines (LREs) are mission-critical propulsion systems whose reliability directly affects launch safety and the repeated operation of reusable launch vehicles. Data-driven LRE fault diagnosis remains difficult because labeled fault samples are scarce, engine-to-engine variations cause distribution shifts, and existing evaluations frequently emphasize classification accuracy without controlling for input representation. This study establishes a reliability-oriented benchmark that evaluates seven representative machine-learning and deep-learning methods from four dimensions: diagnostic capability, sensor informativeness, cross-unit generalization, and data efficiency. The experiments use 1106 fault samples from the XJTU-REF dataset, covering nine fault categories, 19 sensor channels, and three simulated engine units. To ensure an apples-to-apples model comparison, all seven methods are first evaluated using the same 19-dimensional steady-state representation. Under this controlled setting, Random Forest achieves the highest accuracy of 89.15% and Macro-F1 score of 88.74%, while the best deep model, 1D-CNN, reaches 86.42%. An additional representation-ablation experiment shows that concatenating the same steady-state features with learned sequence representations increases 1D-CNN accuracy to 87.58%, reducing its gap from Random Forest to 1.57 percentage points. This result demonstrates that the large difference observed under the original heterogeneous-input setting is partly attributable to representation design rather than model family alone. In cross-unit evaluation, Random Forest obtains an average accuracy of 75.37%, whereas Transformer obtains 61.54%, indicating that engine-to-engine variation remains a major deployment challenge. The top five sensors contribute 47.62% of the total Random Forest importance, and, with five labeled samples per fault category, KNN and Random Forest achieve 71.24% and 70.82% accuracy, respectively. These findings provide quantitative guidance for algorithm selection, sensor prioritization, and data-acquisition planning in reusable launch vehicle health-monitoring systems.
Related Concept Videos
 01:15
Data Validation
Key parameters for method validation include:
 01:23
Correlation of Experimental Data
For example, a spherical particle moving through a viscous fluid experiences drag. Dimensional analysis shows that the drag force depends on the particle's diameter, velocity, and...
 01:52
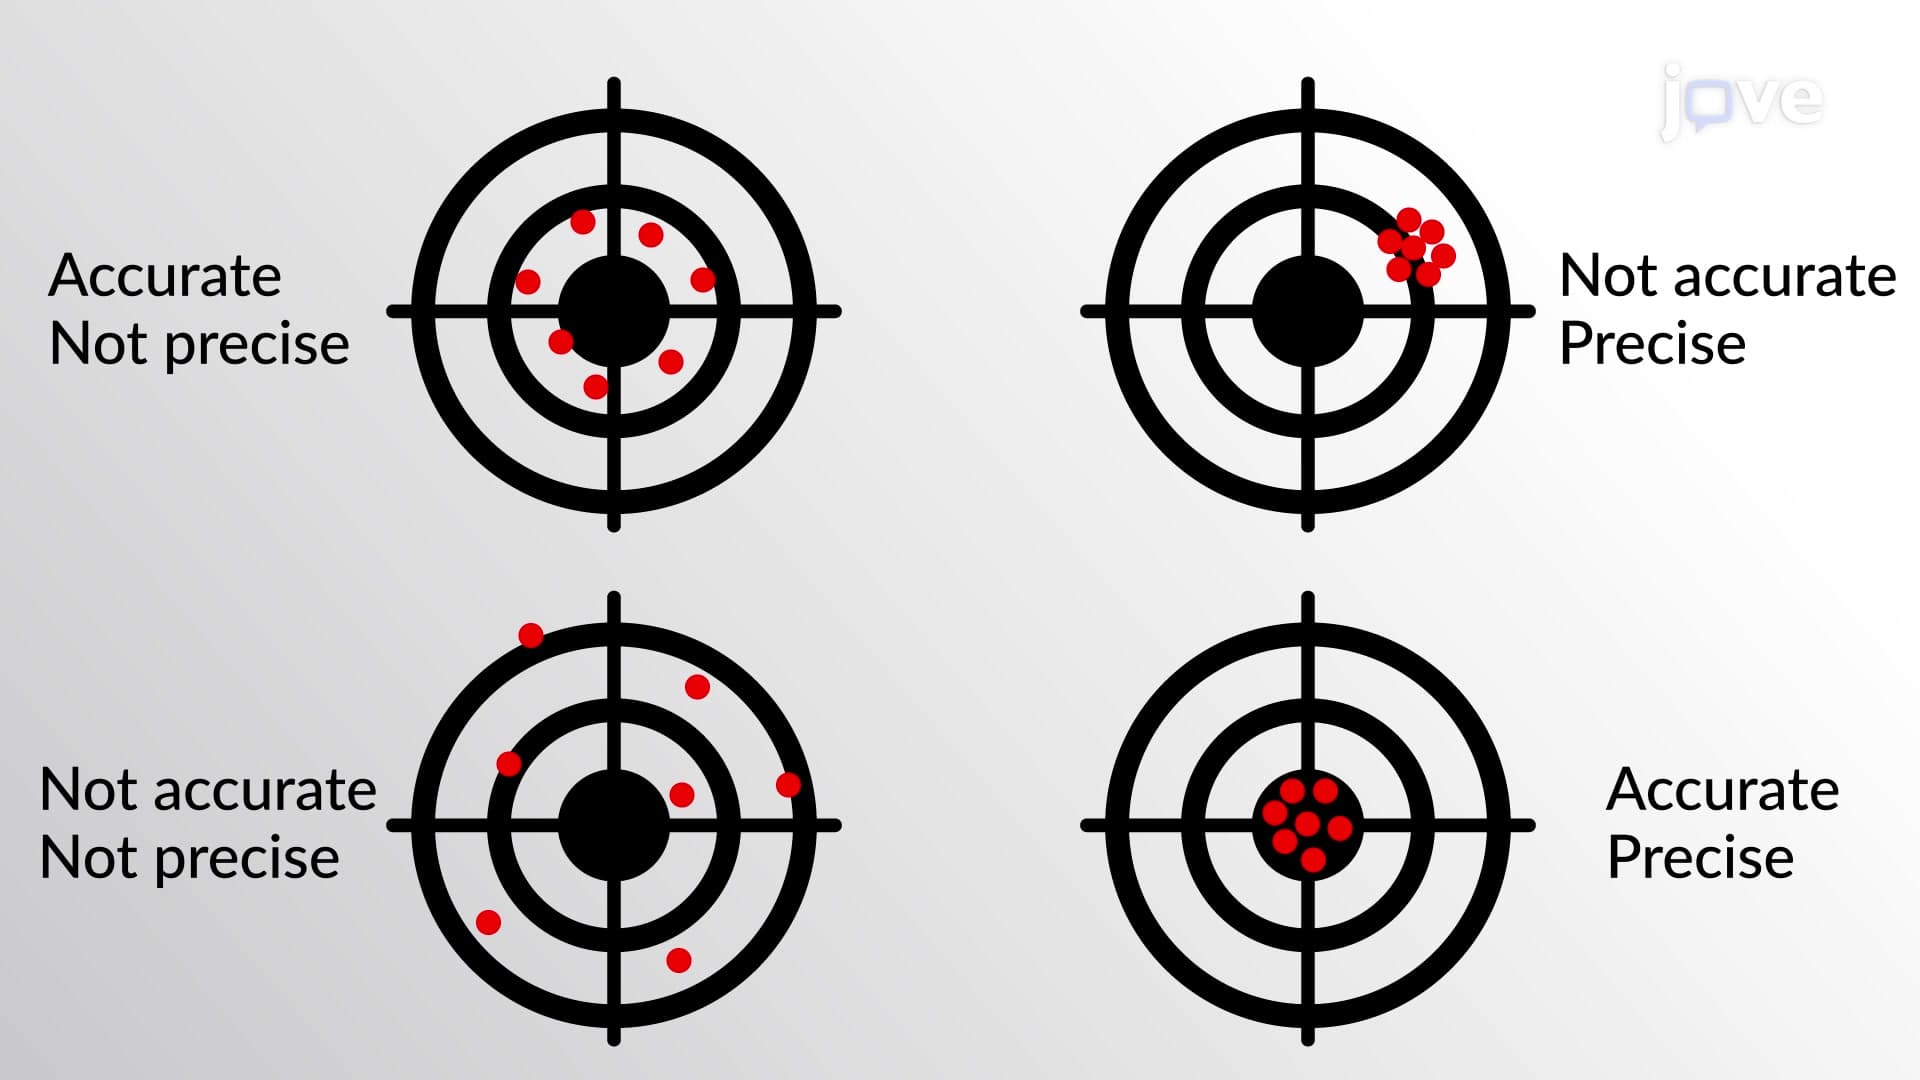
Accuracy and Precision
01:52Accuracy and Precision
 01:28
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:12
Types of Errors: Detection and Minimization
Absolute error in a measurement is the numerical difference from the true or central value. Relative error is the ratio between absolute error and the true or central value, expressed as a percentage.
Errors can be classified by source, magnitude, and sign. There are three types of errors: systematic, random, and gross.
Systematic or...