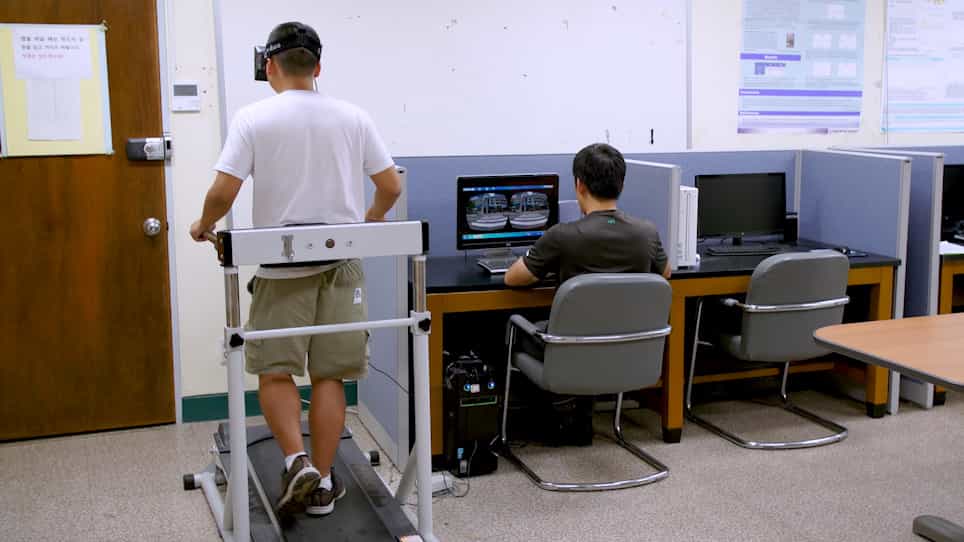
Related Experiment Video
Updated: Oct 2, 2026


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
RCN-MAMBA: Research on Pedestrian-Future-Trajectory-Prediction Methods for Occlusion Scenarios
Sijie Yang1, Zhaoyu Li2, Guoyu Lin3
1Wang Zheng Microelectronics College, Changzhou University, Changzhou 213164, China.

Abstract:
Pedestrian-future-trajectory prediction is a critical task in intelligent driving, traffic-scene understanding, and active safety decision-making. In real-world road environments, pedestrians' historical trajectories are frequently affected by occlusions from vehicles, other pedestrians, road infrastructure, and detector-missed detections, leading to missing values in the historical-observation sequence. Understanding and handling missing values in pedestrian-observation sequences is essential for improving the performance of prediction models; however, existing research has rarely considered this realistic scenario. This paper proposes RCN-MAMBA, a pedestrian-future-trajectory-prediction method for occlusion scenarios. The overall pipeline follows a de-occlusion completion first, future-trajectory-prediction second paradigm. Specifically, in the de-occlusion stage, based on linear interpolation for trajectory completion, a BiLSTM Residual-Correction Network is employed to further refine the occluded trajectory. This paper further proposes the C_MAMBA prediction architecture: first, explicit motion-state encoding is introduced to inject position, velocity, and acceleration information explicitly into the trajectory representation; then, multi-scale temporal convolution is used to extract local motion patterns across different time ranges; finally, a Temporal Bi-Mamba module is introduced to model long-term temporal dependencies in the completed trajectory from both forward and backward temporal directions. RCN-MAMBA achieves competitive performance on the JAAD dataset. Qualitative results show that its predicted future trajectories are consistent with actual motion trends. Quantitative analysis is conducted under six whole-frame random occlusion ratios: 5%, 10%, 15%, 20%, 30%, and 40%. RCN-MAMBA achieves optimal results under all these occlusion ratios. The paired-t test for each trajectory further confirms that the performance advantage of our proposed method over all baseline methods is statistically significant, demonstrating that the proposed method possesses good prediction accuracy and robustness under varying occlusion intensities.