Related Experiment Video
Updated: Oct 3, 2026


Deep-Learning Based Multi-Joint Synchronous Tracking for Objective Quantification of Hindlimb Locomotor Kinematics in Rats
Published on: April 3, 2026
KN-LIO: Kinematics and Neural Field Coupled LiDAR-Inertial Odometry

Abstract:
Recent advancements in LiDAR-Inertial Odometry (LIO) have significantly propelled robotic applications, yet traditional systems inherently prioritize localization over mapping. This results in sparse geometric representations that are often insufficient for downstream tasks. While emerging neural field technologies hold immense potential for dense scene reconstruction, pure LiDAR-based neural mapping methods severely lack robustness when deployed on high-dynamic platforms. To achieve robust online dense reconstruction under such challenging conditions, we present a novel framework that, for the first time, tightly couples IMU kinematics with neural fields. We propose both semi-coupled and tightly coupled Kinematic-Neural LIO (KN-LIO) systems, utilizing an iterated error-state Kalman filter to fuse high-frequency inertial data with online Signed Distance Function (SDF) decoding. In this framework, the high-precision state estimation serves as a robust tracking backbone, ensuring continuous and precise neural field updates. Furthermore, our system seamlessly accommodates asynchronously triggered multi-LiDAR inputs to maximize the structural completeness of the dense maps. Extensive evaluations on diverse high-dynamic datasets demonstrate that our framework delivers superior dense mapping quality compared to traditional pure LiDAR methods, underpinned by robust pose tracking performance that matches or exceeds state-of-the-art LIO solutions. The relevant code and datasets will be made available to the community upon publication. https://github.com/peterWon/KN-LIO.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
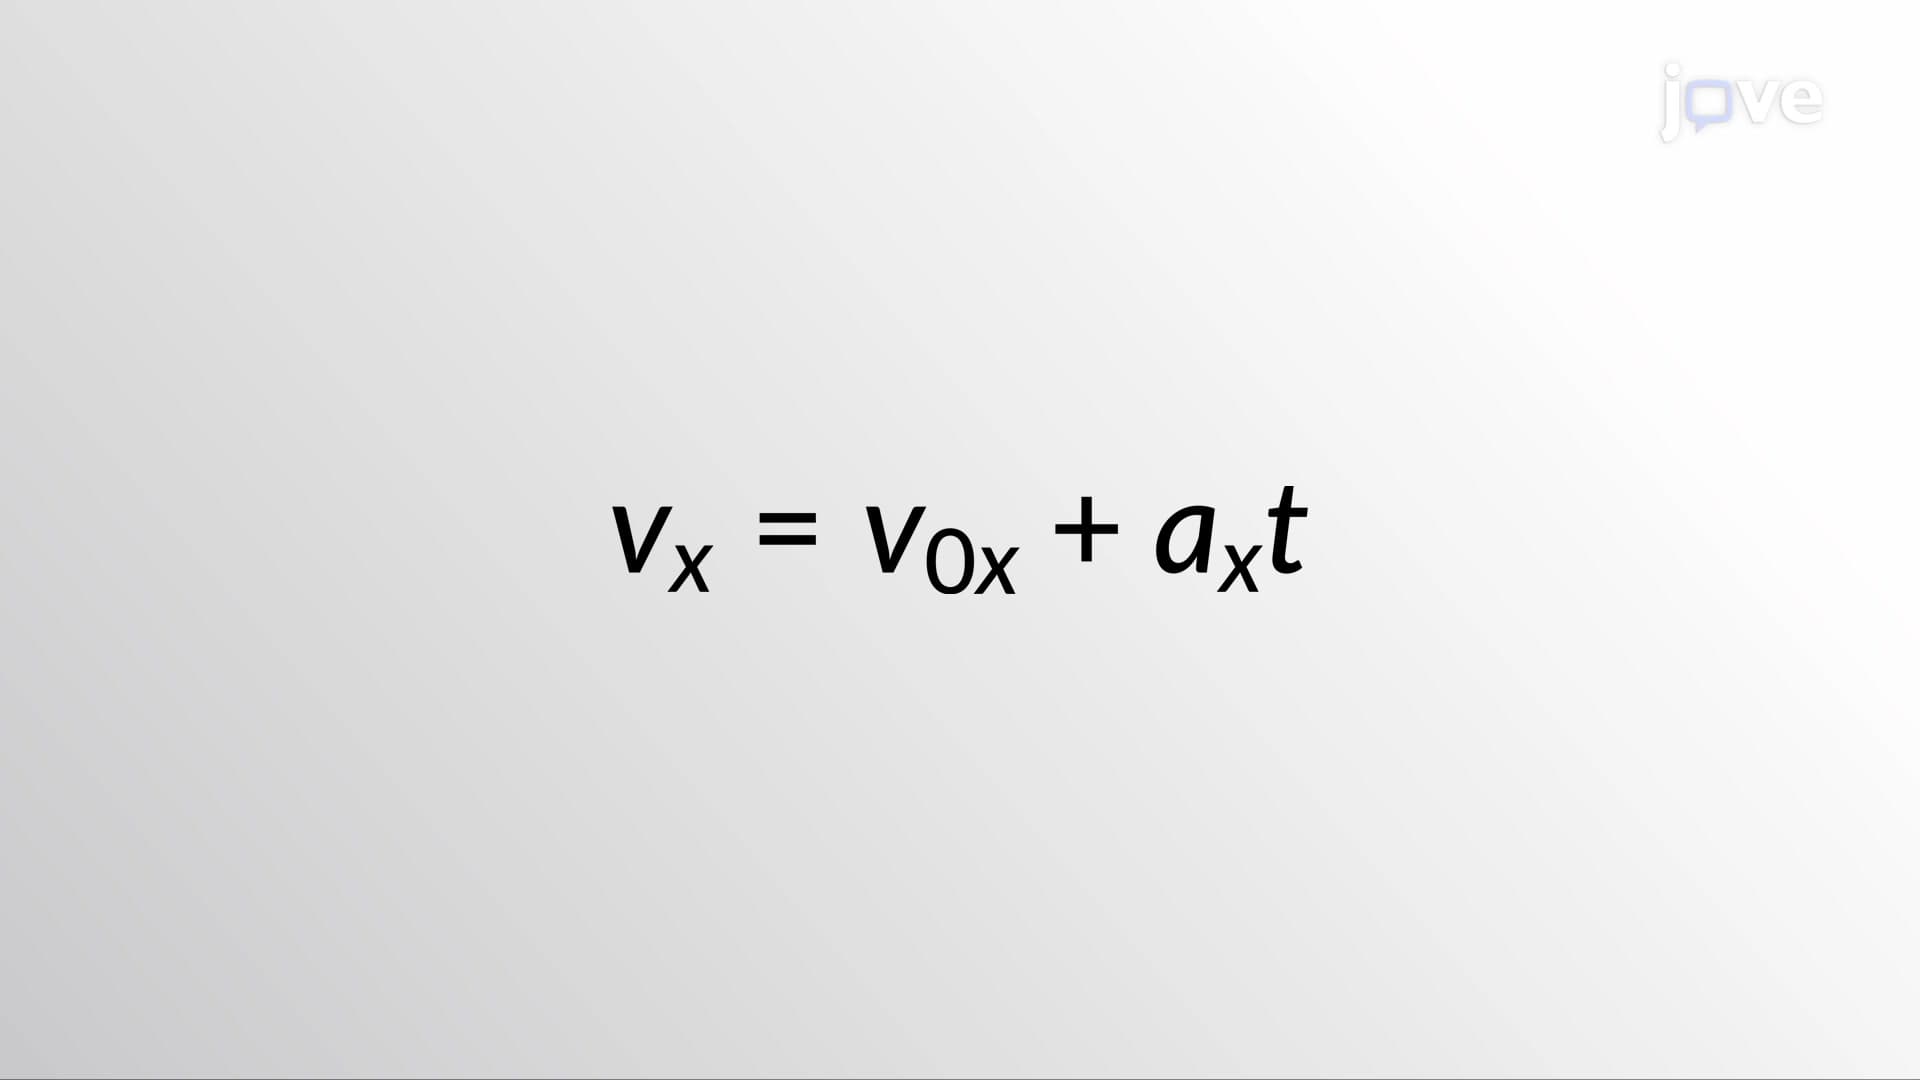 01:26
Kinematic Equations - I
 01:03
Inertial Frames of Reference
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...