Related Experiment Video
Updated: Oct 3, 2026
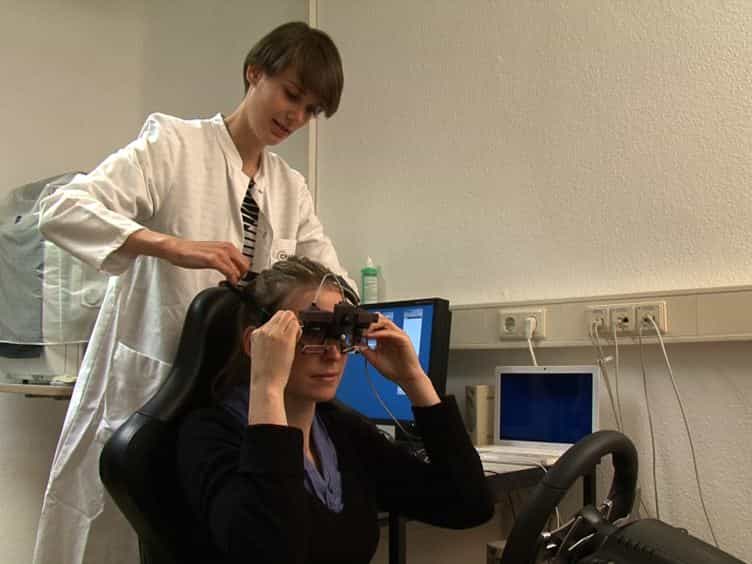

Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Confident but incomplete: gaze behavior and driving dynamics in deadlock situations at T-intersections
Nadine-Rebecca Strelau1, Barbara Deml1
1Institute of Human and Industrial Engineering, Karlsruhe Institute of Technology, Karlsruhe, Germany.

Introduction:
Deadlock situations at T-intersections pose a challenge for human drivers and automated vehicles, as formal right-of-way rules provide no clear guidance and drivers do not share a uniform interpretation of these situations. The present driving simulator study investigated how drivers approach deadlock situations before a standstill occurs and whether they perceive the situation as a conflict.
Method:
Participants drove through an urban environment and encountered deadlock situations from all three possible approach positions while the arrival order of the cooperating vehicles was varied. Perceived ambiguity was assessed after each encounter. Eye movements and driving parameters were analyzed in the segment between 25 m and 10 m before the intersection, and driving order was recorded.
Result/Discussion:
Results show that drivers generally did not perceive deadlock situations as ambiguous. Gaze analyses revealed that at least one cooperating vehicle was often not fixated during the approach, indicating that the full deadlock structure and thus the potential conflict was often not visually processed. Differences in gaze behavior and driving dynamics between drivers who proceeded first and those who stopped emerged only for the left approach. Driving order was influenced by the interaction of approach position and arrival order, with drivers from the left frequently proceeding first when the vehicle from below arrived later. Additionally, a random forest classifier provided a proof of concept for data-driven prediction of driving order based on externally observable approach-related variables. Together, these findings offer a deeper understanding of driver behavior in deadlock situations and provide recommendations for automated vehicles' behavior aimed at preventing standstills.

Related Concept Videos
 01:26
Constraints and Statical Determinacy
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance
 01:42
Schemas
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:29
Sight Distance in a Vertical Curve
 01:43
Incomplete Dominance