Related Experiment Video
Updated: Oct 7, 2026
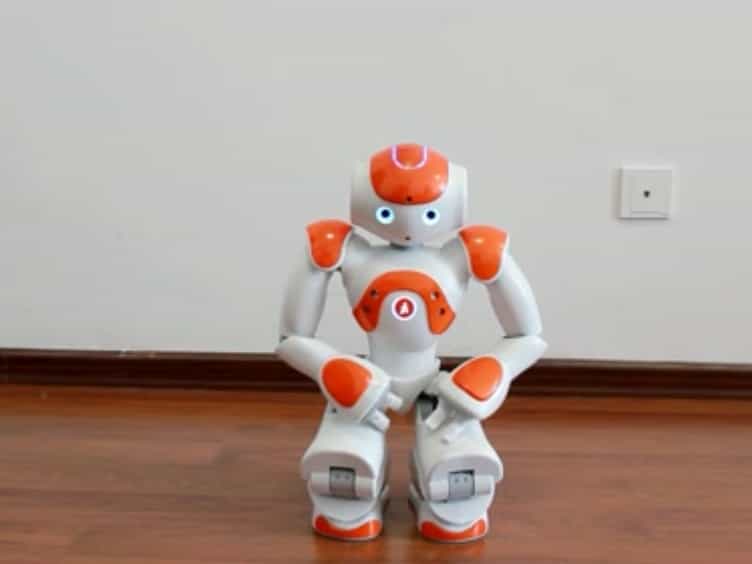

SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Knowledge of robotic identity modulates attentional orienting to humanoid robot motion
Yuhui Cheng1,2, Jianing Zhang3, Jing Hu3
1School of Psychology, Nanjing Normal University, Nanjing, 210097, China.

Abstract:
As humanoid robots become increasingly integrated into human social environments, understanding how individuals perceive and respond to robotic social cues is critical for advancing research in social cognition. While previous studies have demonstrated that robotic eye gaze can direct human attention, the impact of robotic motion on attentional orienting effects remains unclear. In the present study, we employed point-light displays of humanoid robot walking motion as central cues in a modified cueing paradigm. In Experiment 1, participants were naive to the fact that the observed motion patterns represented a robot, and we observed a cueing congruency effect; however, no significant difference emerged between the upright and inverted conditions. In Experiment 2, participants were explicitly informed participants that the motion depicted a robot, and the cueing effects differed significantly between the upright and inverted conditions specifically at 500 ms. Notably, this effect was significantly correlated with participants' perception of animacy. These findings suggest that while robotic motion has the potential to elicit attentional shifts, its effectiveness is further modulated by participants' conceptual knowledge of the agent and perception of animacy. This underscores the pivotal role of mental attribution in shaping social cognitive responses to artificial agents, offering valuable insights for designing socially interactive robots.