Related Experiment Video
Updated: Oct 9, 2026

Flapping Soft Fin Deformation Modeling using Planar Laser-Induced Fluorescence Imaging
Published on: April 28, 2022
Minimal-actuation feather star-inspired soft swimmers for multimodal 3D maneuverability
Haitao Qing1, Yuanhang Zhu2,3, Jiacheng Guo2
1Department of Mechanical and Aerospace Engineering, North Carolina State University, Raleigh, NC 27695, USA.

Abstract:
Complex, three-dimensional (3D) motions typically require actuator arrays and complex control architectures. Here, we present a feather star-inspired soft robotic swimmer that uses only two pneumatic inputs to produce three distinct and switchable swimming modes: jellyfish-like pulsation, fishlike propulsion, and rotor-like reorientation. The robot owes this ability to mechanical intelligence: It leverages a monostable instability in its flexible arms to convert two control actuation inputs into 3D swimming modes, including ascension and descension, forward and backward swimming, hovering, and rotation. The robot achieves a maximum swimming speed of 1.64 body lengths per second, minimum cost of transport of 17.6, and peak rotation speed of 90° per second. Particle image velocimetry analyses and computational fluid dynamics simulations reveal distinct vortex structures governing thrust generation and/or rotational torque in each swimming mode. The robot's minimal input yet multimodal output demonstrates how mechanical intelligence can enable adaptive and multifunctional, yet simple and energy-efficient, robotic and biological swimming mechanisms.

Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
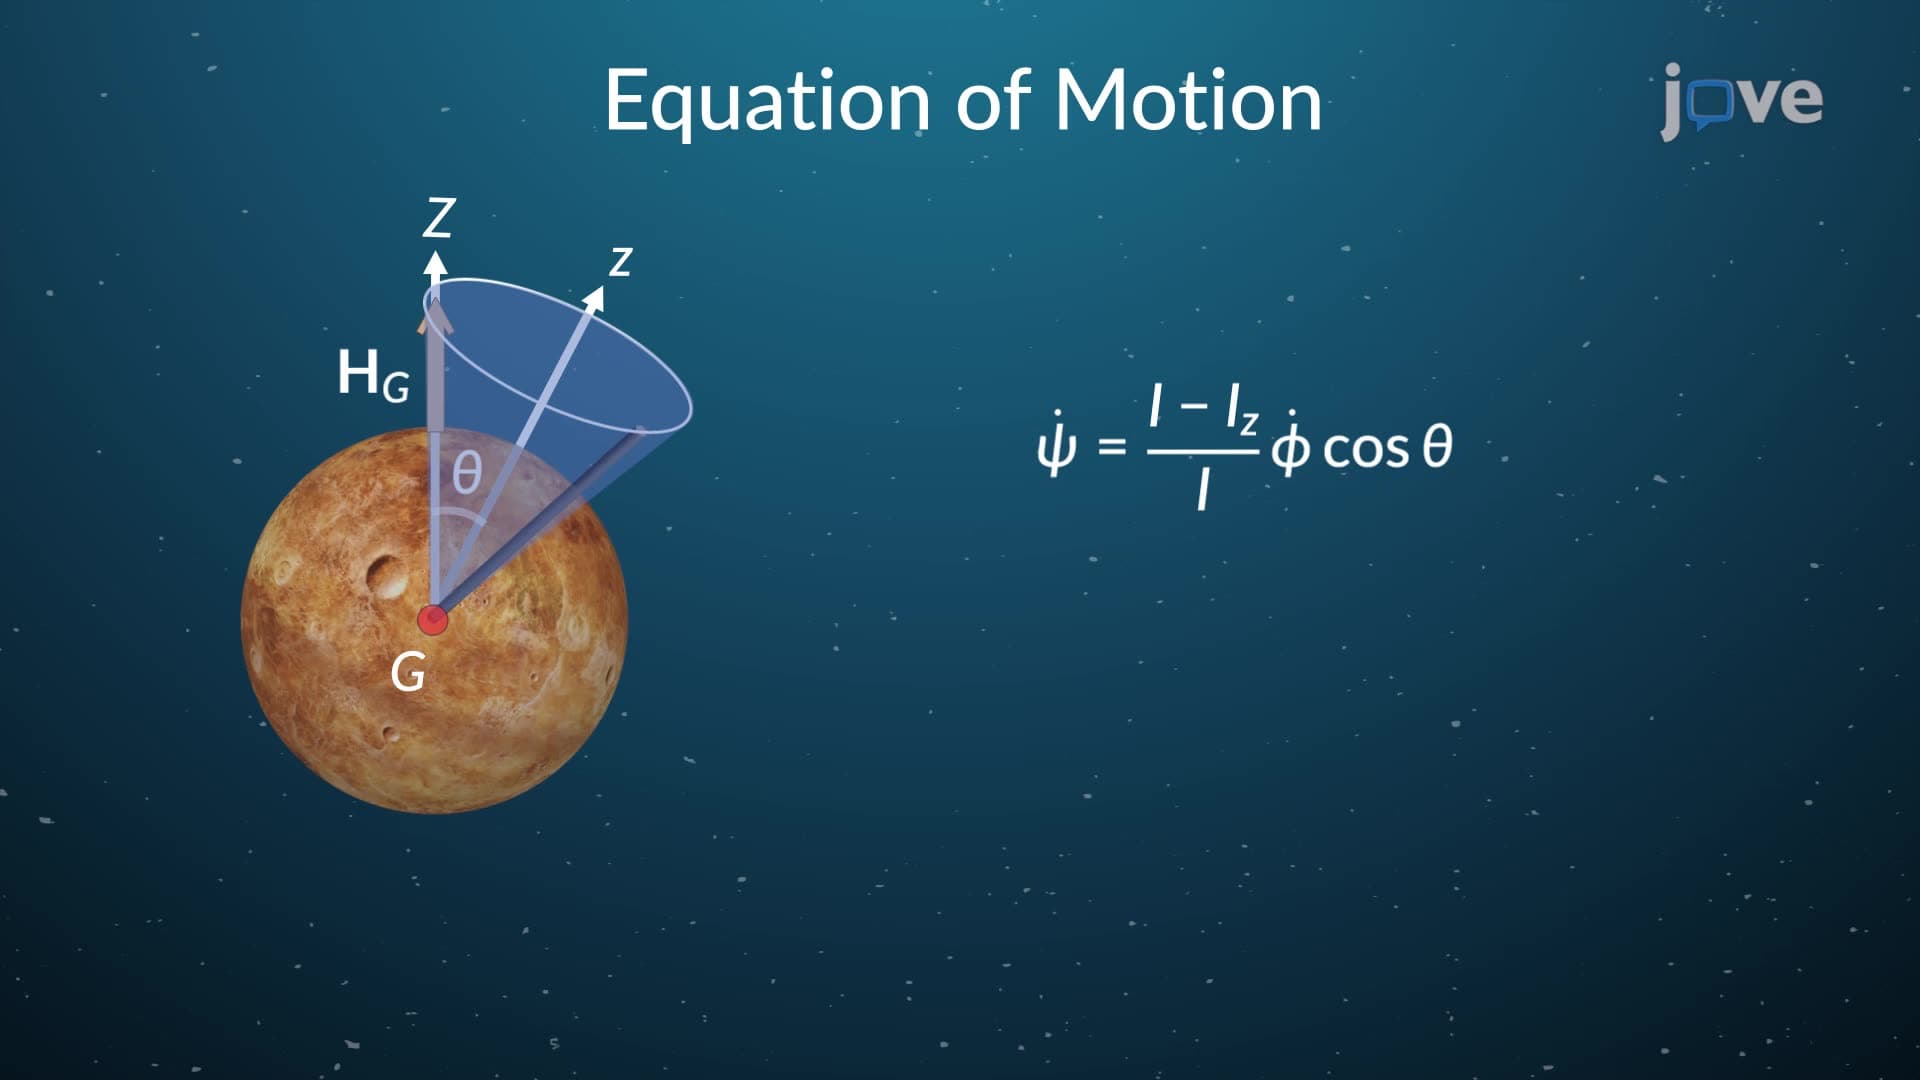
Torque Free Motion
 01:12
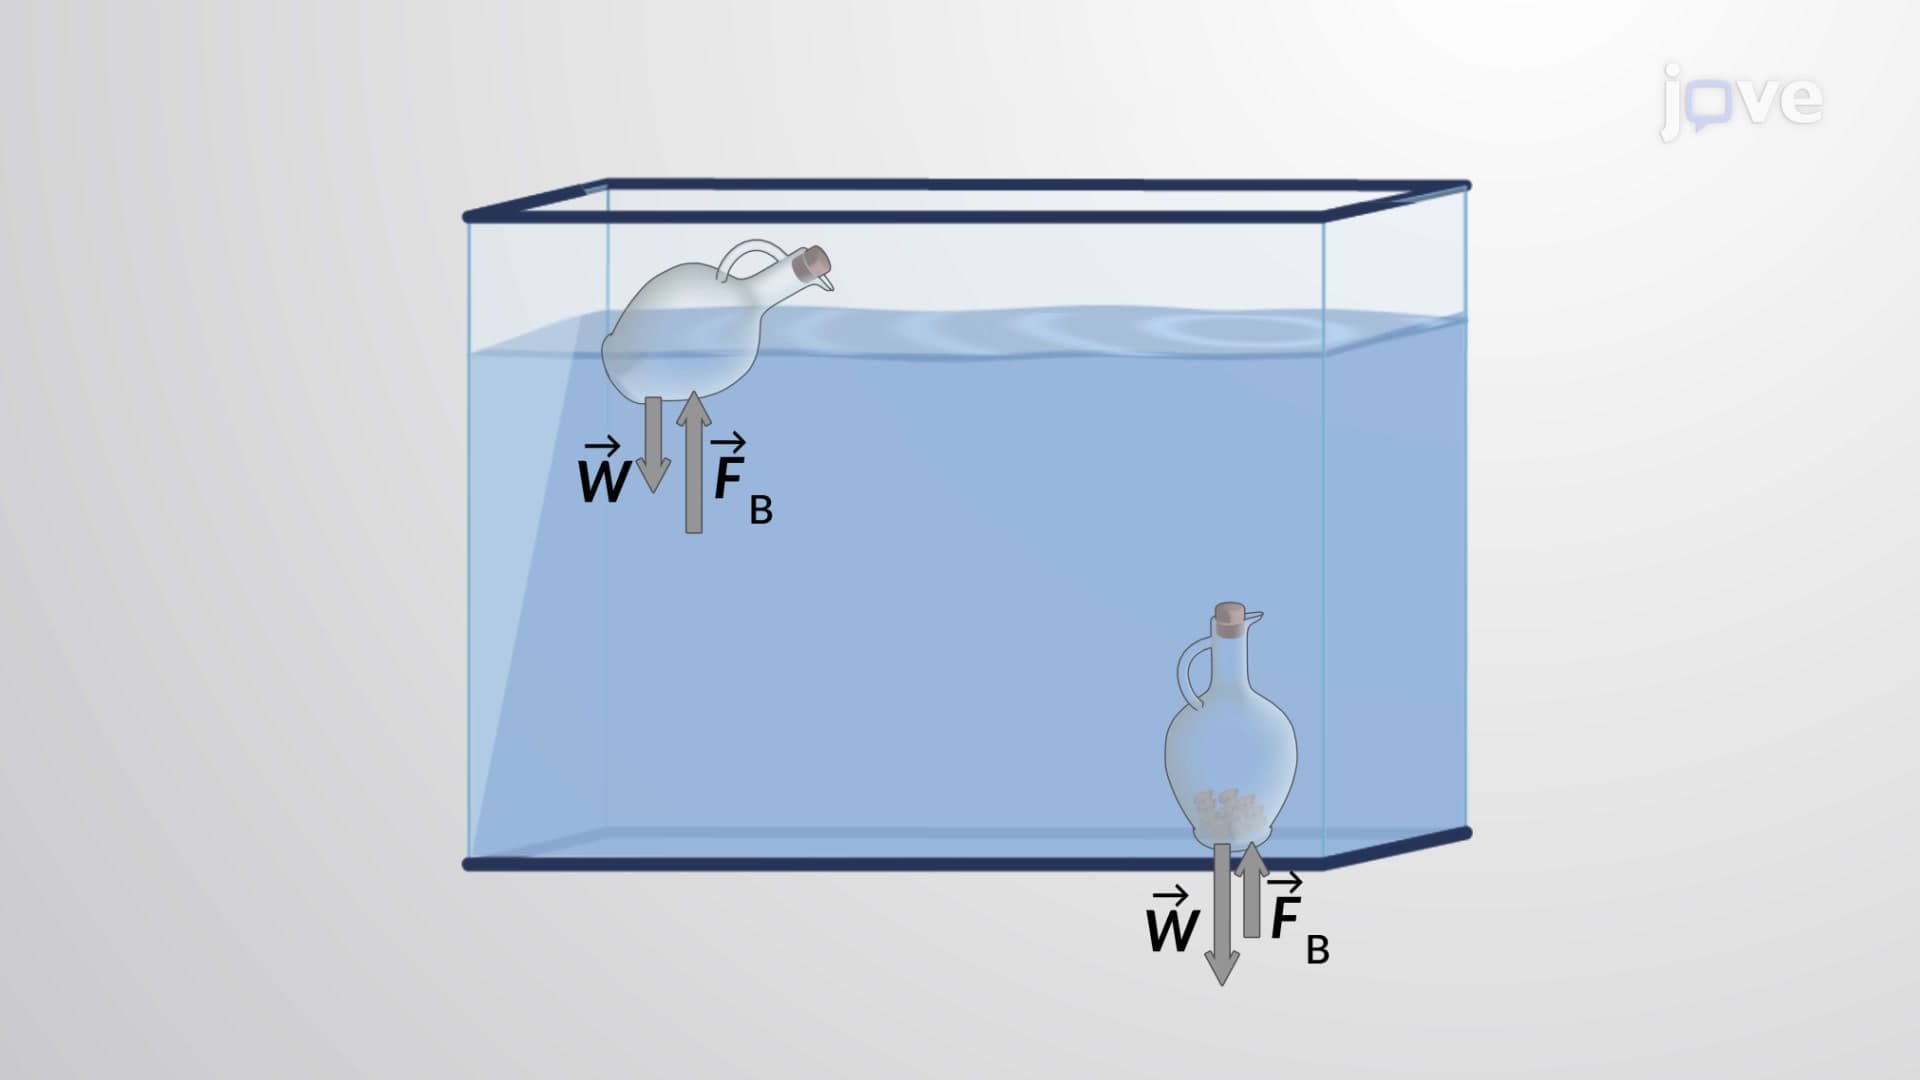
Buoyancy
To get...