Related Experiment Video
Updated: Oct 10, 2026
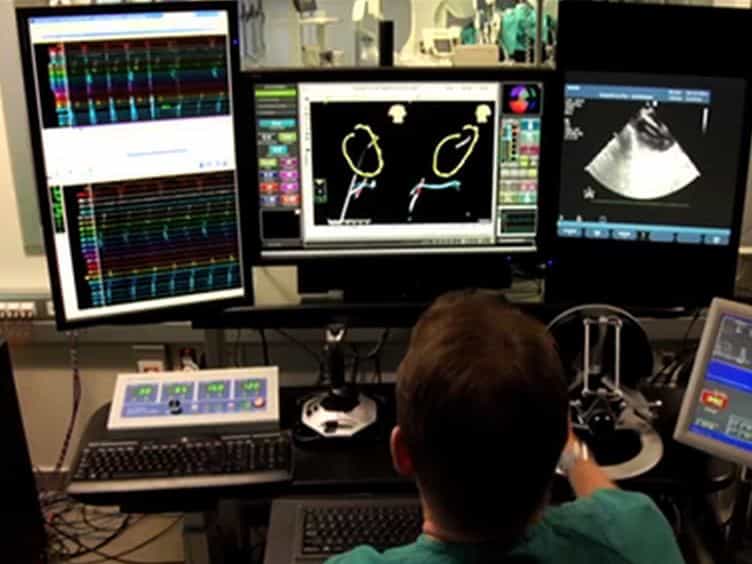

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Magnetic catheter robot with dynamic force feedback for stiffness identification and abnormality detection
Haolan Shen1,2, Zhengwei Li2,3, Shixiong Fu4
1Guangdong Provincial Key Laboratory of Robotics and Intelligent System, Shenzhen Institutes of Advanced Technology, Chinese Academy of Sciences, Shenzhen 518055, China.

Abstract:
Magnetic continuum robots offer unique advantages for minimally invasive surgery owing to their flexibility, miniaturization, and remote actuation. However, the absence of reliable real-time force feedback in existing magnetically actuated catheters severely constrains safe interaction, and quantitative identification of tissue mechanical properties. To address this limitation, this work presents a magnetic catheter robot with integrated dynamic force feedback. The proposed system integrates an axial optical force sensor, a miniaturized endoscope, and annular permanent magnets within a compact distal architecture. This design achieves sub-0.01 N force resolution while remaining robust under large bending deformations and varying deflection angles. System performance is quantitatively evaluated through force-controlled planar writing, 3D curved-surface palpation with shape perception and stiffness mapping, and endoscope-guided bronchial palpation, demonstrating reliable stiffness-based abnormality detection in complex luminal environments. These results demonstrate the feasibility of force-aware magnetic catheterization for quantitative assessment of local tissue mechanics, providing a clinically relevant platform for minimally invasive diagnostics.
More Related Videos
 11:27
Magnetically-Assisted Remote Controlled Microcatheter Tip Deflection under Magnetic Resonance Imaging
Published on: April 4, 2013
 08:55
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023