Related Experiment Video
Updated: Oct 10, 2026


Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Data-driven iterative learning control for nonlinear multivariate systems using transpose adaptive filtering
Yu-Hsiu Lee1, Yi-Tai Cheng1, Kai-Shiang Yuan1
1Department of Mechanical Engineering, National Taiwan University, Taipei, 106319, Taiwan.

Abstract:
This paper presents a novel data-driven iterative learning control (ILC) algorithm for stabilized multivariable nonlinear dynamical systems. The proposed algorithm incorporates two data-driven learning mechanisms: an adaptive feedforward algorithm that models perturbed dynamics as an unknown linear time-varying system and minimizes RMS errors with respect to an LTI reference model, followed by a second learning mechanism for fast convergence in trajectory tracking. For multivariate systems, the non-commutative nature of the cascade of systems necessitates the use of the right inverse for adaptive model matching to promote error convergence. To address challenges in adaptive filtering, a transposition-based technique is introduced to obtain the right inverse for square and over-actuated systems. For -input- -output systems, the approach necessitates conducting experiments. An efficient algorithm is proposed to reduce this requirement by reorganizing impulse response matrix components. The effectiveness of the proposed methods is demonstrated through both simulations and experiments.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:21
Transfer Function in Control Systems
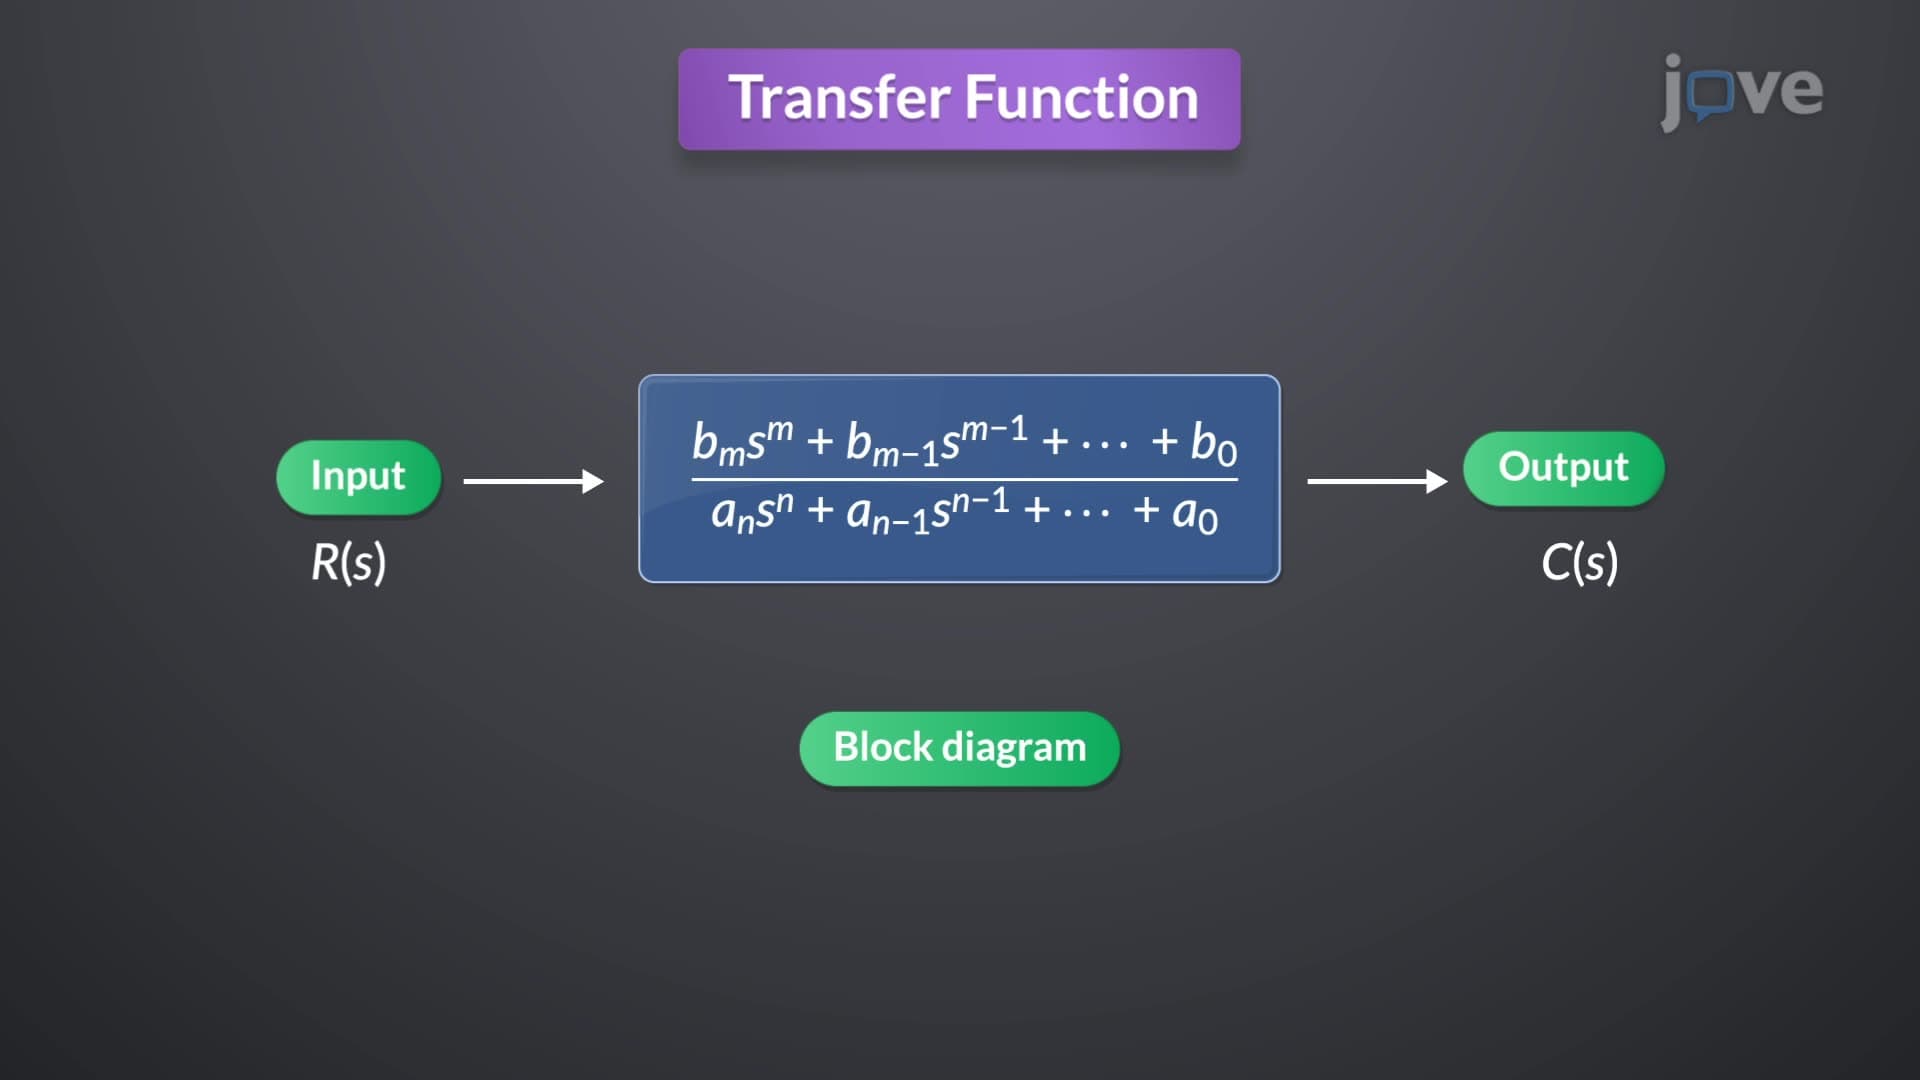
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:27
Linear Differential Equations