Related Experiment Video
Updated: Oct 11, 2026
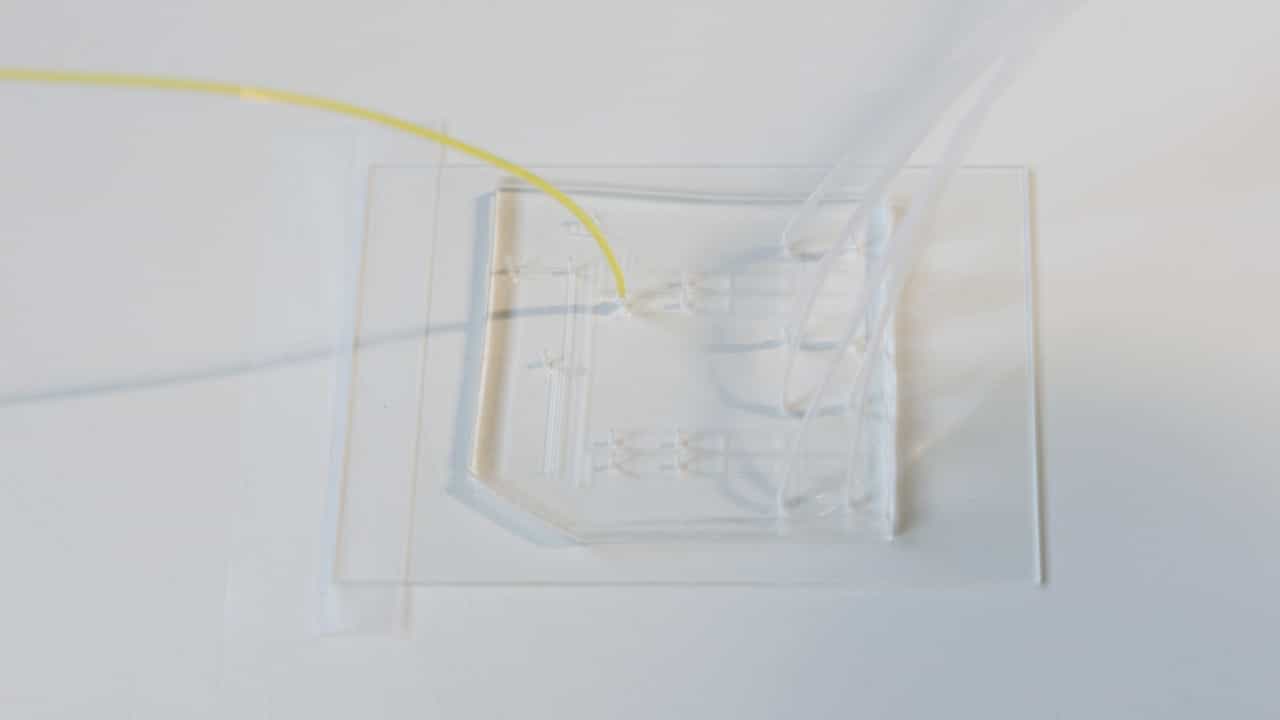

Bilayer Microfluidic Device for Combinatorial Plug Production
Published on: December 1, 2023
Scalable design of fluidic DEMUX/MUX
Hwayeong Jeong1, Jamie Paik1, Jung Kim2
1École Polytechnique Fédérale de Lausanne (EPFL), Lausanne, Switzerland.

Abstract:
Fluidic logic circuits offer a foundation for decentralized onboard control in soft pneumatic robots, enabling their integration into actuator networks to generate complex movements. However, existing fluidic controllers in soft robots face scalability limitations, restricting their ability to handle growing degrees of freedom across sizes while preserving compliance. Here, we present a scalable fluidic control architecture that integrates high-radix demultiplexing with time multiplexing to achieve a high input-to-output ratio and reprogrammable actuation. We incorporate a design method based on dimensionless parameters to preserve comparable valve opening and closing pressure thresholds across different physical scales, thereby maintaining consistent addressing behavior of the demultiplexer after geometric scaling. In addition, structural stretchability enables seamless integration into soft bodies, maintaining reliable control under dynamic deformation without compromising compliance. This hybrid demultiplexer/multiplexer fluidic circuit overcomes key limitations, offering functional scalability, geometric scalability, and physical integrability in a single architecture. Our approach enables autonomous, adaptable soft robots capable of complex, multifunctional motions, functioning as self-contained systems.