Related Experiment Video
Updated: Oct 11, 2026


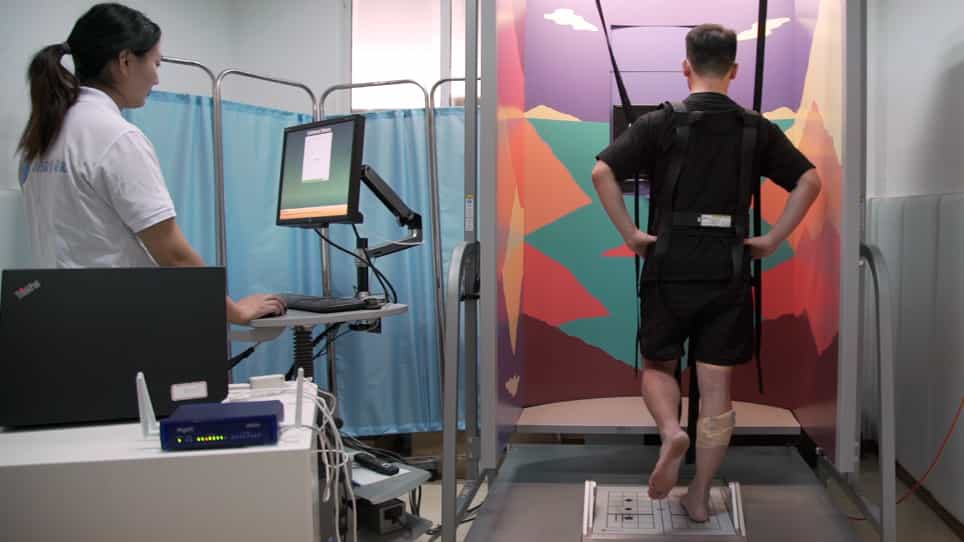
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Different stabilizing mechanisms but a common task-level aim in standing and walking
Yang Geng1, Jaap H van Dieën1, Sjoerd M Bruijn1
1Department of Human Movement Sciences, Faculty of Behavioral and Movement Sciences, Amsterdam Movement Sciences, Vrije Universiteit Amsterdam, Amsterdam, The Netherlands.

Abstract:
Intrinsic mechanisms and feedback control act together to stabilize the body in upright tasks. In unperturbed standing and walking, their combined effects can be captured by lumped stabilization models, relating delayed center of mass position and velocity information to current ground reaction forces. If and how lumped stabilization parameters change across these tasks is unclear. We applied a stabilization model to estimate and compare stabilization between unperturbed standing and walking. Fifteen healthy young participants (21 ± 4 yrs, 63 ± 9 kg, 1.70 ± 0.10 m, 13 females, 2 males) walked at 1.25 m/s for 5 minutes, and performed 3 different standing tasks: normal standing, unipedal standing, and step posture for 1 minute, repeated 5 times. Whole-body kinematics and ground reaction forces were collected and used to fit the stabilization model and estimate the effective delay and lumped gains. Only small differences were found between standing tasks. Model fits were significantly higher in standing than in walking. ML effective delays were significantly longer in walking than in standing, whereas AP delays were comparable. The stabilization gains varied significantly across tasks and directions. The lumped position gains in most tasks exceeded critical stiffness, except for the mean values in walking, which were lower than the critical stiffness. Lumped velocity gains were all at under-damped level. The ratio of lumped position to velocity gains in standing were consistently close to human body's eigenfrequency (gl) as predicted by the extrapolated center of mass concept. In walking, the ratio was close to the eigenfrequency during phases in which stabilization was significant. Our findings suggest that stabilization is organized at the task level, with lumped effects of all stabilizing mechanisms acting to preserve a consistent weighting between position and velocity contributions across tasks, effectively regulating the CoM motion to follow a pendulum-like trajectory.

Related Concept Videos
 01:28
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles.
 01:14
Stability of structures
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:22
Isotonic and Isometric Muscle Contractions
Isotonic contractions
Isotonic contractions occur when a muscle changes length while the...
 01:30
Equations of Equilibrium in Three Dimensions
According to the vector equations of equilibrium, the vector sum of all the external forces acting on a body must...