Related Experiment Video
Updated: Oct 11, 2026
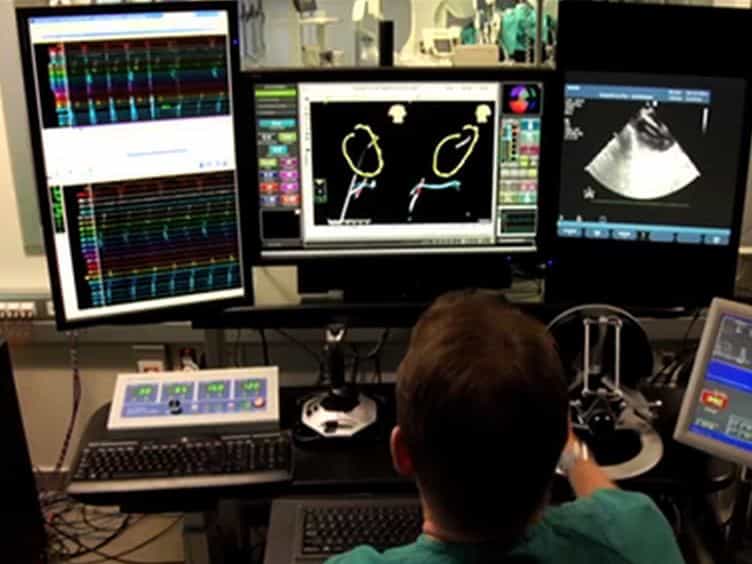

Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Magnetically guided microrobot via minimally invasive percutaneous cisternal access: a first preclinical evaluation
Oana M Mereuta1, Julien Ognard1,2, William G Loudon3
11Department of Radiology, Mayo Clinic, Rochester, Minnesota.

Objective:
Magnetically guided microrobots could enable minimally invasive intracranial interventions by navigating CSF spaces without traversing brain parenchyma. However, clinical translation requires in vivo validation of delivery, control, retrieval, and short-term safety under realistic workflow conditions. The aim of this study was to assess the feasibility and initial safety of percutaneous cisterna magna access, microrobot navigation, and retrieval using an image-integrated electromagnetic coil platform in a large-animal model, targeting future application to Dandy-Walker malformation cyst fenestration.
Methods:
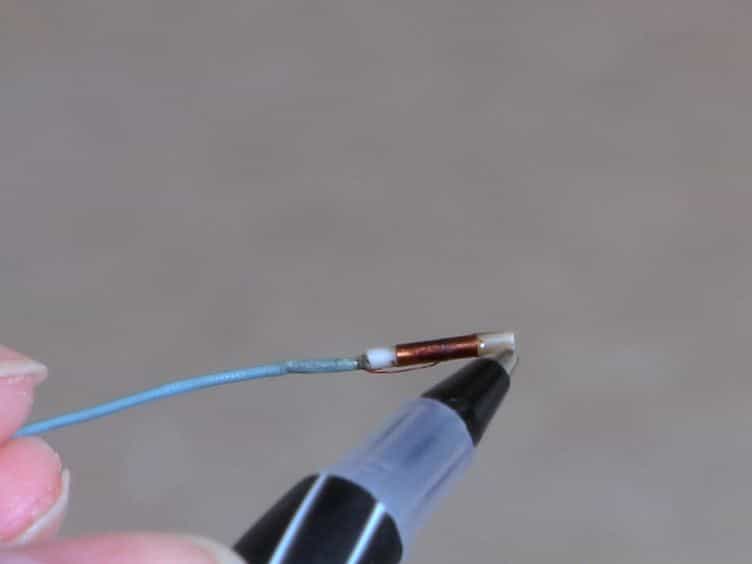
In this Good Laboratory Practice-compliant ovine study, 7 male sheep were allocated to an MRI-only control group (n = 1), flexion control group (n = 1), and treatment group (n = 3; percutaneous cisternal access, deployment of a 3.5 × 7-mm Parylene-C-coated bladed microrobot with a neodymium core, magnetic navigation, scripted dwell, and retrieval), with 2 animals designated as alternates. Preoperative MRI was used for planning, with intraoperative cone-beam CT fusion and biplanar fluoroscopy. The follow-up period was 28 days and included daily observation, weekly neurological examination, and analysis of hematology/chemistry, intraoperative CSF, and terminal necropsy with histopathology. Outcomes were descriptive.
Results:
The full workflow was completed in all 3 treated animals without conversion or rescue. Cannulation succeeded on the first attempt; continuous fluoroscopic visibility and stable magnetic control were maintained; and retrieval succeeded in a single maneuver. Postoperative recovery was uneventful, with weight gain and no neurological deficits over 28 days of follow-up. Laboratory values were within reference ranges except for 1 case of transient leukocytosis (day 0) that resolved. CSF was acellular/normal. Necropsy showed localized procedure-site changes only (dural fibrosis, thin adhesions in 2 of 3 treated animals). Histology revealed focal superficial vermian gliosis ≤ 2 mm in 2 of 3 treated animals without hemorrhage, necrosis, or off-target injury, and controls were within normal limits (1 case of minimal incidental axonal change in the flexion control).
Conclusions:
Percutaneous cisternal delivery and retrieval of an untethered microrobot were feasible and tolerated in sheep, with localized tissue responses at 28 days. These findings support further studies focused on longer follow-up, workflow optimization, and disease-specific efficacy.