Related Experiment Video
Updated: Oct 12, 2026


End-To-End Deep Neural Network for Salient Object Detection in Complex Environments
Published on: December 15, 2023
Adjusting modal contributions via differential-driven SoftMax fusion for RGB-IR object detection

Abstract:
Visible light (RGB) and infrared (IR) fusion enhances object detection in complex environments by leveraging complementary modalities. However, adaptively balancing modal contributions under extreme distribution imbalance remains challenging, while transformer-based methods incur heavy computational costs. To address this, we propose Diff-Fusion, which uses semantically prepared inter-modal differences to generate spatially varying complementary weights for modal contributions in efficient RGB-IR detection. To improve modality-specific feature encoding, we apply lightweight RGB and IR detail enhancement adapters to the pretrained encoder. Then, we design the adaptive differential-driven feature fusion (ADFF) module to learn the relative contribution weights of RGB and IR features during fusion. To prepare multi-modal features for contrast-driven fusion, ADFF first learns shared channel-wise semantic weights to construct comparable spatial response maps. Finally, ADFF derives paired contribution weights from the inter-modal difference through a parameter-free complementary gate, enabling context-aware feature complementarity. The design combines modality-specific adaptation with spatially varying, normalized relative weighting in a parameter-efficient fusion framework. Extensive experiments on the FLIR, LLVIP, and M3FD datasets demonstrate that Diff-Fusion achieves leading reported mAP values of 50.6%, 71.4%, and 54.0%, respectively, with compact trainable adaptation and fusion modules. These results support the effectiveness of its compact adaptation and spatially adaptive fusion design for RGB-IR object detection.
Related Concept Videos
 01:19
IR Spectrum
Transmittance is defined as the ratio of the radiant power passing through a sample to that from the radiation's source. Multiplying the transmittance by 100 gives the percent transmittance (%T), which varies between 100% (no absorption) and 0% (complete...
 01:03
IR Frequency Region: Fingerprint Region
The...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:20
Deconvolution
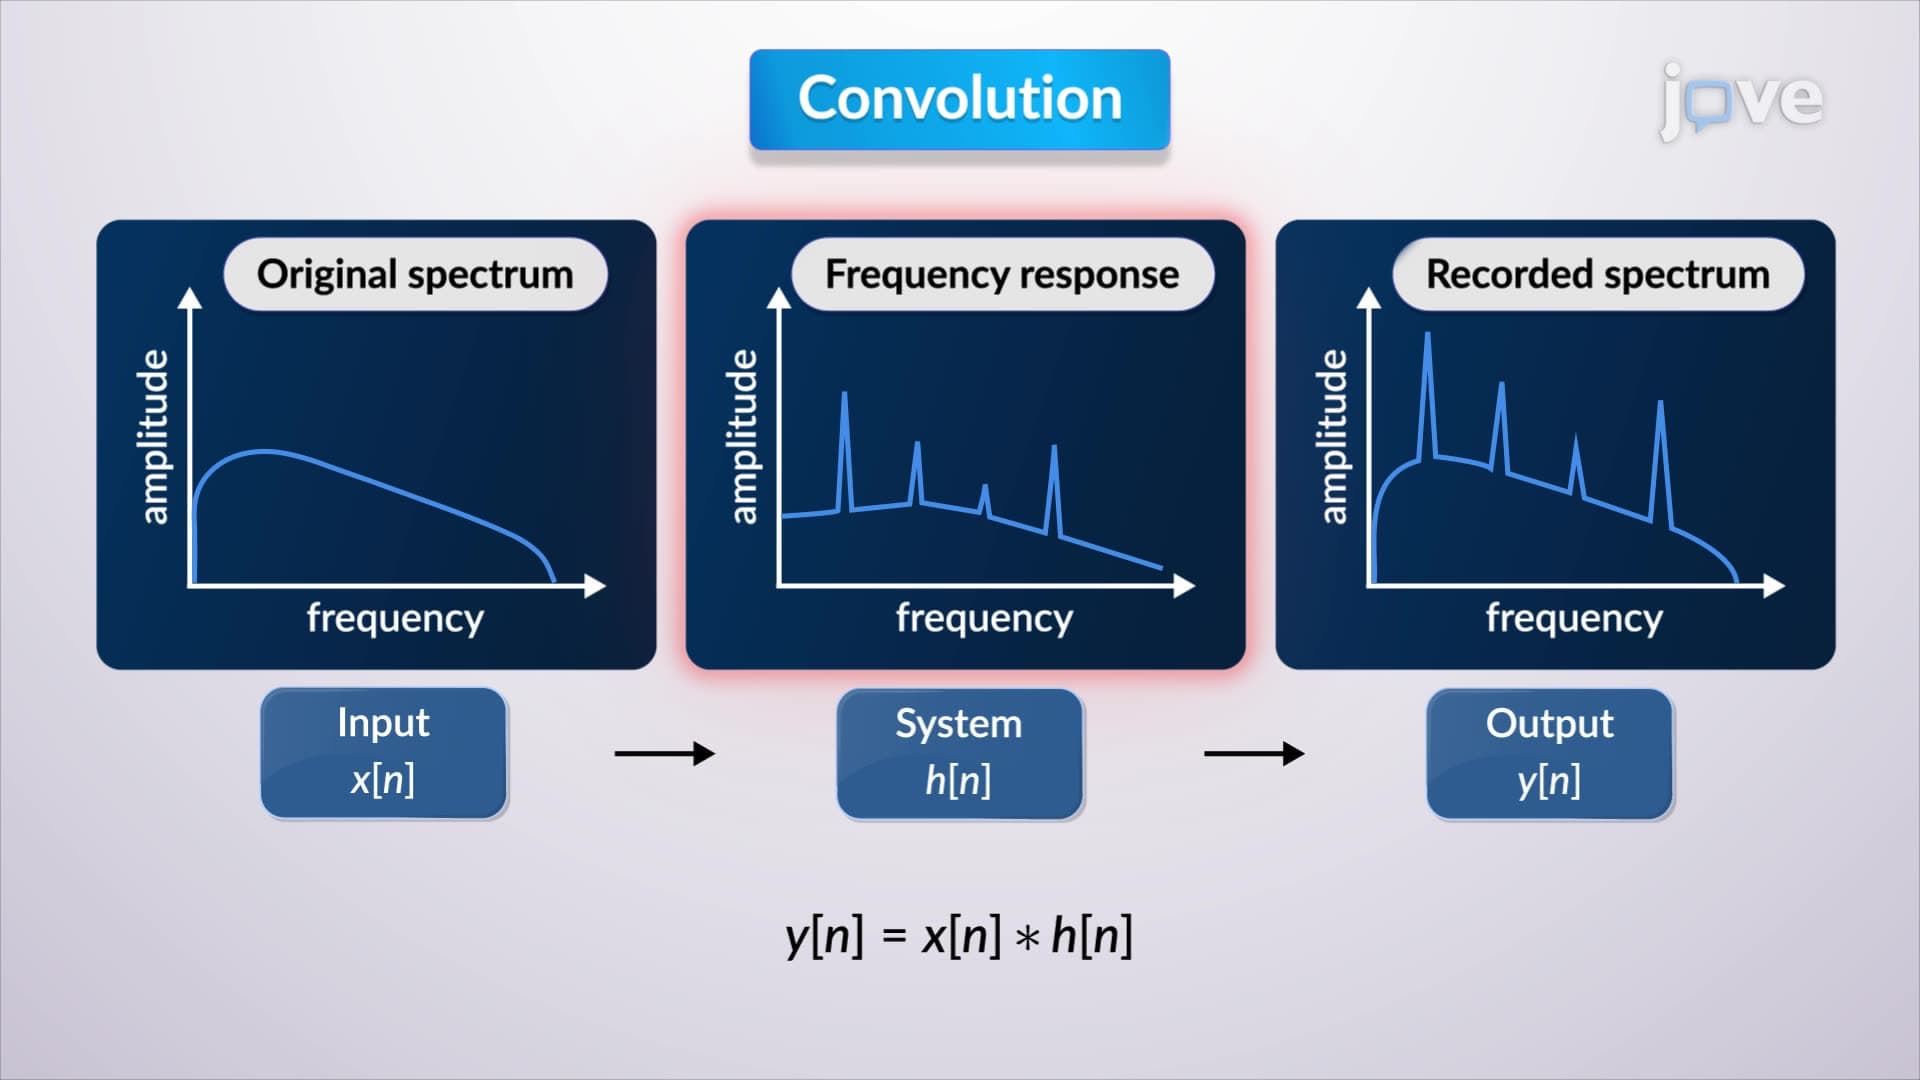
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:22
Multi-input and Multi-variable systems
In the absence of...