Related Experiment Video
Updated: Oct 14, 2026
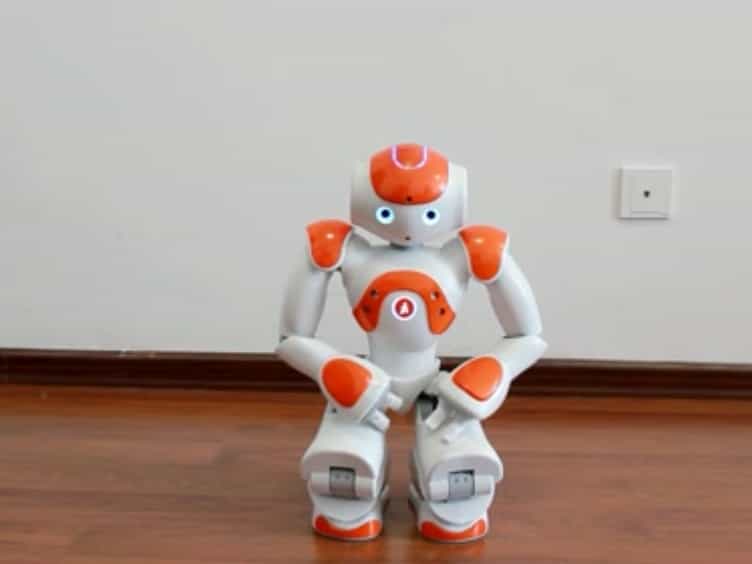
SSVEP-based Experimental Procedure for Brain-Robot Interaction with Humanoid Robots
Published on: November 24, 2015
Toward brain-trained humanoid robots
1Ouroboros Neurotechnologies, Lausanne, Switzerland.

Abstract:
A growing corpus of experimental research demonstrates that neuroimaging data can be leveraged to improve the performance of artificial intelligence models, including reinforcement learning models in robotics. However, most existing studies have focused on vision, audition, language, or reward and error signals recorded while the human brain acts as an observer. In this paper, we argue that humanoid robots, although not equivalent to humans, could offer a unique opportunity to use the neural signals associated with touch, or other embodiment-dependent neural signals. As a result, humanoid robots could significantly expand the range of brain regions and functional networks that could be targeted for brain-trained artificial intelligence, and open new horizons in terms of alignment and reasoning. We discuss the improvements that neuroimaging data could potentially unlock in the context of sensorimotor tasks, spatial navigation, sensorimotor integration, embodied alignment, embodied reasoning, and social integration, as well as the broader challenges and opportunities related to brain-trained humanoid robots.

Related Concept Videos
 01:30
Machines: Problem Solving II
 01:26
Transformers
The iron core has a substantial relative permeability. Therefore, the magnetic field lines generated due to the current in one winding are almost entirely confined within the core, such that the same magnetic flux permeates each turn of both...
 01:22
Mechanical Systems
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:18
Hierarchy of Motor Control