Related Experiment Video
Updated: Oct 15, 2026

Operation of the Collaborative Composite Manufacturing (CCM) System
Published on: October 1, 2019
Analytical Kinematic Model and RCM Control of a Parallel-Serial Steady-Hand Eye Robot
Botao Zhao1, Mojtaba Esfandiari1, Teng Long1
1Laboratory for Computational Sensing and Robotics, Johns Hopkins University, Baltimore, MD, 21218, USA.

Abstract:
Maintaining a precise remote center of motion is essential for safe and accurate tool manipulation in retinal microsurgery. However, existing numerical Jacobian identification methods for parallel manipulators often exhibit nonlinear, workspace-dependent inaccuracies and require frequent recalibration, limiting their reliability and clinical applicability. To address these challenges, this study presents an analytical kinematic framework for a hybrid parallel-serial robot designed for retinal surgery, known as the Steady-Hand Eye Robot (SHER 3.0). Closed-form solutions for forward and inverse kinematics, as well as analytical formulations of the direct and inverse Jacobians, are derived to ensure consistent motion estimation across the workspace. The kinematic performance of SHER 3.0 is analyzed to evaluate the manipulability and workspace efficiency. Building on these models, a model predictive control strategy is implemented on SHER 3.0, which maintains the remote center of motion constraint at the sclerotomy with sub-millimeter accuracy, with a root mean square error of 0.55 ± 0.12 mm, in a pilot study on a teleoperation experiment. Experimental results demonstrate the effectiveness of the proposed analytical models and control framework in enhancing robot motion stability and robustness of the controller in maintaining the remote center of motion constraints, enabling safe robot-assisted retinal microsurgery.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
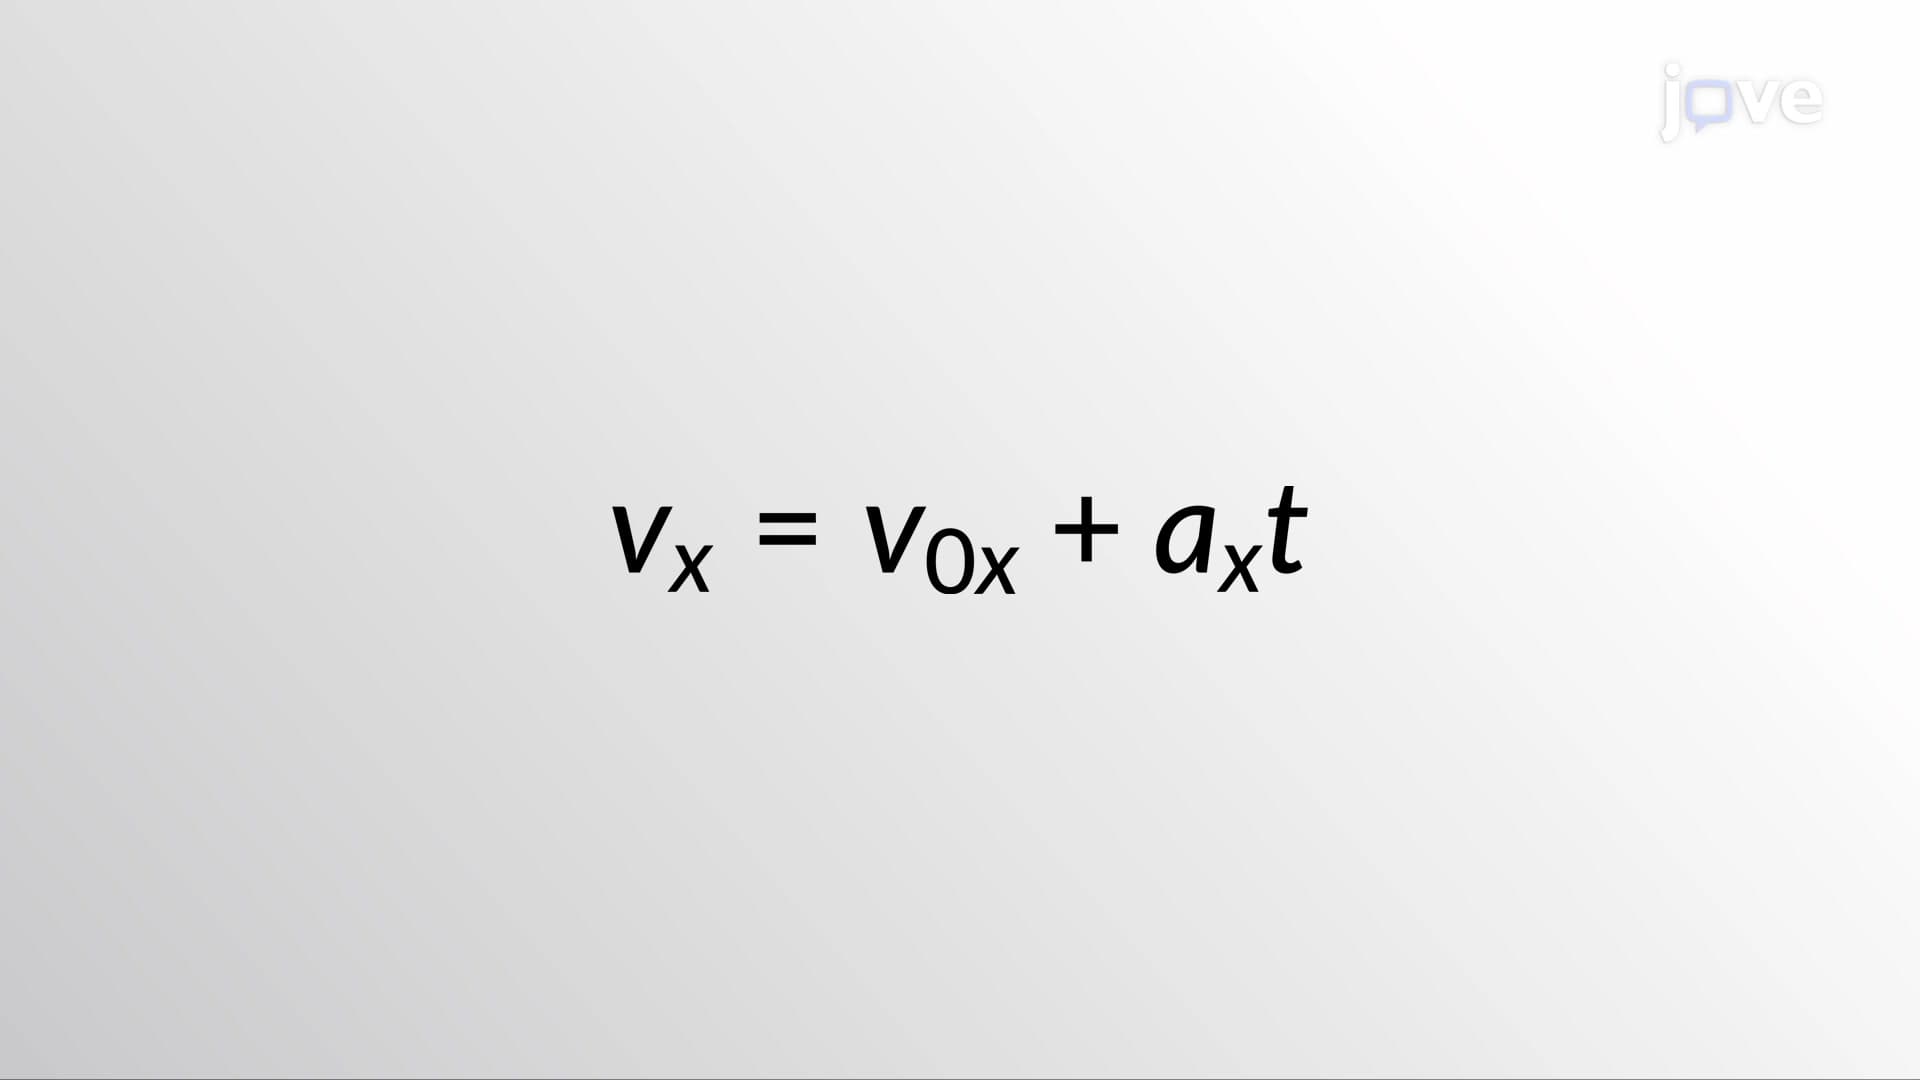 01:26
Kinematic Equations - I
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...