Related Experiment Video
Updated: Oct 15, 2026
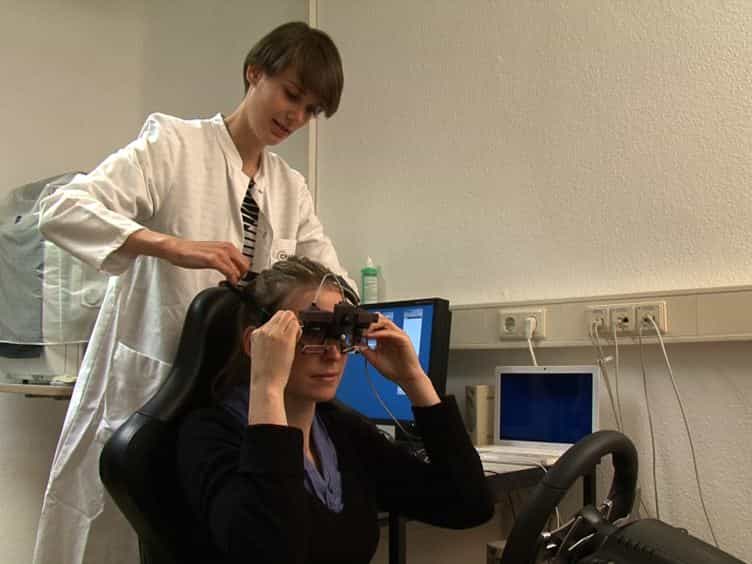
Driving Simulation in the Clinic: Testing Visual Exploratory Behavior in Daily Life Activities in Patients with Visual Field Defects
Published on: September 18, 2012
Human-guided continual learning for multifaceted improvement of self-driving vehicles
Haohan Yang1, Yanxin Zhou1, Xiaosong Hu2
1School of Mechanical and Aerospace Engineering, Nanyang Technological University, Singapore, Singapore.

Abstract:
Today's self-driving vehicles have achieved impressive driving capabilities, nonetheless, safety concerns arising from ambiguous traffic laws, rare long-tail events, etc., still pose a significant challenge to their practical deployment. Therefore, human drivers are necessitated to take over in certain cases. Here, we present a human-guided continual learning method that leverages these human guidance data to continually improve self-driving performance, thereby enabling better handling of similar cases in the future. Our technique facilitates performance improvement by merely using the new data collected during driving, without requiring lengthy re-training from scratch. We evaluate the proposed technology through both simulations and real-world experiments, showing that it enables continual improvement by incrementally acquiring small amounts of human guidance. After each learning stage, the updated policy matches or outperforms the previous self-driving policy in terms of social compliance, rare case handling, etc. These findings highlight the potential of this technology to continually improve self-driving vehicles across multiple dimensions and to support broader human-in-the-loop autonomous systems.
Related Concept Videos
 01:22
Purposive Learning
 01:18
Hierarchy of Motor Control
 01:12
Observational Learning
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:28
Automatic Processing and Automatic Social Behavior