Related Experiment Video
Updated: Oct 16, 2026
Visualization Method for Proprioceptive Drift on a 2D Plane Using Support Vector Machine
Published on: October 27, 2016
Motion uncertainty visualization based on Gaussian process regression
Bojan Kocev1, Horst Karl Hahn2, William M Wells3
1Department of Computer Science and Electrical Engineering, Constructor University Bremen, Bremen, Germany; Fraunhofer Institute for Digital Medicine MEVIS, Bremen, Germany; Institute of Computer Science, University of Münster, Münster, Germany; Department of Mathematics and Computer Science, University of Bremen, Bremen, Germany.

Abstract:
In the context of image-guided soft-tissue intervention and surgery navigation, soft tissue motion estimation for a deformed/registered pre-operative/pre-interventional medical image may suffer from multiple sources of uncertainty. Visualizing the uncertainty in the deformed image is of great interest because it conveys the uncertainty in the registered pre-interventional/pre-operative navigation information on deformable soft-tissue organs governing the decisions of the surgeon or intervention specialist. We address the problem of propagating the uncertainty from a Gaussian process (GP)-based motion estimation of an input image. To visualize the deformed image itself, we show its maximum a posteriori (MAP) estimate. To convey the overall uncertainty in the MAP deformed image estimate, we apply a spatially-varying blur (according to the uncertain motion estimate) to an image containing a grid and combine it with the MAP deformed image itself. We show 2D cross sections of the final image that convey both the deformed image and its uncertainty. We further extend our approach to local investigations of points or regions of interest (e.g., a tumor). To visualize where a point/region of interest (POI/ROI) is after deformation, we estimate marginal (i.e., per voxel) label (e.g., for being a tumor) probabilities (MLPs) based on an input probabilistic segmentation of the ROI in the non-deformed pre-interventional/pre-operative image and the input GP posterior distribution over deformation fields and show 2D cross sections of visually mapped MLPs or MLP isocontours.

Related Concept Videos
 00:59
Uncertainty: Overview
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:27
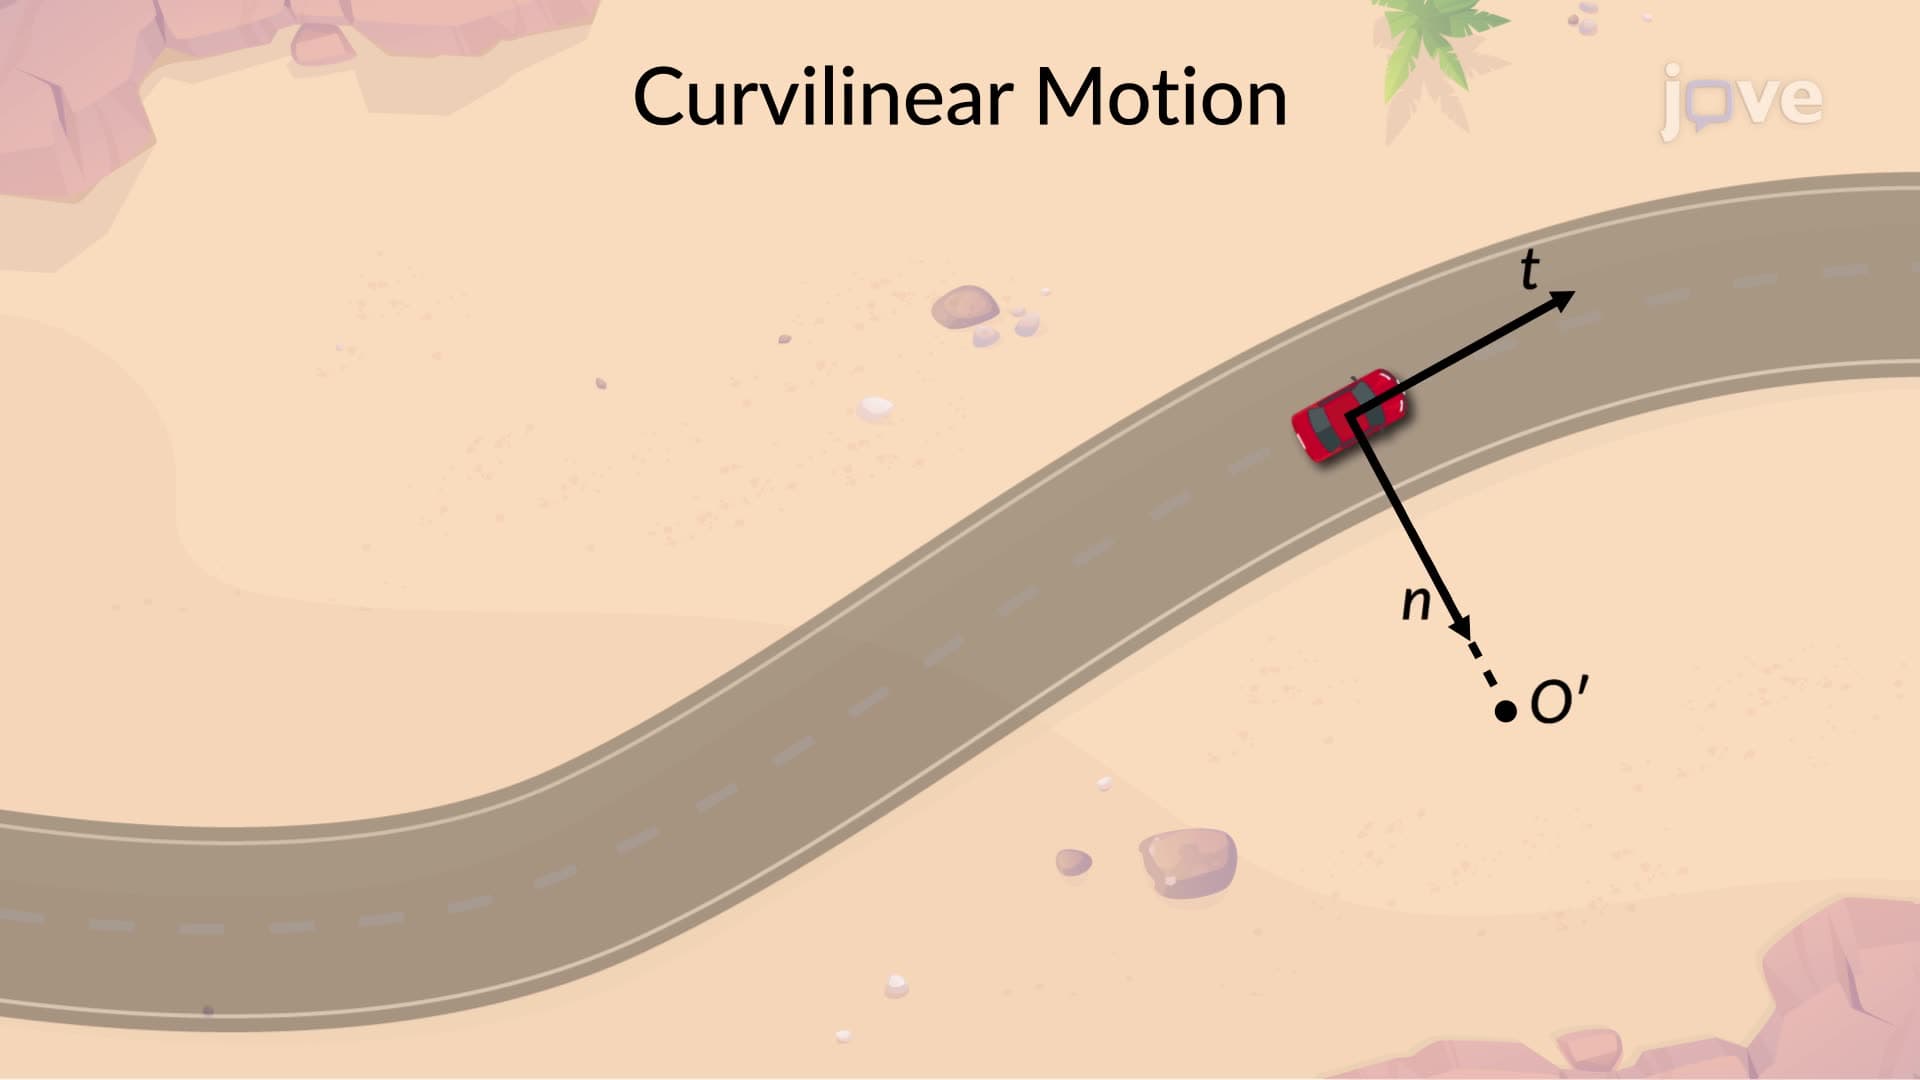
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...