Related Experiment Video
Updated: Oct 16, 2026
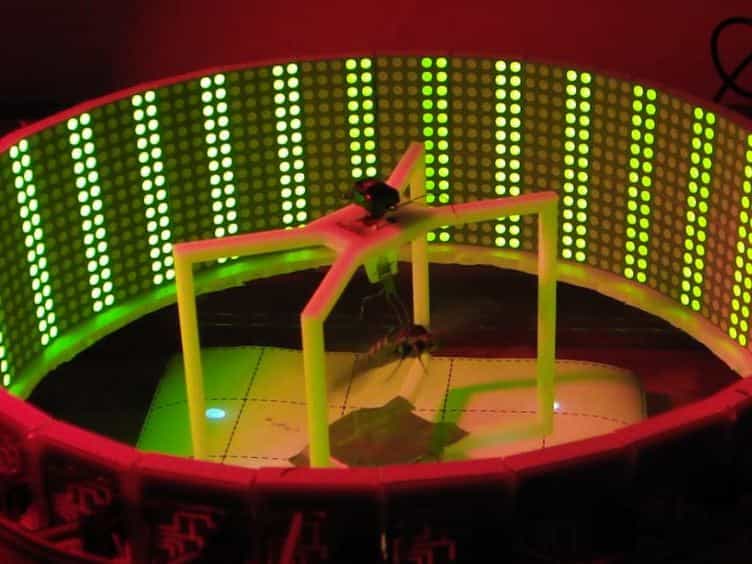
Early Metamorphic Insertion Technology for Insect Flight Behavior Monitoring
Published on: July 12, 2014
Wing pitch timing and wing elevation modulate forces and body pitch in forward flapping flight
Victor Colognesi1, Christoffer Johansson2
1Biology department, Lund University, Naturvetarvägen 6A, Lund, 22362, Sweden.

Abstract:
Aerodynamic performance in flying animals can be controlled not only by changes in wing shape and size, but also by changes in wing motion. In flapping wings, the two wings interact aerodynamically, where the interaction depends on wingbeat phase, wing proximity, and wing attitude. Although, observations of free-flying animals show wings are relatively close during forward flight, how these interactions influence force production remain unclear. Here we used a robotic flapping wing and quantitative flow measurements to test the effect of wing interactions while varying mean wing elevation and pitch timing during upstroke-downstroke transitions. We show that both force magnitude and direction depend strongly on these parameters and their interaction. The fitted response models showed that high wing position combined with early pitching maximized vertical force, whereas low-to-mid wing position with synchronized-to-late pitching increased thrust. Efficiency metrics were highest near mid-to-high wing position combined with late pitching. In addition, we found that transition phases strongly affected thrust generation and produced substantial body pitch torques. These findings demonstrate that small kinematic adjustments can markedly alter aerodynamic performance and be used for tailless flight control. This offers mechanistic explanations for observed animal wing motions and novel strategies for controlling flapping drones.
Related Concept Videos
 01:23
Lift
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:54
Convergent Evolution
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:17
Turbine-Governor Control