Related Experiment Video
Updated: Oct 16, 2026

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A new hybrid optimization intelligence for cable-driven continuum robot motion: two-obstacle simulation and real-data
Selman Djeffal1, Abdelhamid Ghoul2, Mohamed Razi Morakchi3
1Department of Mechanical Engineering, National Polytechnic School of Constantine, Constantine, Algeria.

Introduction:
Cable-driven continuum robots enable dexterous motion in confined spaces, but inverse kinematics remains difficult because different internal shapes and cable states can produce the same end-effector position.
Methods:
This study presents a design-aware hybrid optimization framework, DA-IHHO-DELS, for inverse kinematics of a three-section continuum robot. A piecewise-constant-curvature forward model generates physically consistent section positions, cable-length estimates, and feasibility terms. The optimizer combines geometry-consistent seeding, opposition learning, improved Harris hawks search, differential-evolution exploitation, grey-wolf leader guidance, Cauchy/Levy perturbations, and bounded local refinement. Its multi-objective score includes the arc-length consistency residual, orientation error, cable-length dispersion, inter-section smoothness, actuation effort, and constraint violation, and it is compared with GA, ABC, ACO, DE, HHO, TLBO, BOA, GWO, WOA, and POA.
Results:
In the regenerated obstacle-constrained simulation, DA-IHHO-DELS achieved a median residual of 0.00491 mm, a median reconstructed Cartesian error of 0.00255 mm, 100% success under the strict criterion, the lowest median aggregate score, and a mean runtime of 0.56883 s. A secondary benchmark using measured CBHA/Robotino XT actuator lengths further assessed transfer of the geometry-guided optimization consistency to real measured continuum-robot data.
Discussion:
The results show that design-aware hybrid optimization can combine analytical continuum-robot kinematics with robust search to obtain accurate, feasible, and smooth inverse-kinematic solutions. The real-data benchmark supports consistency transfer while remaining distinct from a direct hardware test of the same three-section cable-driven robot.
Related Concept Videos
 01:30
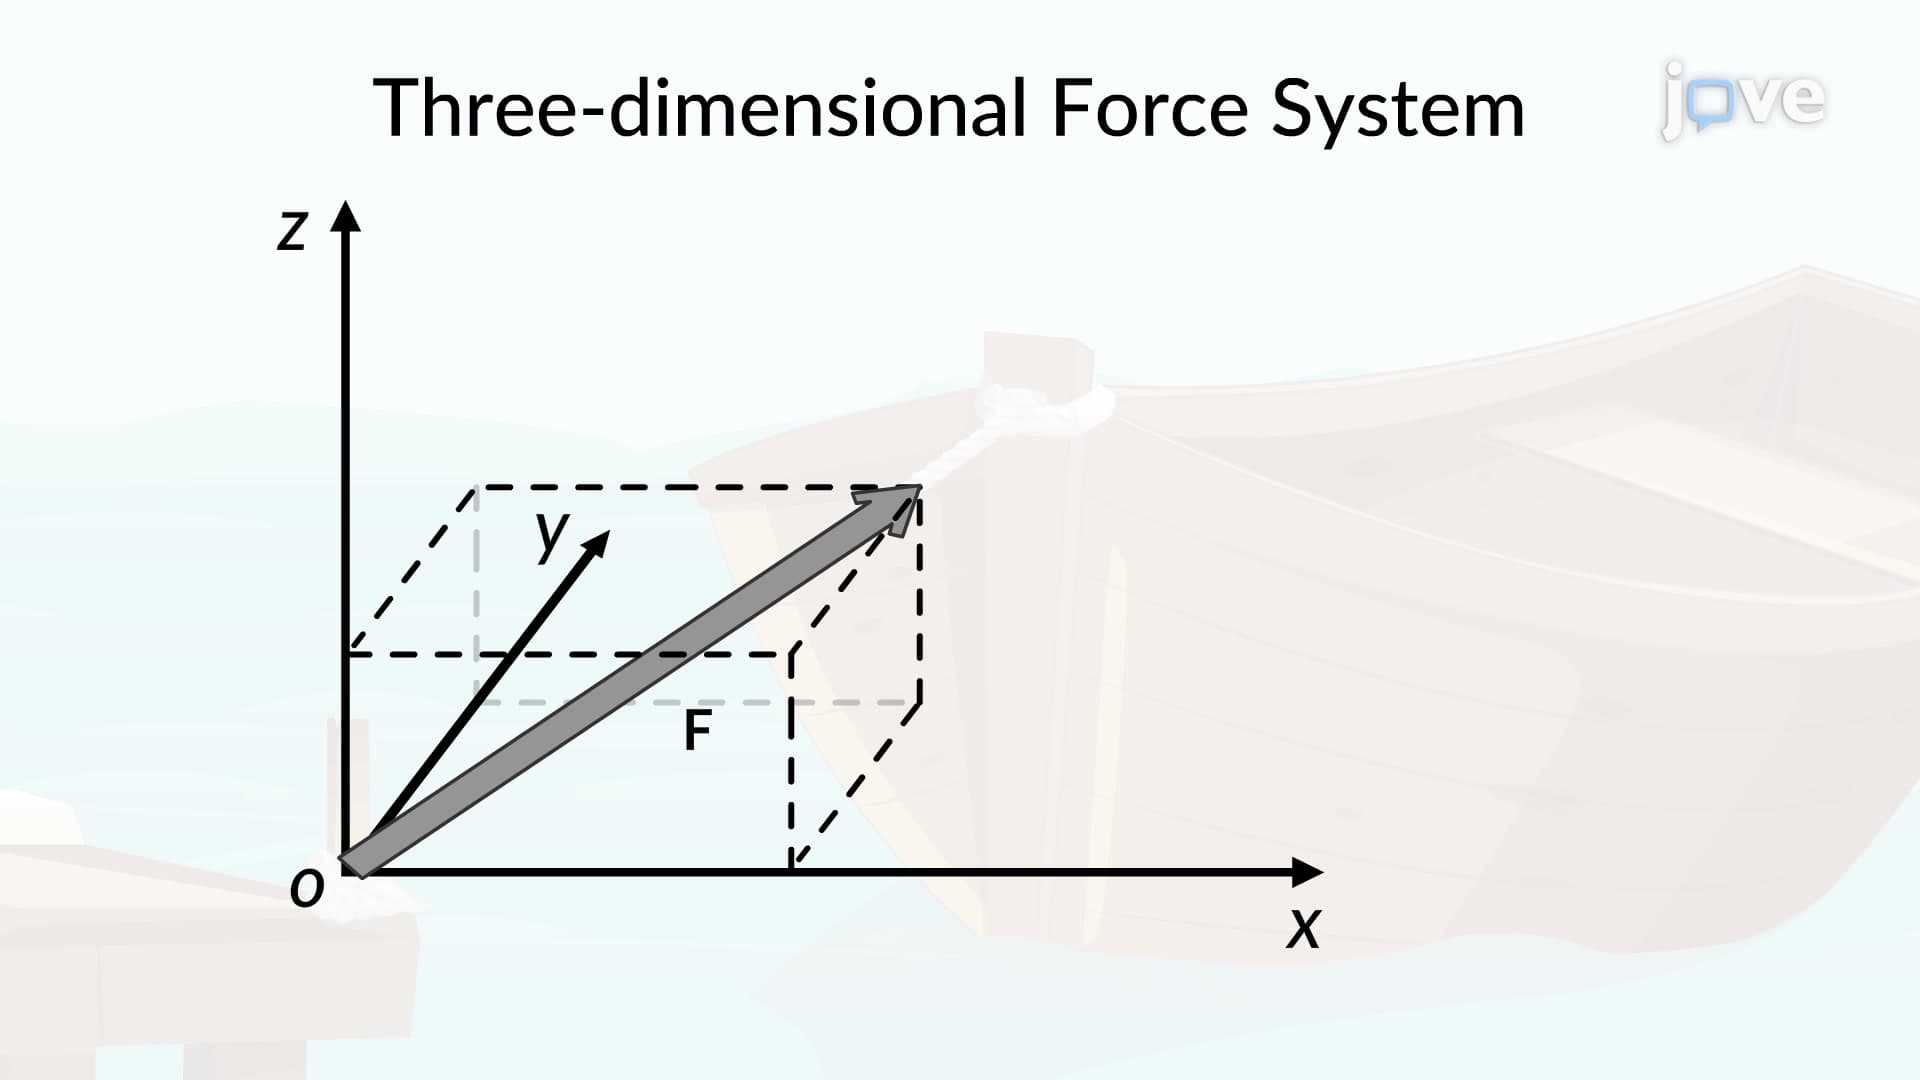
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Vector Functions and Motion: Problem Solving
 01:30
Three-Dimensional Force System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...