Related Experiment Video
Updated: Oct 17, 2026
Fabrication of Magnetic Platforms for Micron-Scale Organization of Interconnected Neurons
Published on: July 14, 2021
Programmable Spatiotemporal Magnetic Fields for Selective Multimodal Actuation and Deterministic Decoupling of
Armando Ramos-Sebastian1, Ja Sung Lee2, Sung Hoon Kim2,3
1Center for Advanced Photonic Materials, College of Science and Technology, Korea University, Sejong, Republic of Korea.

Abstract:
Magnetic milli/microrobots hold strong potential for biomedical applications, but their deployment as multi-robot systems is limited by short-range magnetic coupling, which prevents independent control in confined environments. Here, we present an expanded field-free region (FFR)-based control framework for spatially selective actuation of multiple magnetic torque-driven robots in confined environments. A generalized selective-control criterion incorporating the minimum rotating magnetic field required for robot actuation enables the framework to accommodate robots with different magnetic responses and operating conditions. Through programmable displacement and oscillation of the FFR, the framework extends conventional selective locomotion to include velocity regulation under a constant rotating magnetic field and oscillation-induced stick-slip locomotion. For strongly interacting permanent-magnet robots, a dedicated decoupling field reorients their magnetic moments to transition the inter-robot interaction from attraction to repulsion, enabling subsequent deterministic separation, whereas weakly interacting low-remanence robots can be separated using conventional FFR-based selective locomotion without dedicated decoupling. The framework is validated across different fluid viscosities and robots with distinct magnetic properties and is further integrated with robot redistribution and FFR-selective magnetic heating to achieve spatially regulated thermal responses. Finally, proof-of-concept demonstrations show clot-removal and targeted-delivery emulation and selective robot navigation in a 3-dimensional cerebrovascular phantom. These results establish an expanded FFR-based framework for sequential selective control of magnetic robots in confined environments and support its potential use in imaging-compatible robotic platforms for biomedical interventions.
More Related Videos
Related Concept Videos
 01:13
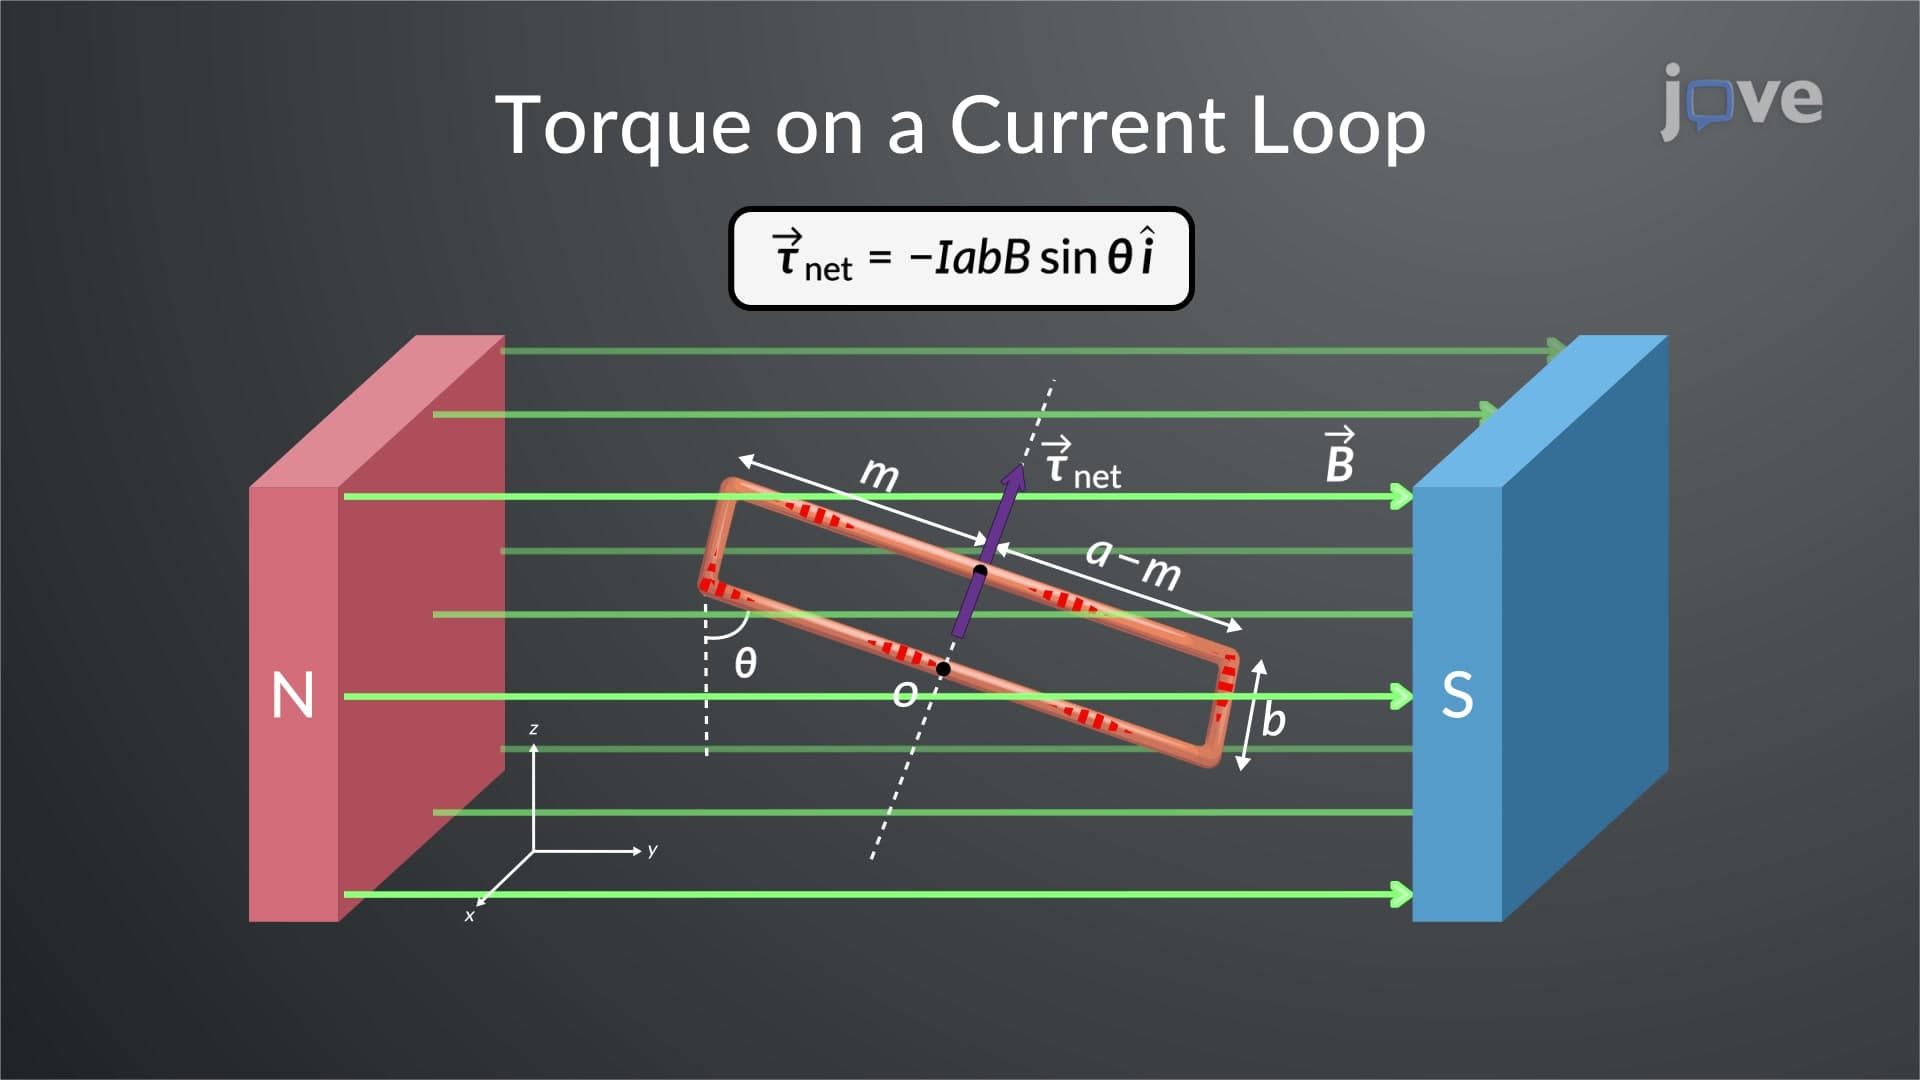
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:17
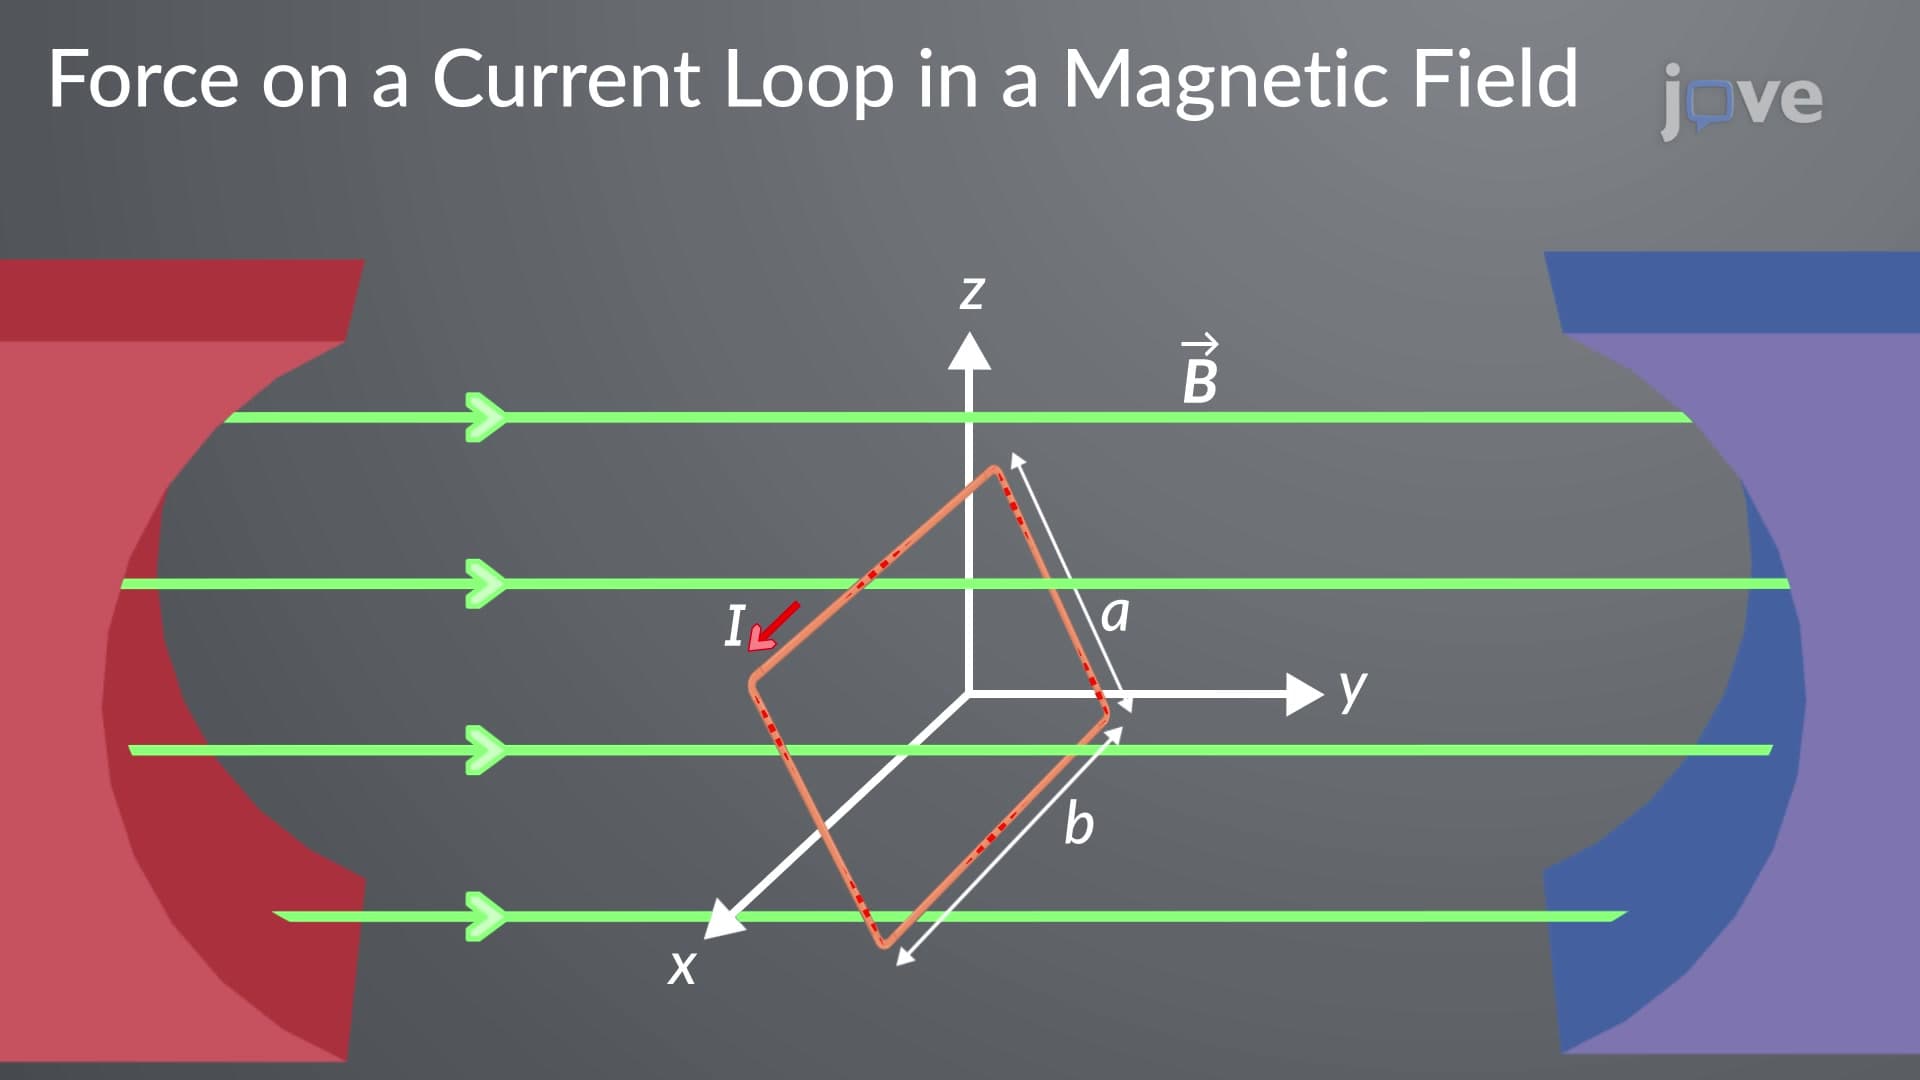
Force On A Current Loop In A Magnetic Field
 01:30
Magnetism
An individual magnetic pole cannot be isolated. No matter how small, every piece of a magnet contains a north pole and a south...
 01:16
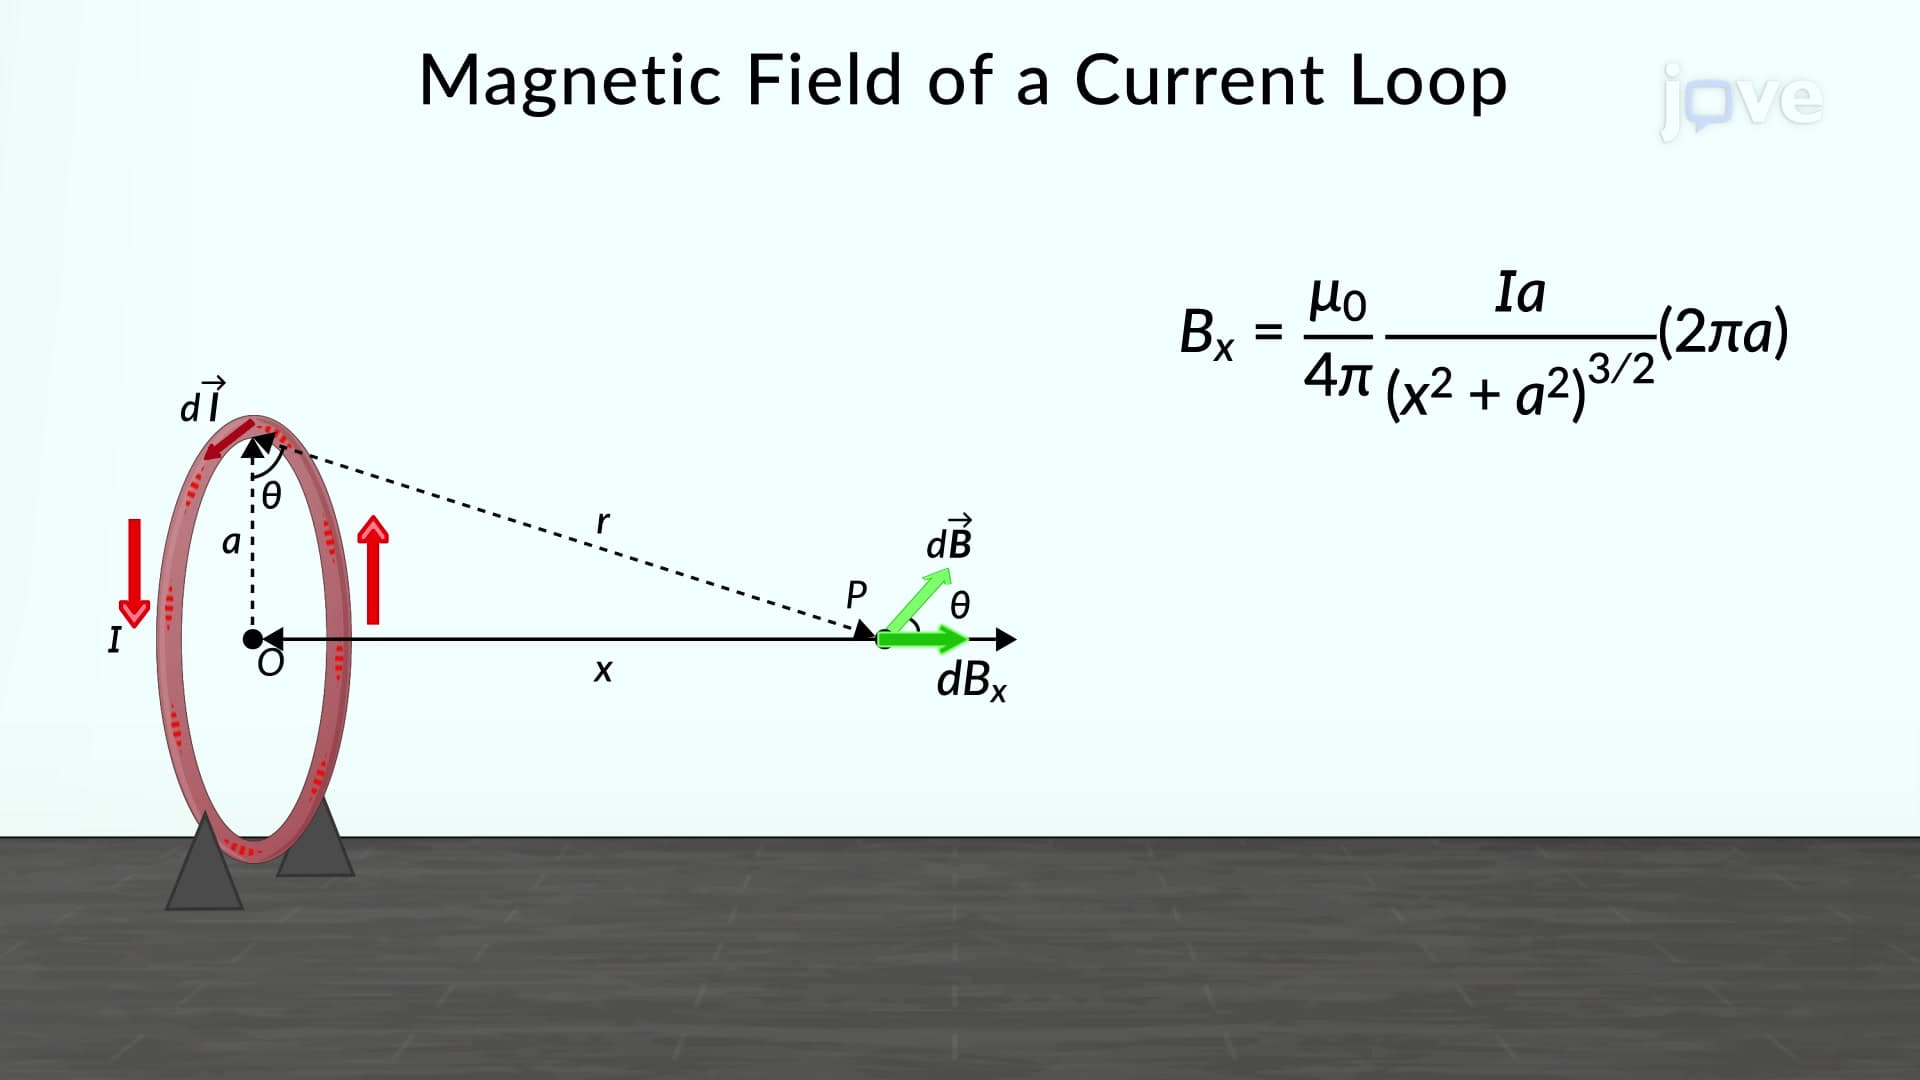
Magnetic Field Of A Current Loop