Related Experiment Video
Updated: Oct 17, 2026
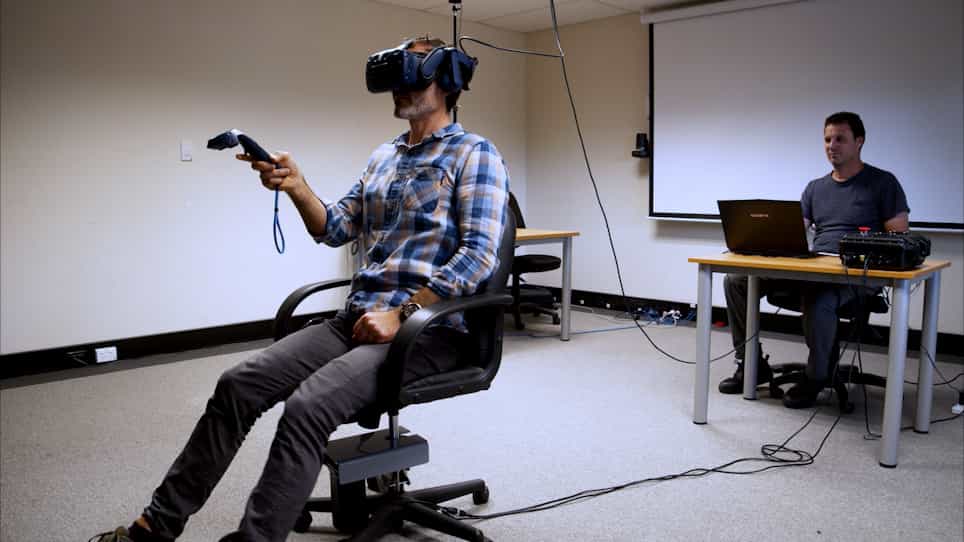
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Subjective equality of visual self-motion and walking speed in virtual environments depends on the field of view
Patricia R Mueller1, Wolfgang Einhäuser1
1Physics of Cognition Group, Institute of Physics, Chemnitz University of Technology, Germany.

Abstract:
Typical visual displays cover only a fraction of the visual field. How do such restrictions influence the perception of visual speed during self-motion? While surrounded by a panoramic screen on which an alley of terraced houses was presented, participants walked at constant speed on a treadmill. They adjusted the speed of the visual scene to match their subjectively experienced walking speed. We manipulated which areas of the visual field remained visible. Only this effective Field of View (FoV) contributed to stimulation by scene motion, while the remainder of the scene was replaced by a homogenous grey overlay with no optic flow. We found that the central part of the visual field needs to be presented substantially faster than the actual walking speed to be perceived as matching. This ratio of visual to actual walking speed ("gain") is lower for equally sized parts of the visual periphery. This result is mainly explained by motion-energy density, but there are also unique contributions of size and position in the visual field (including interaction of the three). There is substantial inter-individual variability in the overall gain perceived as optimal, which is in part explained by step length, but shows no relation to anthropometric measures (body height, leg length). Our results quantify the contribution of different visual field areas to motion perception in complex scenes and are of specific relevance for simulating self-motion, especially in virtual-reality setups with limited horizontal FoV.

Related Concept Videos
 01:10
Relative Velocity in One Dimension
 01:15
Depth Perception and Spatial Vision
 01:11
Relative Velocity in Two Dimensions
 01:03
Inertial Frames of Reference