Related Experiment Videos
Digital Twin-Enabled Vehicle Routing in Logistics and Transportation
Amir Alavi1, Hamidreza Alavi2,3
1Faculty of Commerce and Business Administration, Department of Business, Douglas College, 700 Royal Ave, New Westminster, BC V3M 5Z5, Canada.

Abstract:
Vehicle routing in modern logistics increasingly depends on live sensing: GPS and Internet-of-Things telemetry, roadside perception, and vehicle-to-everything (V2X) data streams change the operational state faster than static route plans can absorb. Digital twins have been proposed to link real-time sensing with routing decisions, yet the literature is fragmented across production, emergency, urban, supply-chain, and Internet of Vehicles (IoV) domains. This systematic review synthesizes 30 peer-reviewed studies of digital-twin-enabled vehicle routing retrieved by a two-stage search of Scopus, ScienceDirect, IEEE Xplore, and Google Scholar, and reported in accordance with PRISMA 2020. Each study was coded for domain, digital-twin role, coupling granularity, evidence maturity, evidence type, and evidence confidence. Four roles recur in the routing loop: monitoring and synchronization; simulation and training; adaptive re-optimization; and infrastructure, data governance, and model management. Twenty-five studies contribute primary evidence and five are conceptual or secondary review sources; simulation-only validation dominates (19 of 30 studies), and only three studies are validated on industrial or field data, so reported operational benefits remain largely unconfirmed. No meta-analysis was performed, because the corpus is too heterogeneous for pooled estimation. The review contributes a role taxonomy, an evidence-maturity mapping, and a routing-specific reference architecture in which synchronization quality, decision latency, and sensor-data governance are proposed as first-class design variables, together with three testable design hypotheses and a research agenda for sensing-driven, cyber-physical routing systems.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:27
Curvilinear Motion: Normal and Tangential Components
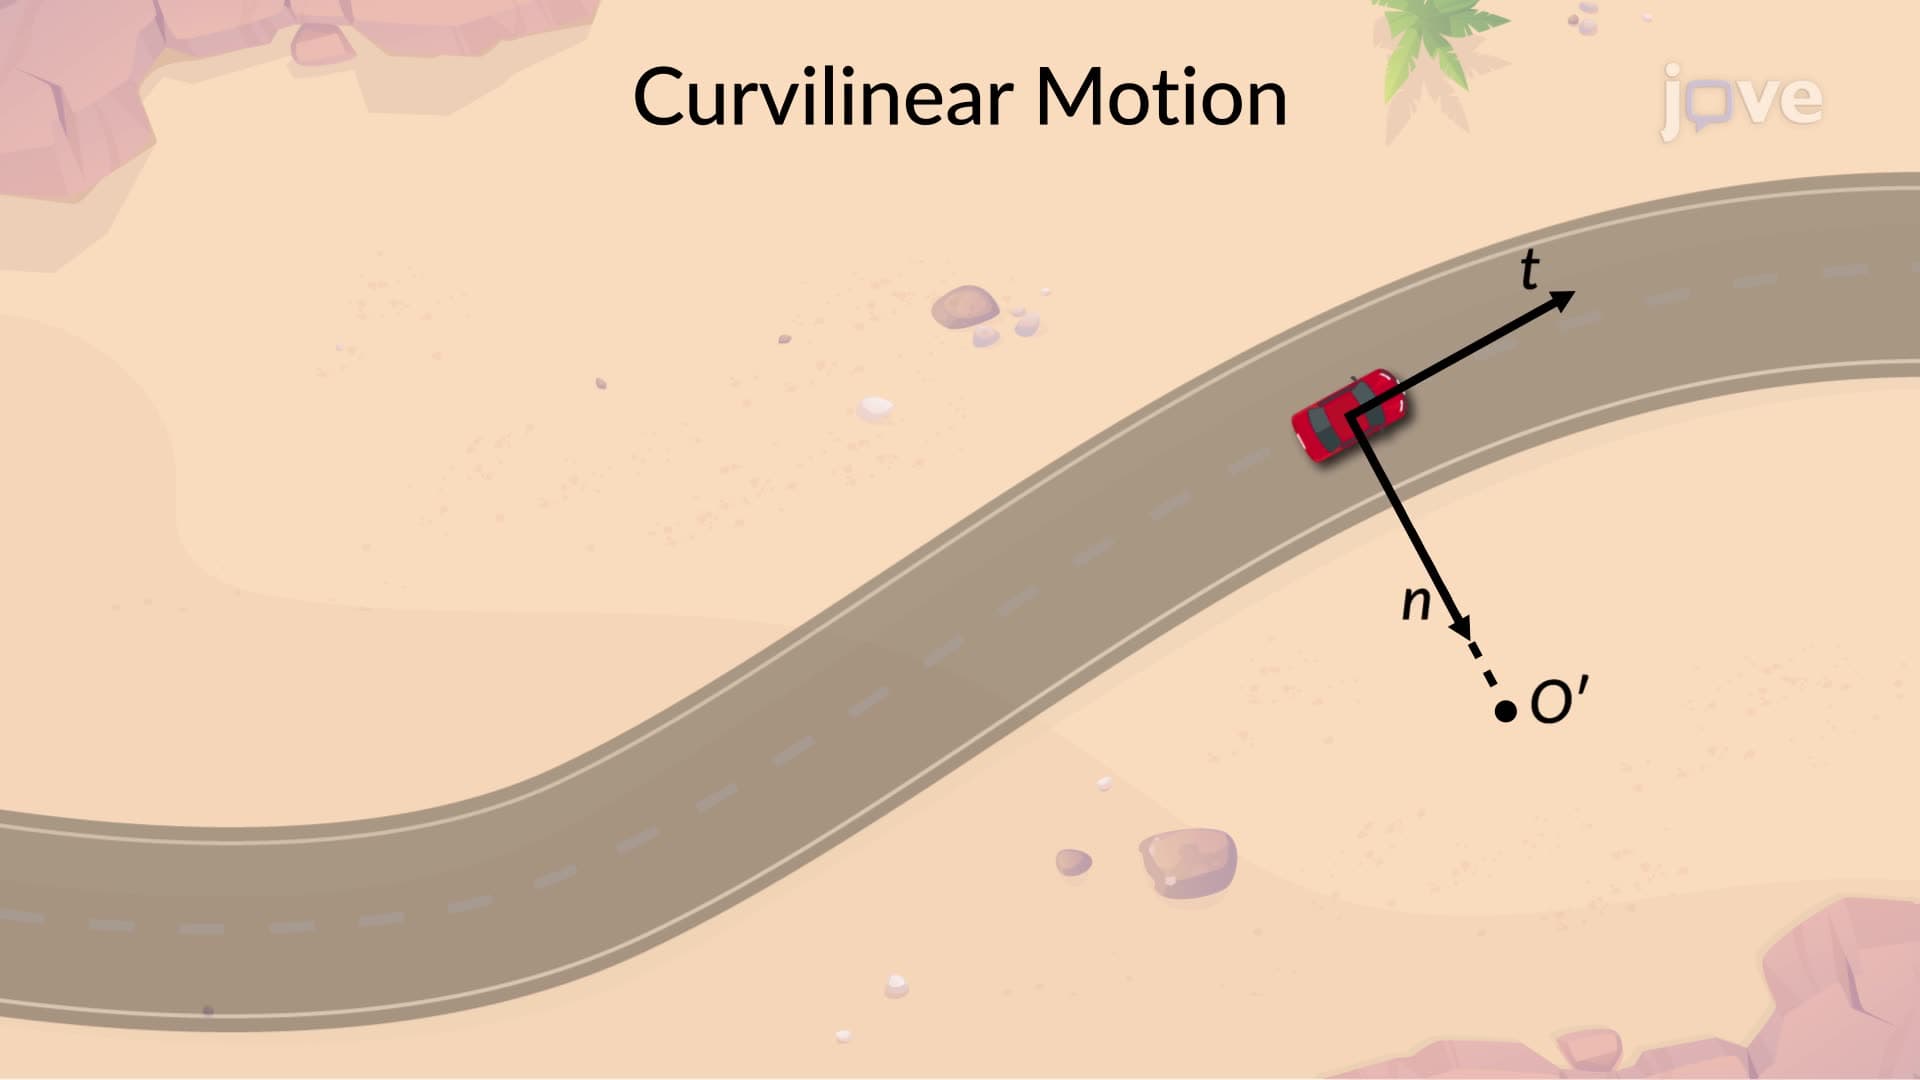
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...