Related Experiment Videos
Dynamic-Weight Fusion of 3D Pose Guidance and Image-Based Visual Servoing for Pre-Contact Alignment in Marine
Wenxing Sun1, Duanjiao Li2, Junwen Yao2
1Guangdong Power Grid Co., Ltd., Guangzhou 510030, China.

Abstract:
The small-clearance assembly of marine engineering equipment requires the robot to correct coupled pose deviations before contact while retaining fine local alignment. This paper presents an eye-in-hand red, green, and blue plus depth (RGB-D) controller that computes a 3D pose-guidance velocity and an image-based visual-servoing (IBVS) velocity in parallel. Distance and attitude-angle errors set a bounded gain on the 3D branch, while the IBVS gain remains fixed; both velocities are expressed in the same six-dimensional end-effector frame. Each of three initial-deviation conditions was repeated five times for IBVS, 3D Pose Guidance, and Dynamic Fusion. With convergence defined as a mean 3D feature error below 0.3 mm for 30 consecutive frames, Dynamic Fusion reached the threshold and ended within it in all 15 clean trials. IBVS ended within the threshold in 14 of 15 trials and 3D Pose Guidance in 12 of 15. Under combined deviation, Dynamic Fusion converged in 17.73±1.43 s, compared with 24.14±4.81 s for IBVS, and had a terminal error of 0.214±0.011 mm. With injected camera-end-effector calibration perturbations, Dynamic Fusion retained 10/10 terminal successes, whereas 3D Pose Guidance retained 7/10. A single terrestrial physical demonstration showed visual alignment followed by successful insertion; it is treated as a feasibility observation rather than a success-rate evaluation. An additional five-trial fixed-gain ablation converged in 10.17±0.34 s with 0.127±0.040 mm terminal error under clean combined deviation, outperforming the recorded dynamic-fusion results in that condition. The evidence supports feasibility within the tested conditions, but it does not establish the superiority of dynamic weighting over fixed-gain fusion.
Related Concept Videos
 01:30
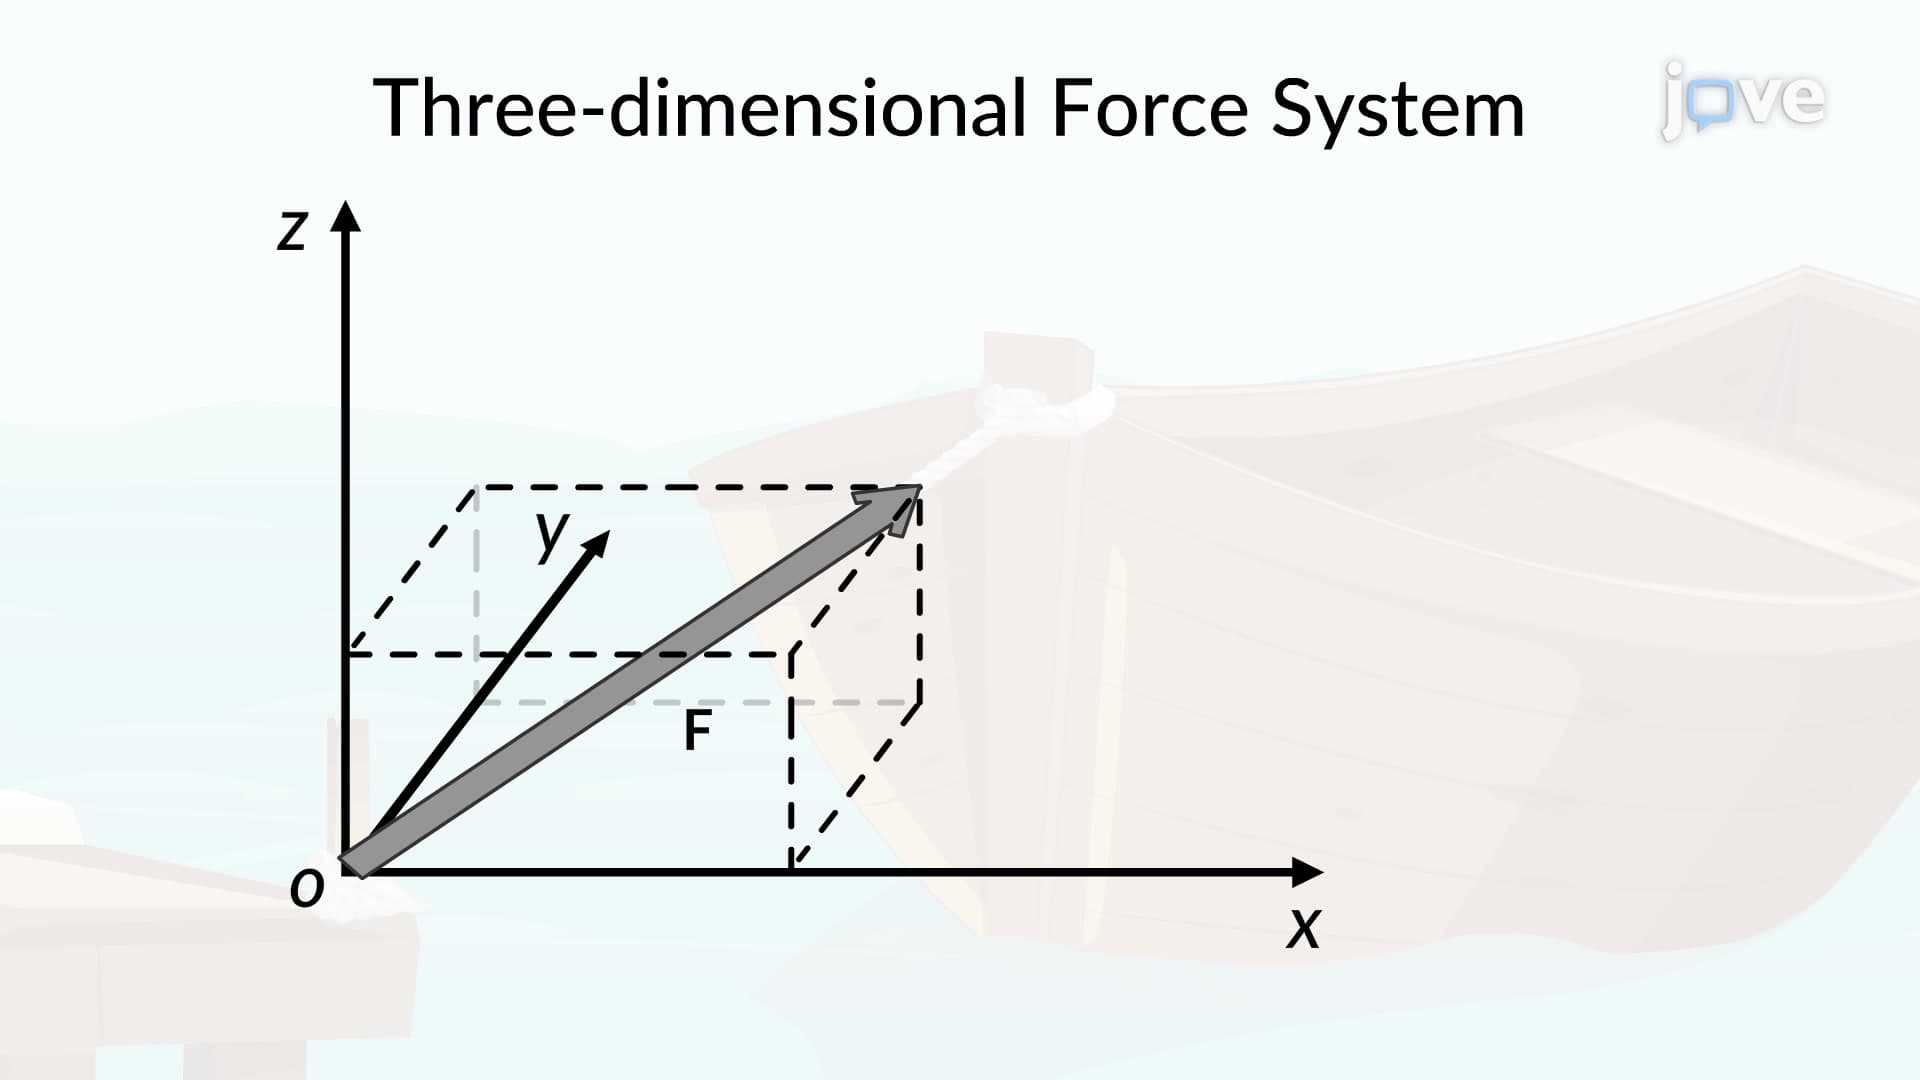
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:11
Deformation of Member under Multiple Loadings
In the case of a member with a variable cross-section, the strain is not constant but depends on the position. The deformation of an...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...