Quantifying Pilot Operational Deviations Based on Flight Data via Inverse Reinforcement Learning and Conformal Prediction
Related Experiment Video
Updated: Oct 17, 2026
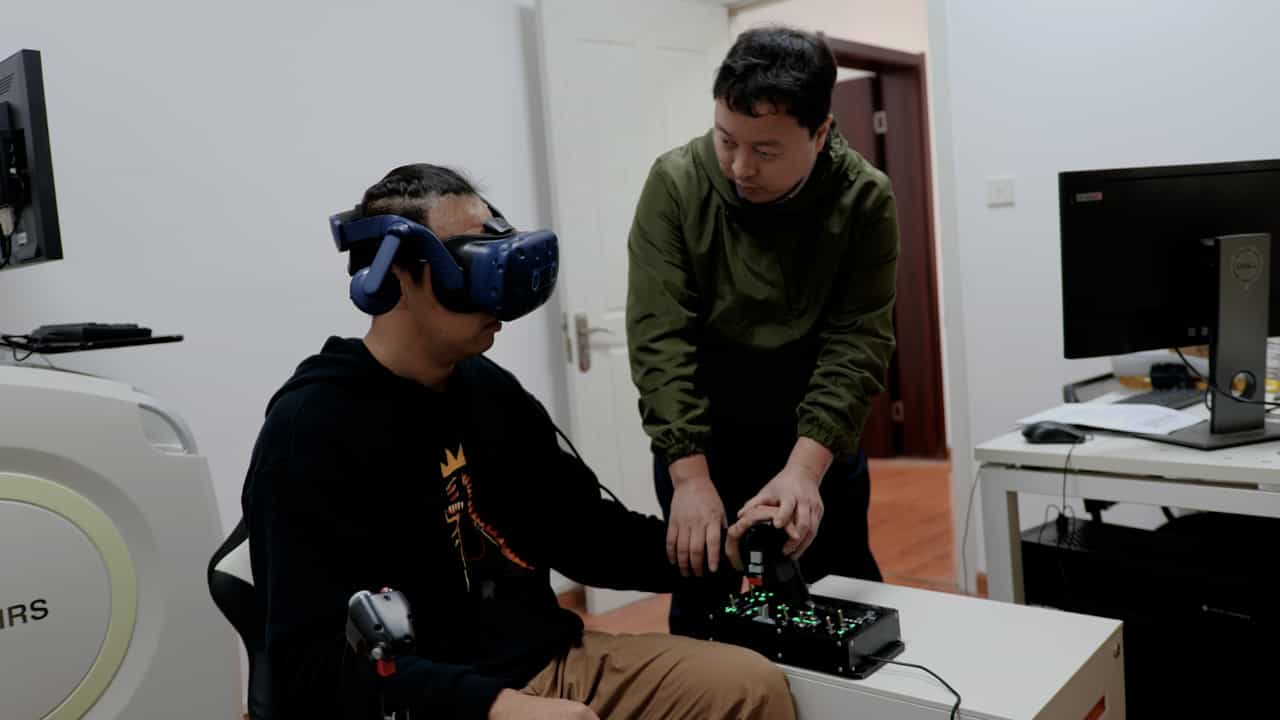
Evaluating Flight Performance and Eye Movement Patterns Using Virtual Reality Flight Simulator
Published on: May 19, 2023
Taoyuan Chen1, Zhenxing Gao1, Yangyang Zhang1
1College of General Aviation and Flight, Nanjing University of Aeronautics and Astronautics, Nanjing 211100, China.

Abstract:
Threshold-based flight data monitoring (FDM) identifies parameter exceedances but provides limited visibility into gradual operational deviation within nominal operating bounds. This study presents a three-layer framework for continuous operational deviation quantification from quick access recorder (QAR) data. A standard operating procedure (SOP)-constrained Gaussian mixture model-hidden Markov model (GMM-HMM) infers 27 procedural states from flight parameters, aligning latent state representation with operational procedure. From these state sequences, maximum entropy inverse reinforcement learning (IRL) recovers an expert value function that estimates execution quality at each time step. Split conformal prediction calibrates detection thresholds with distribution-free coverage guarantees, while counterfactual analysis traces identified deviations to their procedural origin. Learned from real flight data, the recovered reward function assigns 1.6 times greater weight to lateral and speed stability than to vertical stability. Split conformal calibration yields an empirical false alarm rate of 4.2% under a nominal 5% significance level. Counterfactual analysis identifies vertical speed management as the dominant source of procedural deviation. These results support the proposed framework as a candidate continuous safety performance indicator that surfaces gradual operational deviation that threshold-based exceedance monitoring would not flag.
Related Concept Videos
 01:29
Application of Linearization and Approximation
 01:12
Observational Learning
 01:24
PI Controller: Design
 01:30
Vector Functions and Motion: Problem Solving
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:23
Reinforcement
Positive reinforcement occurs when a behavior is followed by the presentation of a rewarding stimulus, increasing the frequency of that behavior. For example: