Related Experiment Video
Updated: Oct 17, 2026
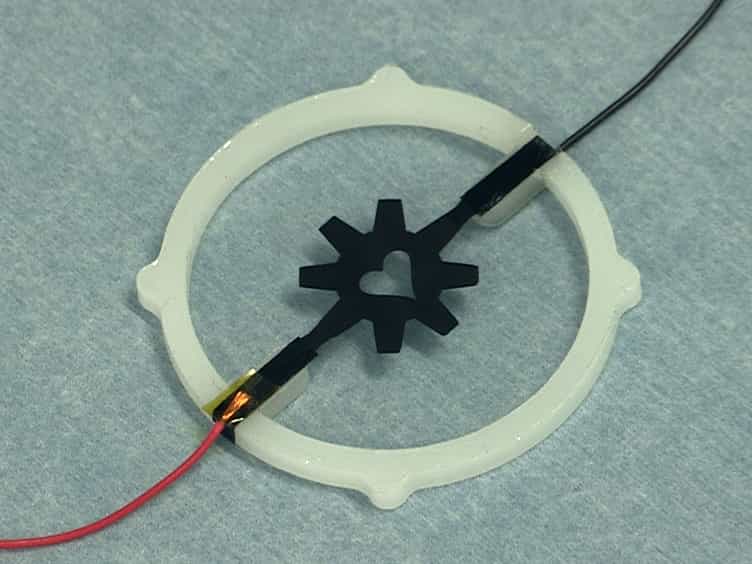
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Polyacrylate-Based Dielectric Elastomer Fiber Actuators for High-Performance Artificial Muscles
Mengke Shi1,2, Jiangshan Zhuo2,3, Junbo Peng2,3
1Department of Polymer Science and Engineering, Zhejiang University, Hangzhou, China.

Abstract:
Dielectric elastomer fiber actuators (DEFAs) are promising candidates for artificial muscle applications, owing to their high axial actuation and mechanical compliance, yet achieving scalable fabrication without compromising electromechanical performance remains a critical bottleneck. Existing continuous manufacturing routes are predominantly restricted to silicone elastomers, which yield limited actuation strains and low energy densities. Here, a continuous fabrication strategy that integrates coaxial wet spinning with in situ ultraviolet curing is developed to produce polyacrylate-based DEFAs (PA-DEFAs) from a bimodal-networked polyacrylate dielectric elastomer at rates up to 22.5 mm s-1. The fiber geometry and electromechanical properties are readily tunable by adjusting the core-to-shell flow-rate ratio and elastomer formulation. The resulting fiber actuators deliver a maximum prestretch-free axial strain of ∼39%, a maximum energy density of 54.8 J kg- 1, and a peak power density of 443 W kg- 1-outperforming previously reported continuously fabricated DEFAs. The long and continuous fiber architecture further enables wrapped actuator and parallel-connected arrays, facilitating seamless integration into diverse soft robotic systems, including a robotic arm, a crawling robot, and an underwater robotic manta-ray with modular fault-tolerance. By reconciling scalable manufacturing with high actuation performance, PA-DEFAs establish a versatile and manufacturing-compatible platform for next-generation artificial muscles and adaptive soft robotics.