Related Experiment Video
Updated: Oct 18, 2026
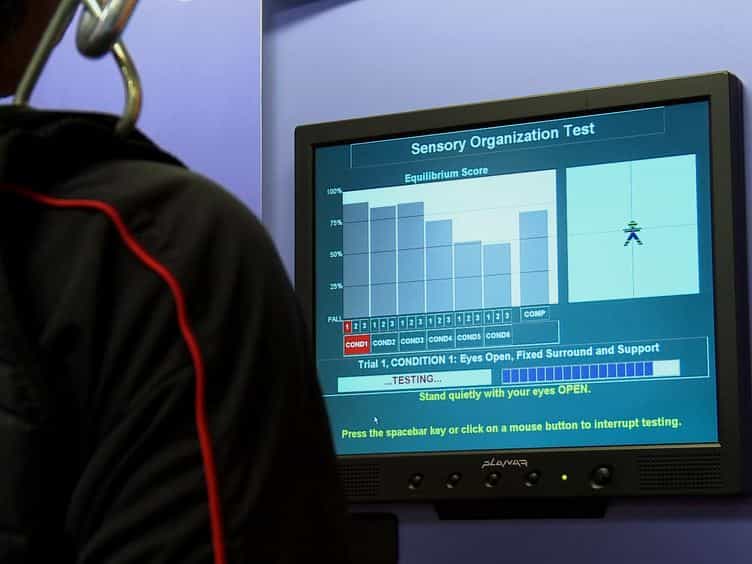
Computerized Dynamic Posturography for Postural Control Assessment in Patients with Intermittent Claudication
Published on: December 11, 2013
Stage-specific alignment between operational loss and rear-end conflict exposure during traffic oscillations
Yunhao Zhou1, Yanni Huang1, Yiik Diew Wong1
1School of Civil and Environmental Engineering, Nanyang Technological University, Singapore.

Objective:
Stop-and-go oscillations degrade traffic efficiency and elevate rear-end crash risk, yet these two consequences are usually evaluated separately. This study examined the extent to which operational loss and rear-end conflict exposure are aligned within the same traffic oscillation episodes and identified the stage-specific behavioral and kinematic factors associated with their correspondence or divergence.
Methods:
Operational loss and conflict exposure were quantified using two conceptually parallel time-integrated indicators: Time-Integrated Speed Difference (TISD) and Time-Integrated Time-to-Collision (TIT), respectively. Each oscillation cycle was segmented into pre-deceleration, deceleration, low-speed cruising, and acceleration stages using Wavelet Transform-based transition point detection. Stage-specific behavioral features were estimated with the Asymmetric Behavior (AB) model and summarized as stage-level averages and within-stage adjustment trends. The operational-safety alignment was examined at whole-cycle and stage-specific levels through absolute and platoon-centered comparisons. Feature-block extreme gradient boosting (XGBoost) models and SHapley Additive exPlanations (SHAP) were used to assess the relative contributions of behavioral and kinematic information.
Results:
Trajectories of 654 vehicles in 27 oscillation platoons from the CitySim-Freeway B dataset showed a positive but moderate association between TISD and TIT. Whole-cycle correlations were 0.360 for absolute outcomes and 0.335 for platoon-centered outcomes (both p < 0.001). Their stage compositions differed: 72.7% of mean TISD accumulated during low-speed cruising and acceleration, whereas TIT was concentrated in deceleration and low-speed cruising, with deceleration alone accounting for 47.1%. Within-platoon TISD deviations were predominantly explained by behavioral features, while TIT deviations reflected both behavioral and kinematic information. SHAP analysis showed that TISD was mainly associated with pre-deceleration and acceleration-stage behavior, whereas TIT was more strongly linked to behavior and motion states during deceleration, low-speed cruising, and acceleration. Cautious recovery during acceleration was associated with higher operational loss but lower conflict exposure, indicating a potential operational-safety trade-off.
Conclusions:
Operational loss and rear-end conflict exposure are related but not interchangeable. Their association varies across oscillation stages and reflects different behavioral and kinematic patterns. The proposed stage-specific framework supports joint evaluation of traffic efficiency and safety and may inform longitudinal control strategies that balance the two objectives.
Related Concept Videos
 01:16
Eccentric Loading
 01:13
Maximum Deflection
The maximum deflection occurs at a specific point, known as point O, where the tangent to the deflection curve is horizontal. To find point O, the slope of the tangent at any...
 01:16
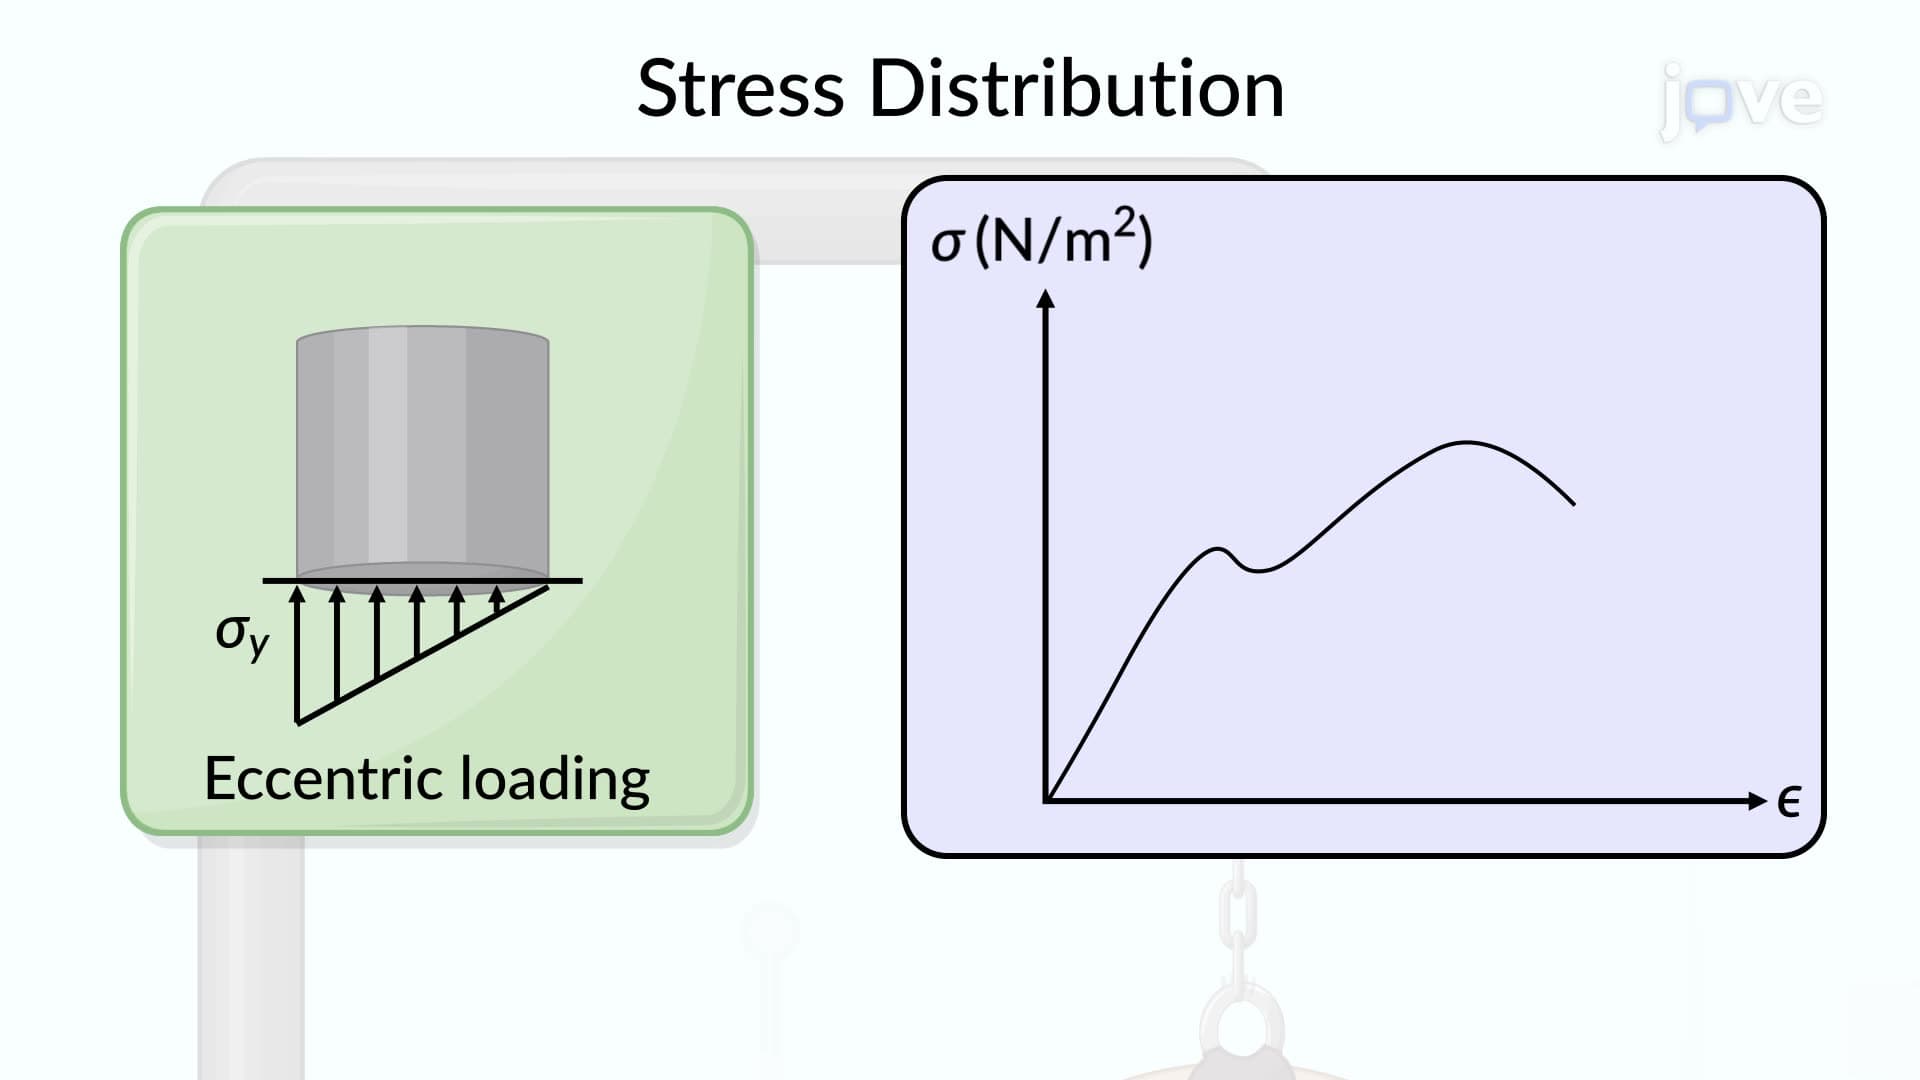
Eccentric Axial Loading in a Plane of Symmetry
 01:17
Beams with Unsymmetric Loadings
The first moment-area theorem determines the slope at any point on the beam. This theorem indicates that the change in slope between two points on a beam...
 01:14
Stability of structures
 01:12
General Case of Eccentric Axial Loading
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical bending,...