Related Experiment Video
Updated: Oct 18, 2026
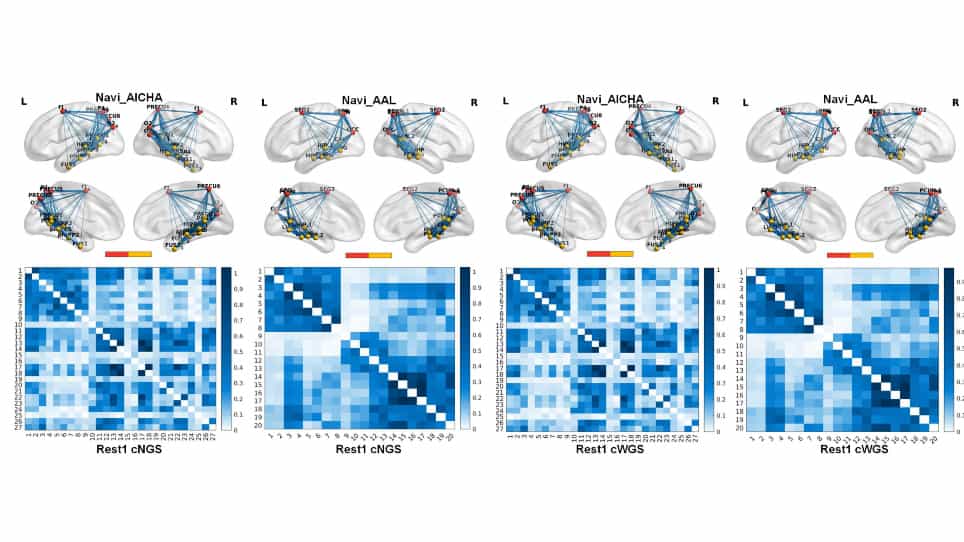
Modeling the Functional Network for Spatial Navigation in the Human Brain
Published on: October 13, 2023
Allocentric navigation is computationally universal
1Department of Philosophy, University of Missouri, Columbia, MO, USA. piccininig@umsystem.edu.

Abstract:
I present three proofs that idealized neurocomputational architectures capable of navigation guided by allocentric maps with landmark structure can be computationally universal. Navigation may occur online, in the environment, or offline, in the animal's head. The first proof encodes the counters of a two-counter machine as positions of movable markers on orthogonal axes. The second directly simulates a one-tape Turing machine using a writable tape-path embedded in the map. The third realizes the tape-path's predecessor/successor relation through local cues at a two-row landmark track rather than through a globally indexed path primitive. I establish universality in two senses: each class of navigation models is Turing-complete, and each contains a single machine that simulates every machine in its class. These constructions are mathematically close to classical graph-based models, including Kolmogorov-Uspensky machines, storage-modification machines, and graph Turing machines, so the bare computability results are unsurprising. My contribution is to reconstruct them explicitly within an allocentric cognitive-map architecture whose representational and computational primitives are drawn from empirical and theoretical work on spatial navigation and cognitive control. This shows that an allocentric navigation-based architecture can be computationally universal and opens the possibility of reconstructing aspects of biological cognition, including symbolic processing, in navigation-based terms.
Related Concept Videos
 01:27
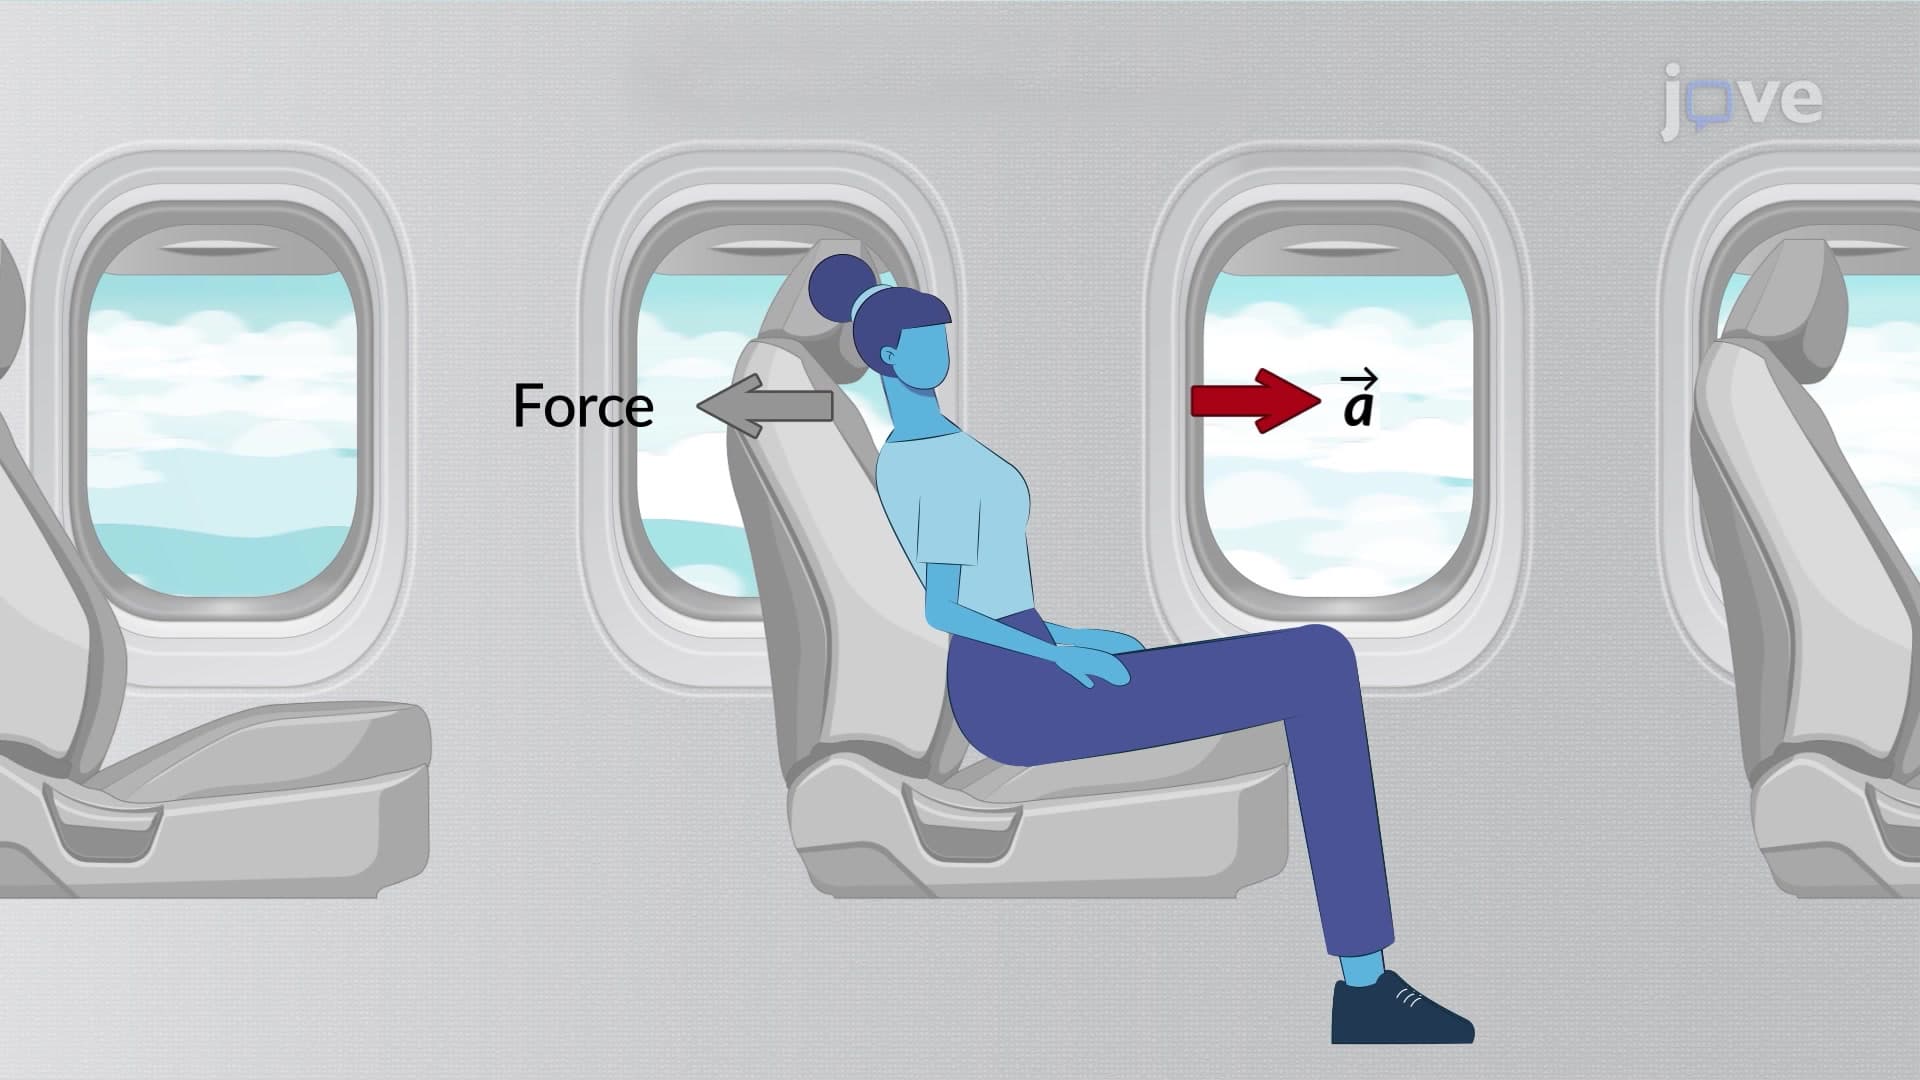
Non-inertial Frames of Reference
 01:03
Inertial Frames of Reference
 01:30
Introduction to Global Positioning System
 01:29
Coordinates and Map Projections
 01:30
Types of Global Positioning System Surveys
 01:03
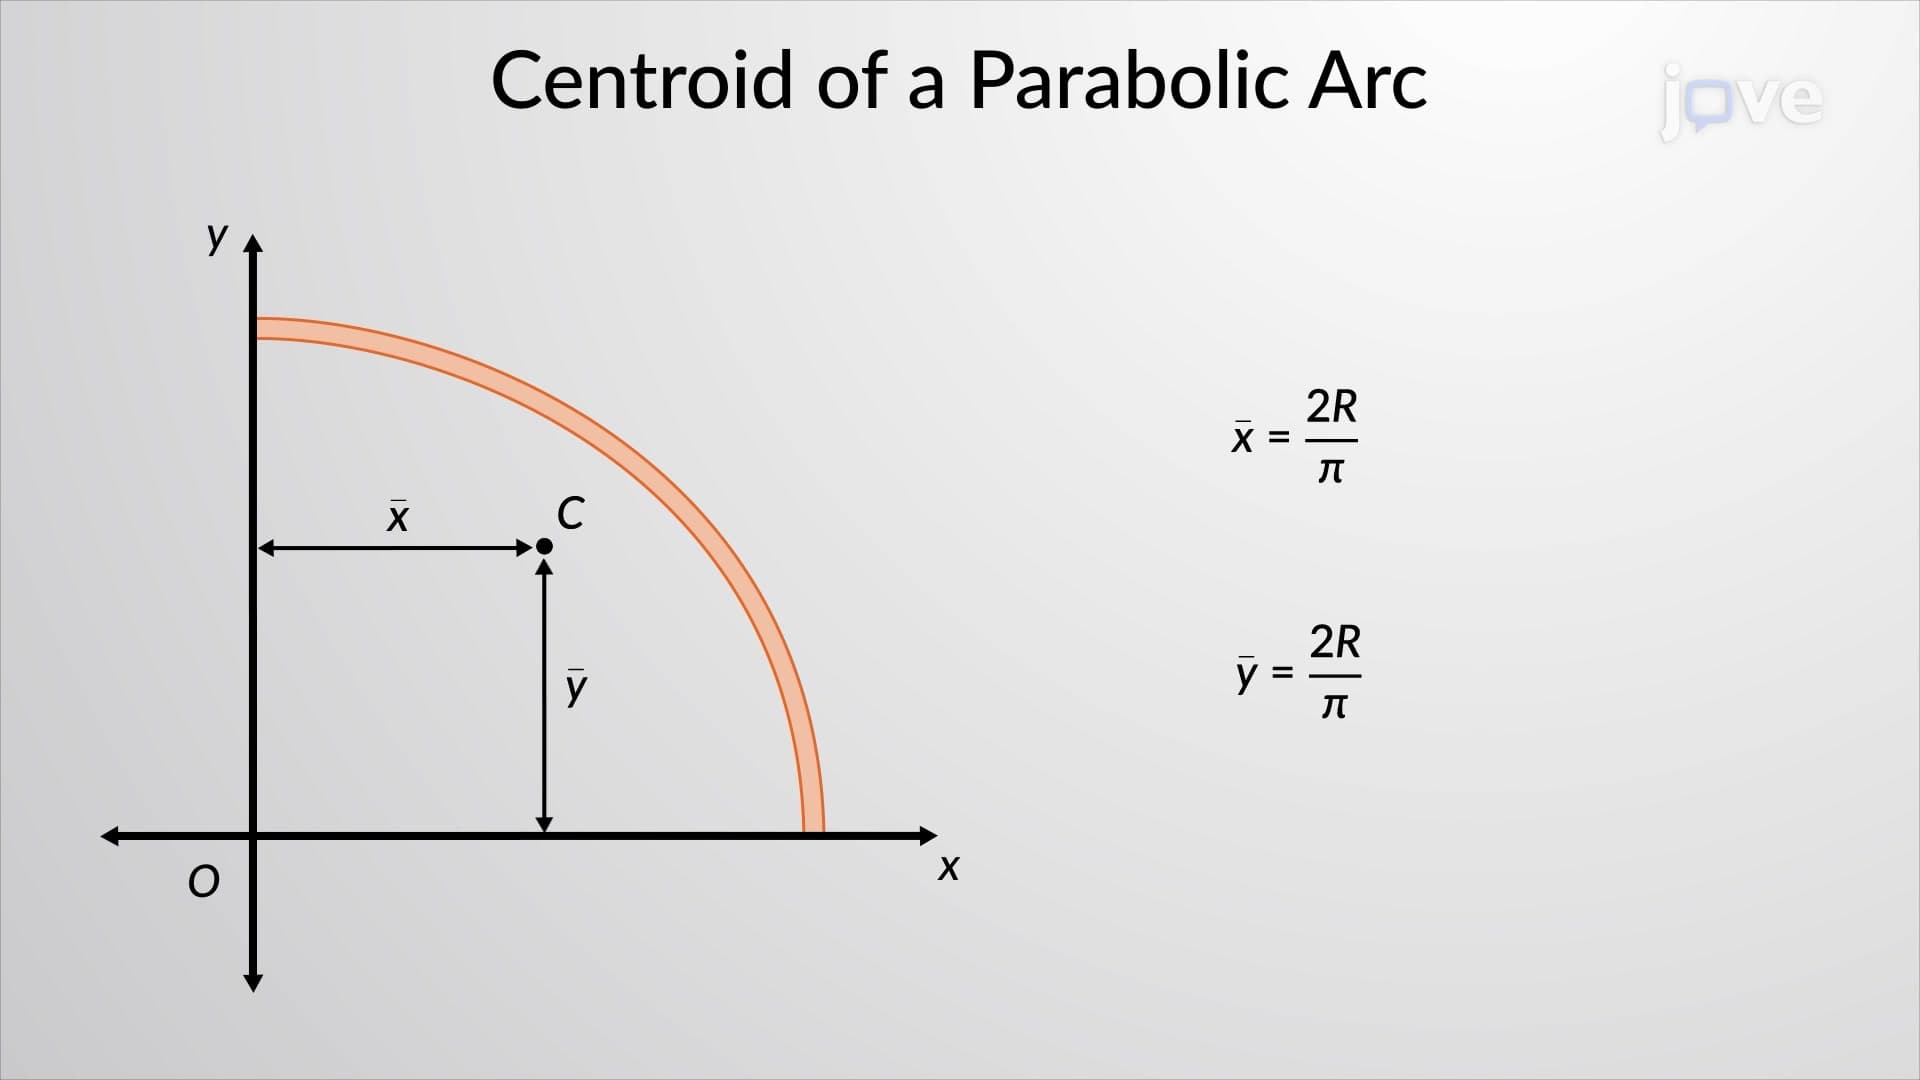
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...