Related Experiment Video
Updated: Oct 18, 2026
Asymmetric Walkway: A Novel Behavioral Assay for Studying Asymmetric Locomotion
Published on: January 15, 2016
Role of asymmetric time delay and its structure in one-dimensional swarmalators
Rommel Tchinda Djeudjo1, Gourab Kumar Sar2, Timoteo Carletti1
1Namur Institute for Complex Systems, Department of Mathematics and naXys, University of Namur, Rue Grafé 2, B-5000 Namur, Belgium.

Abstract:
Swarmalators are a class of coupled oscillators that simultaneously self-organize in both space and phase, providing a minimal model for systems ranging from biological microswimmers to robotic swarms. Time delay is ubiquitous in such systems, arising from finite signal propagation speeds and sensory processing lags; however, its structural form, whether symmetric or asymmetric, has received little attention. Here, we study a one-dimensional swarmalator model with asymmetric time delay, in which the delay enters only the self-interaction terms of the spatial and phase dynamics, breaking the symmetry assumed in prior work. Using initial conditions drawn uniformly from [-π,π] for both the position and phase variables, we identify various collective states, such as async, static phase wave, static π, and active π, and derive analytical stability boundaries for each state as functions of the coupling parameters and the delay. Our analysis reveals that the asymmetric delay structure fundamentally reshapes the collective phase diagram: in particular, for the asymmetric delay models, increasing the delay systematically expands the active π state at the expense of other ordered states. This contrasts with the symmetric delay model, which more strongly promotes unsteady states that are generally not well ordered. By providing closed-form stability conditions validated against numerical simulations, our work establishes that the internal structure of the delay, and not merely its magnitude, is a decisive factor in determining the emergent collective behavior of swarmalator populations.
Related Concept Videos
 01:32
Cytoskeletal Coordination in Cell Migration
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
 01:21
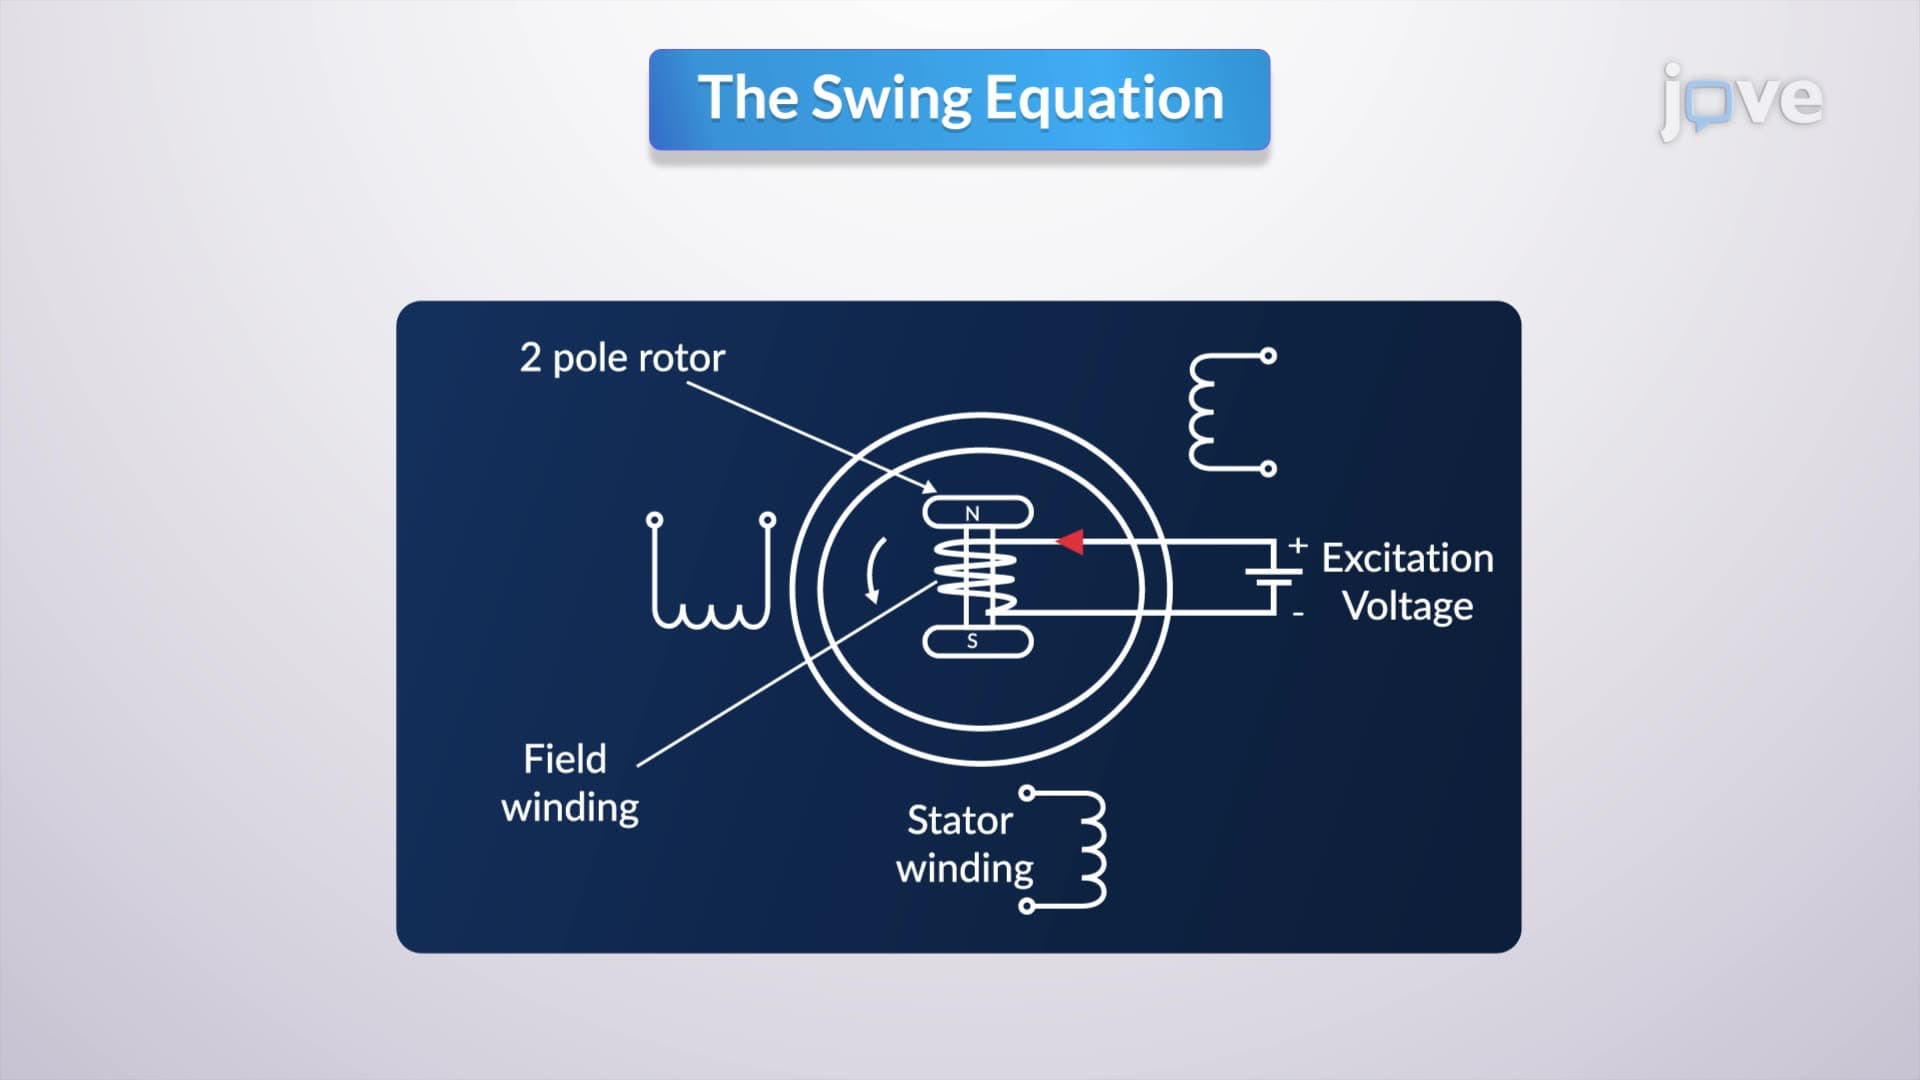
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:22
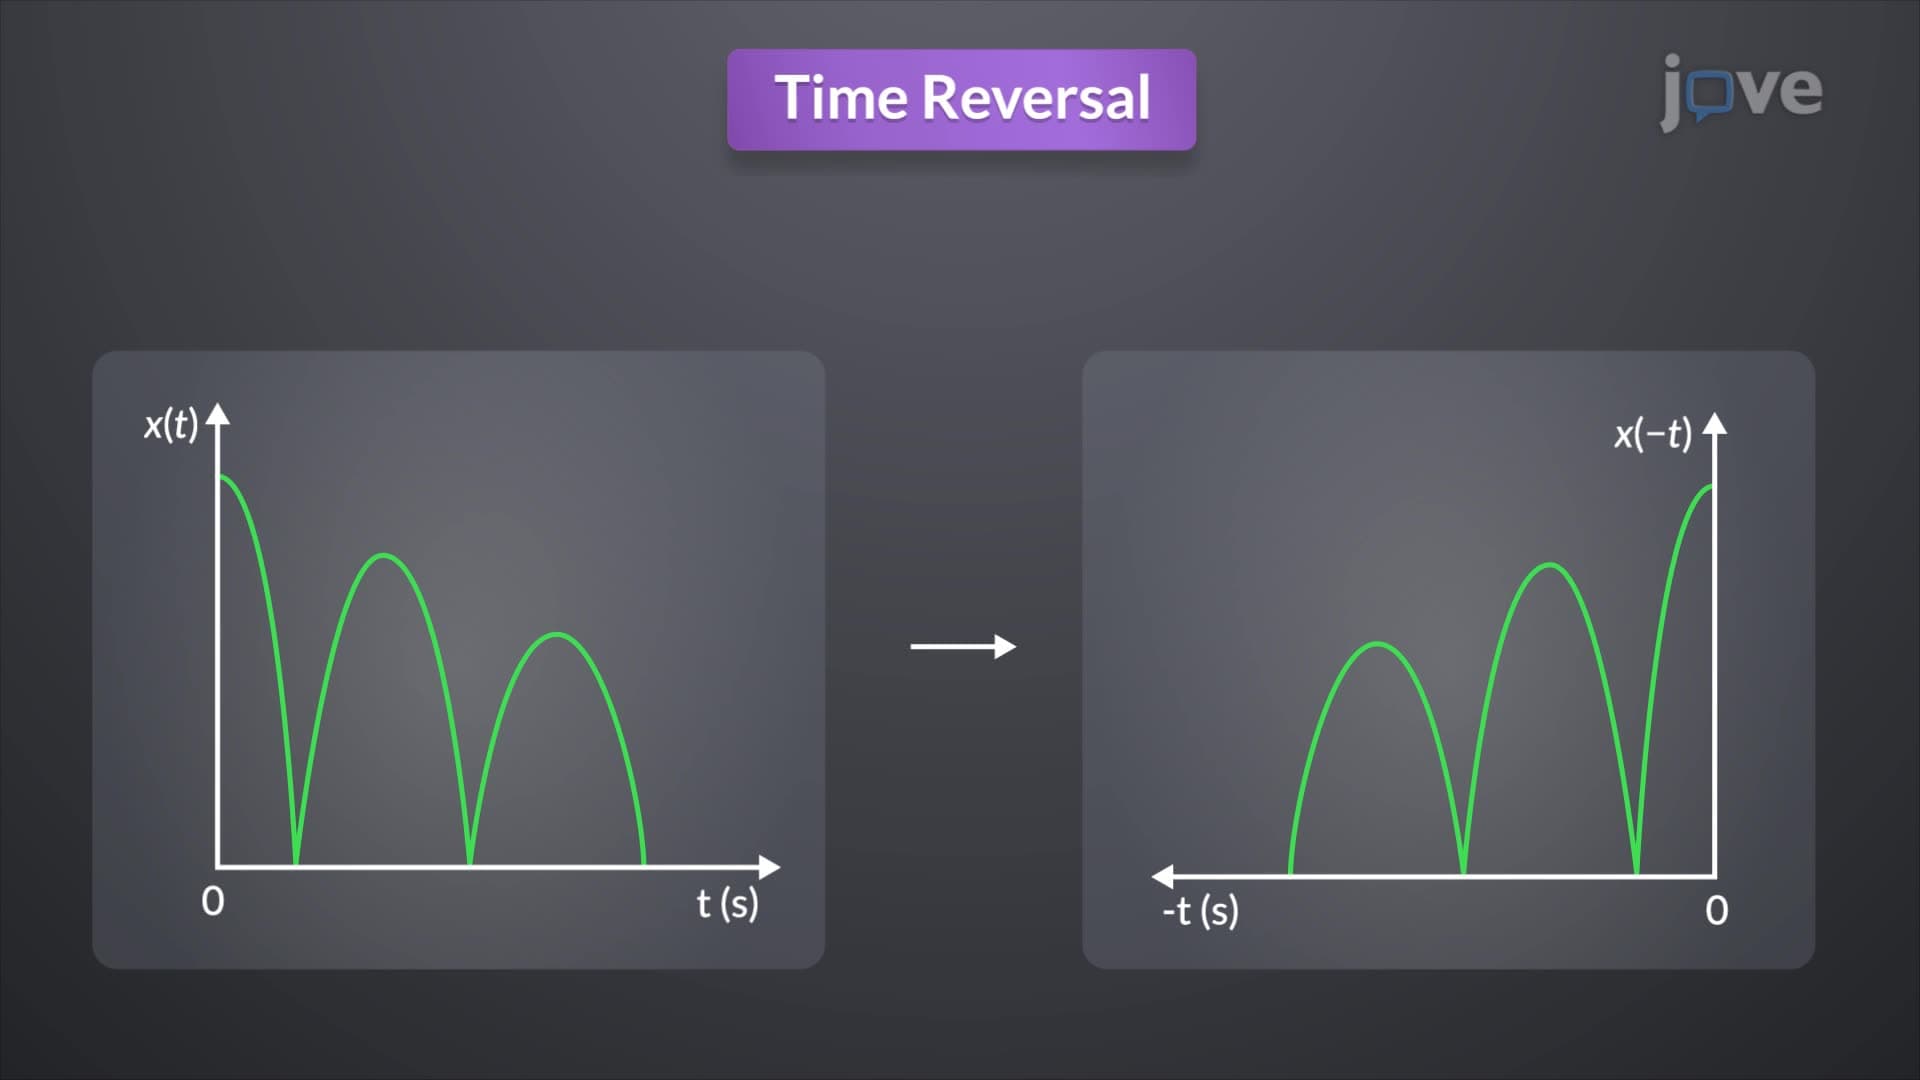
Basic Operations on Signals
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.
 01:27
State Space Representation
Consider an RLC circuit, a...