Related Experiment Video
Updated: Oct 21, 2026

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
A single-loop bilevel deep learning method for optimal control of obstacle problems
Yongcun Song1, Shangzhi Zeng2, Jin Zhang2
1Division of Mathematical Sciences, School of Physical and Mathematical Sciences, Nanyang Technological University, 21 Nanyang Link, 637371, Singapore.

Abstract:
Optimal control of obstacle problems arises in a wide range of applications and is computationally challenging due to the nonsmoothness, nonlinearity, and bilevel structure of the underlying problems. Classical numerical methods typically rely on mesh-based discretizations and require solving a sequence of computationally expensive subproblems, while deep learning approaches for this class of problems remain largely unexplored. In this work, we propose a bilevel deep learning framework whose core training algorithm is the computationally efficient Single-Loop Stochastic First-Order Bilevel Algorithm (S2-FOBA), which avoids nested optimization, uses only first-order information, and does not rely on restrictive lower-level uniqueness assumptions. The proposed method is mesh-free, scalable to high-dimensional settings and complex domains, and avoids the repeated solution of discretized subproblems. It employs constraint-embedding neural networks to approximate both the state and the control, thereby enforcing admissibility by construction while preserving the intrinsic bilevel structure of the problem. We further analyze the convergence behavior of S2-FOBA under mild conditions. Numerical experiments on benchmark problems, including two-dimensional examples with regular and irregular obstacles, a five-dimensional example, and a problem posed on a complex domain, demonstrate the effectiveness, efficiency, and robust constraint enforcement of the proposed approach.
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:16
Hydraulic Jump: Problem Solving
 01:24
Laminar Flow: Problem Solving
 01:16
Statically Indeterminate Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:28
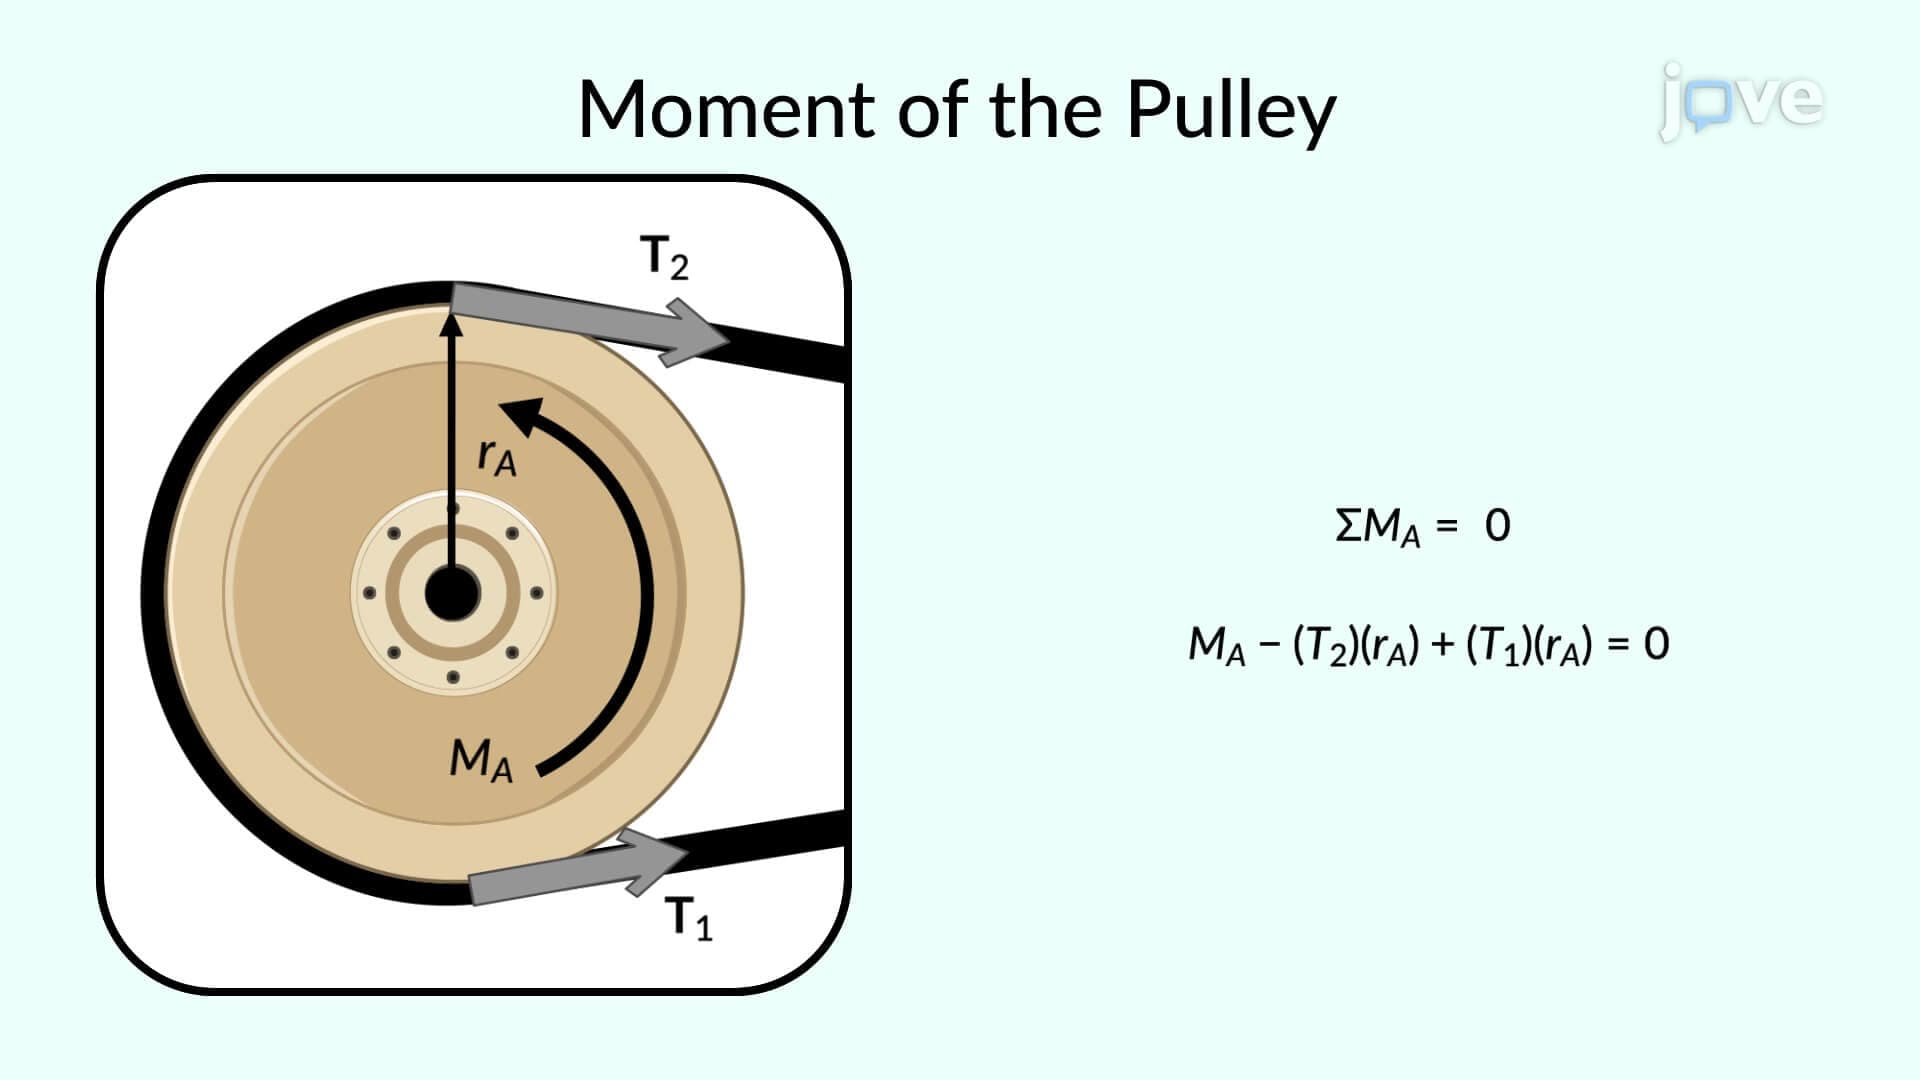
Flat Belts: Problem Solving