Related Experiment Video
Updated: Oct 21, 2026
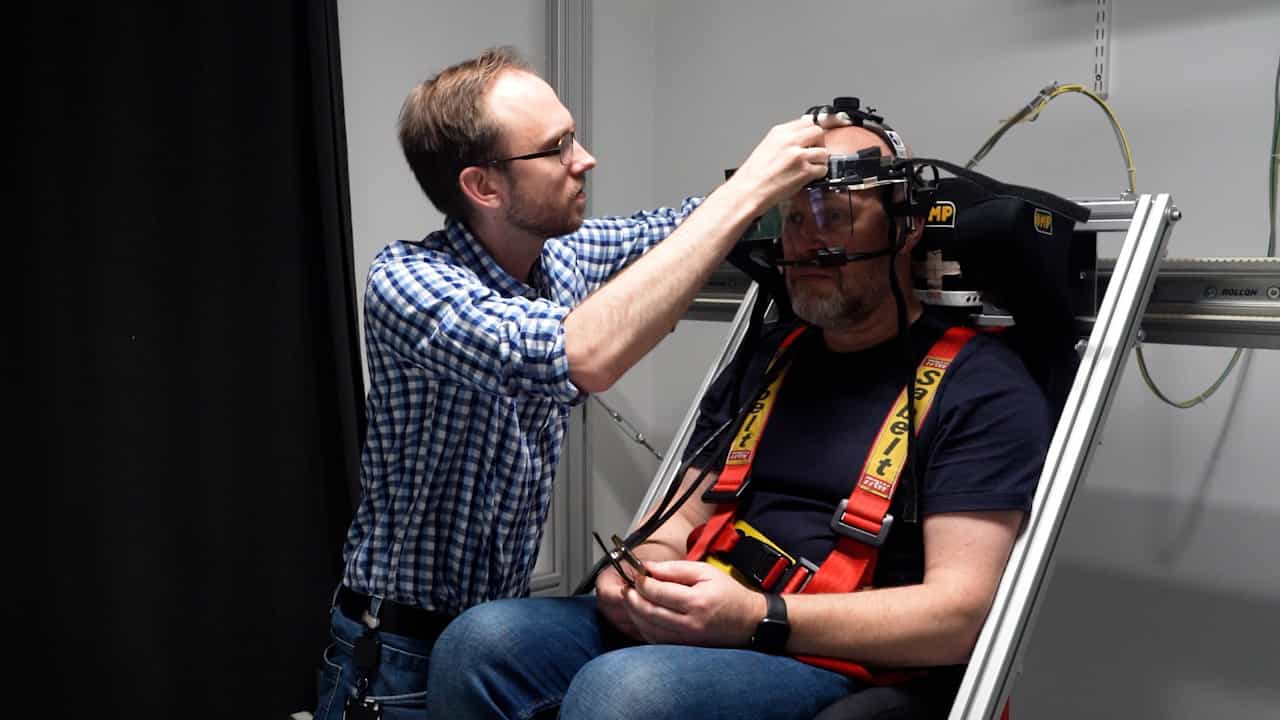
Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Locomotor kinematics and head stabilization in rolling snakes
Yosuke Kojima1, Ibuki Fukuyama2, Mohamad Yazid Hossman3
1Department of Biology, Toho University, 2-2-1 Miyama, Funabashi, Chiba 274-8510, Japan.

Abstract:
Morphology constrains the strategies available to organisms and their functional capacities. A striking example is the absence of wheels and the rarity of rolling locomotion across the animal kingdom1,2. Although rolling can confer high speed, it poses a fundamental mechanical challenge, as body rotation destabilizes the head and disrupts sensory-guided adjustment, particularly at high speeds. Here we report a behavioral solution to this problem: our video analyses show that dwarf reed snakes (Pseudorabdion) stabilize their head during dynamic rotational motion of the posterior body by using precisely coordinated body movements. This acrobatic behavior enables fast and controlled rolling locomotion that would otherwise be impossible, illustrating how behavioral innovation can circumvent deep morphological constraints and expand the capacities of animals.

Related Concept Videos
 01:05
Development of Head Control During Infancy
 01:14
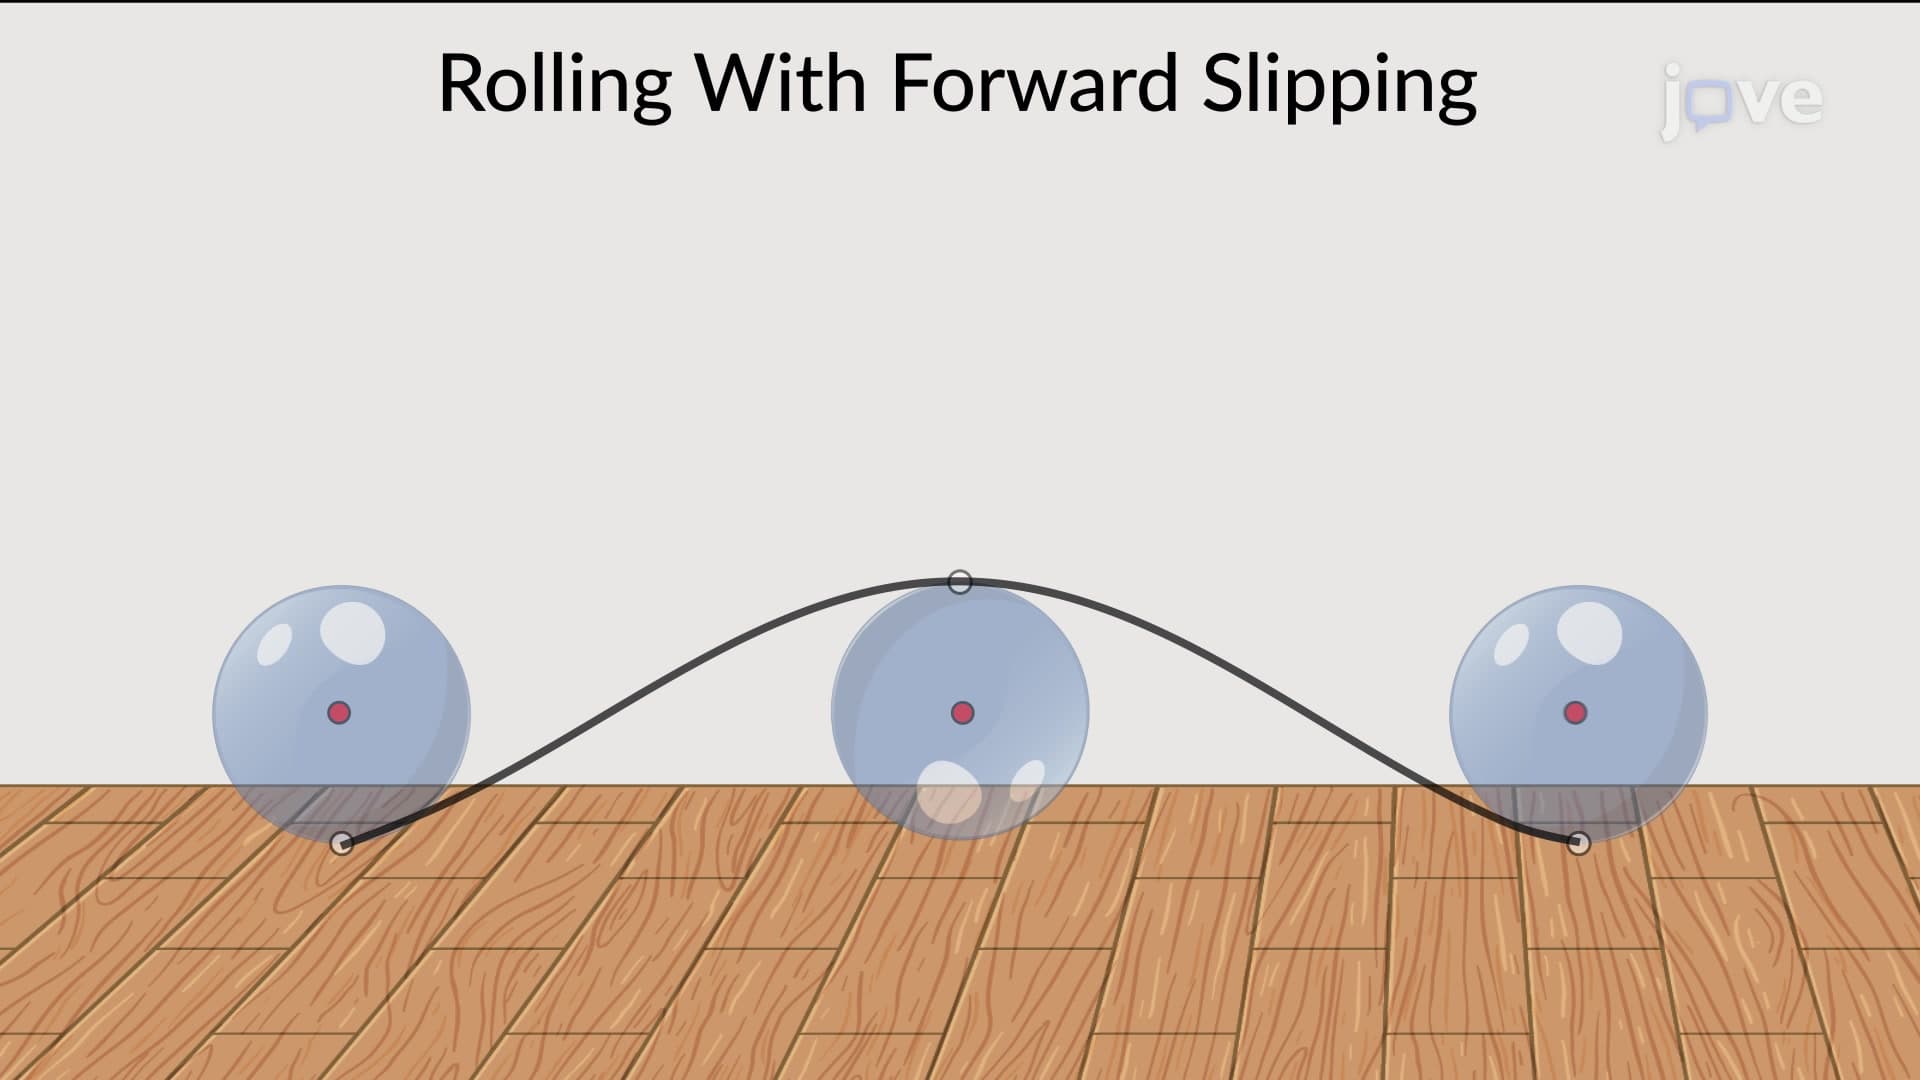
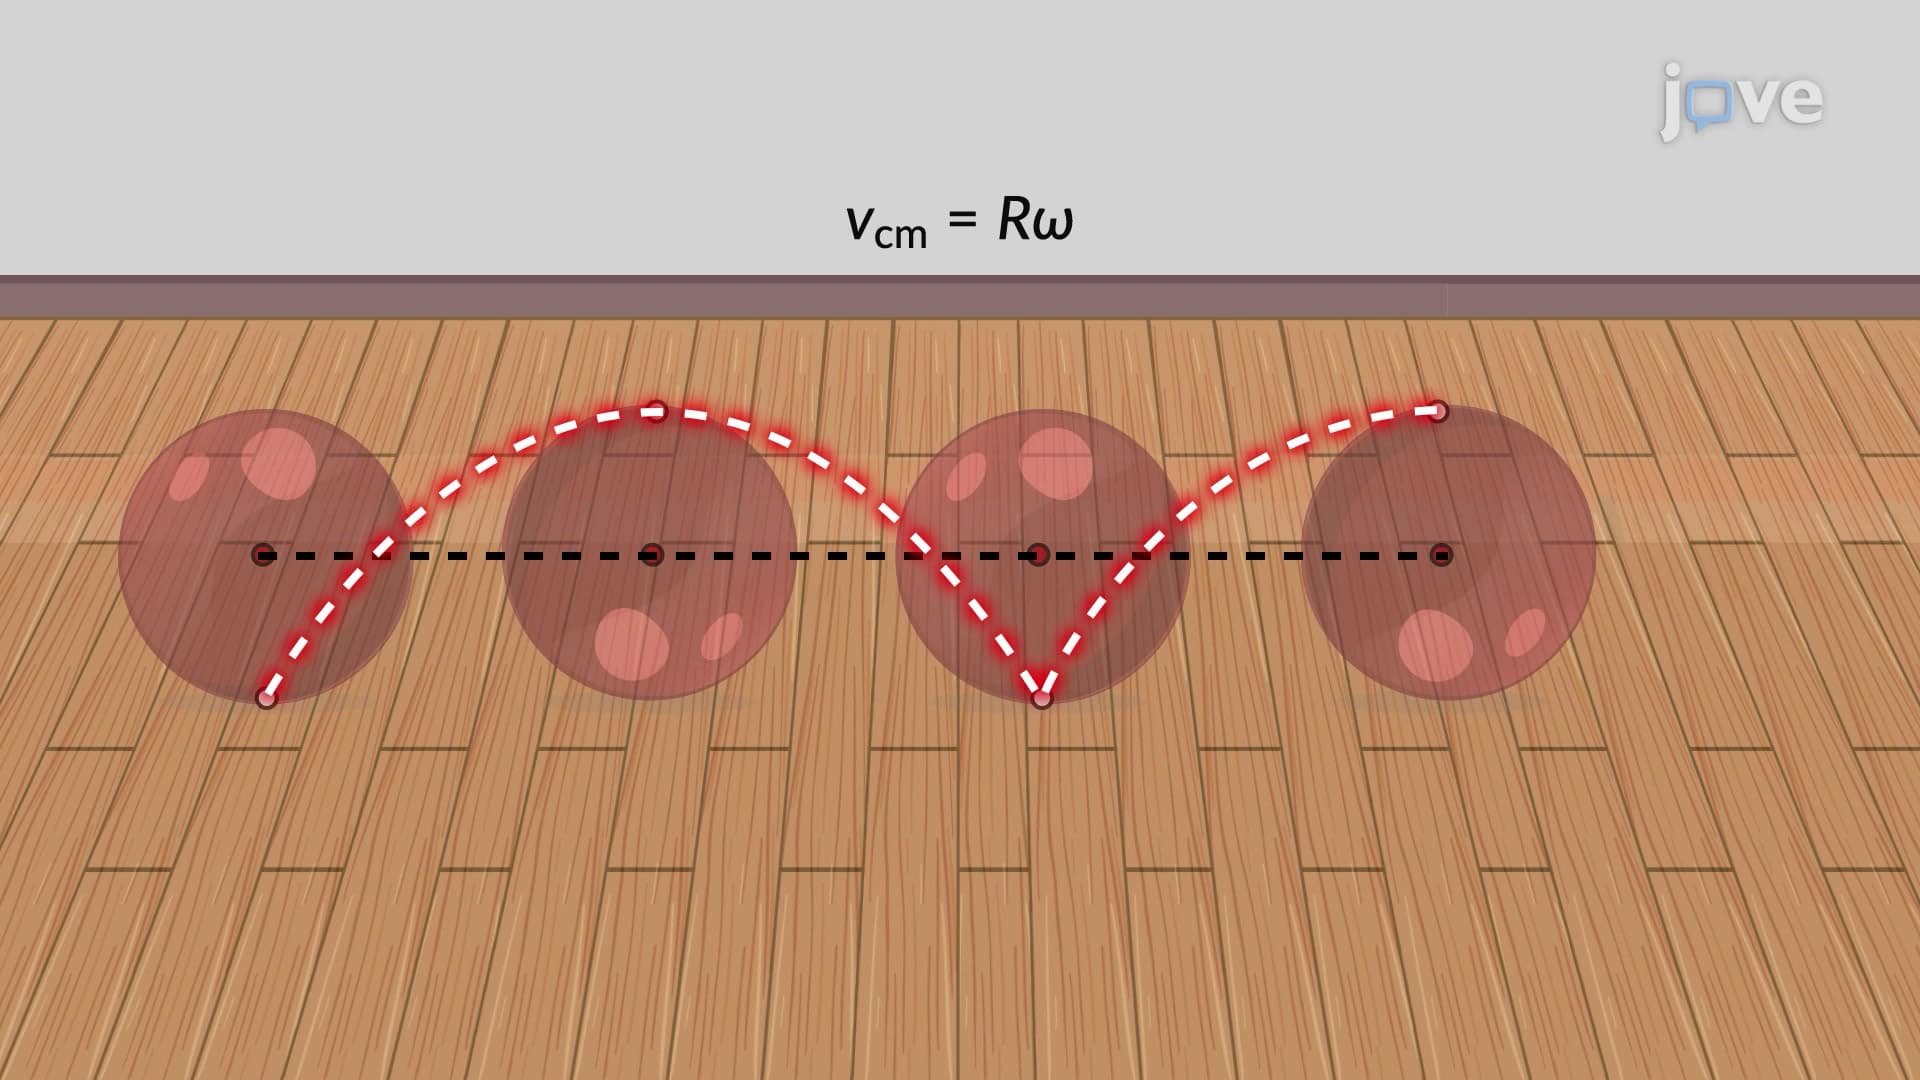
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can affect...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:09
Rolling Without Slipping
 00:49
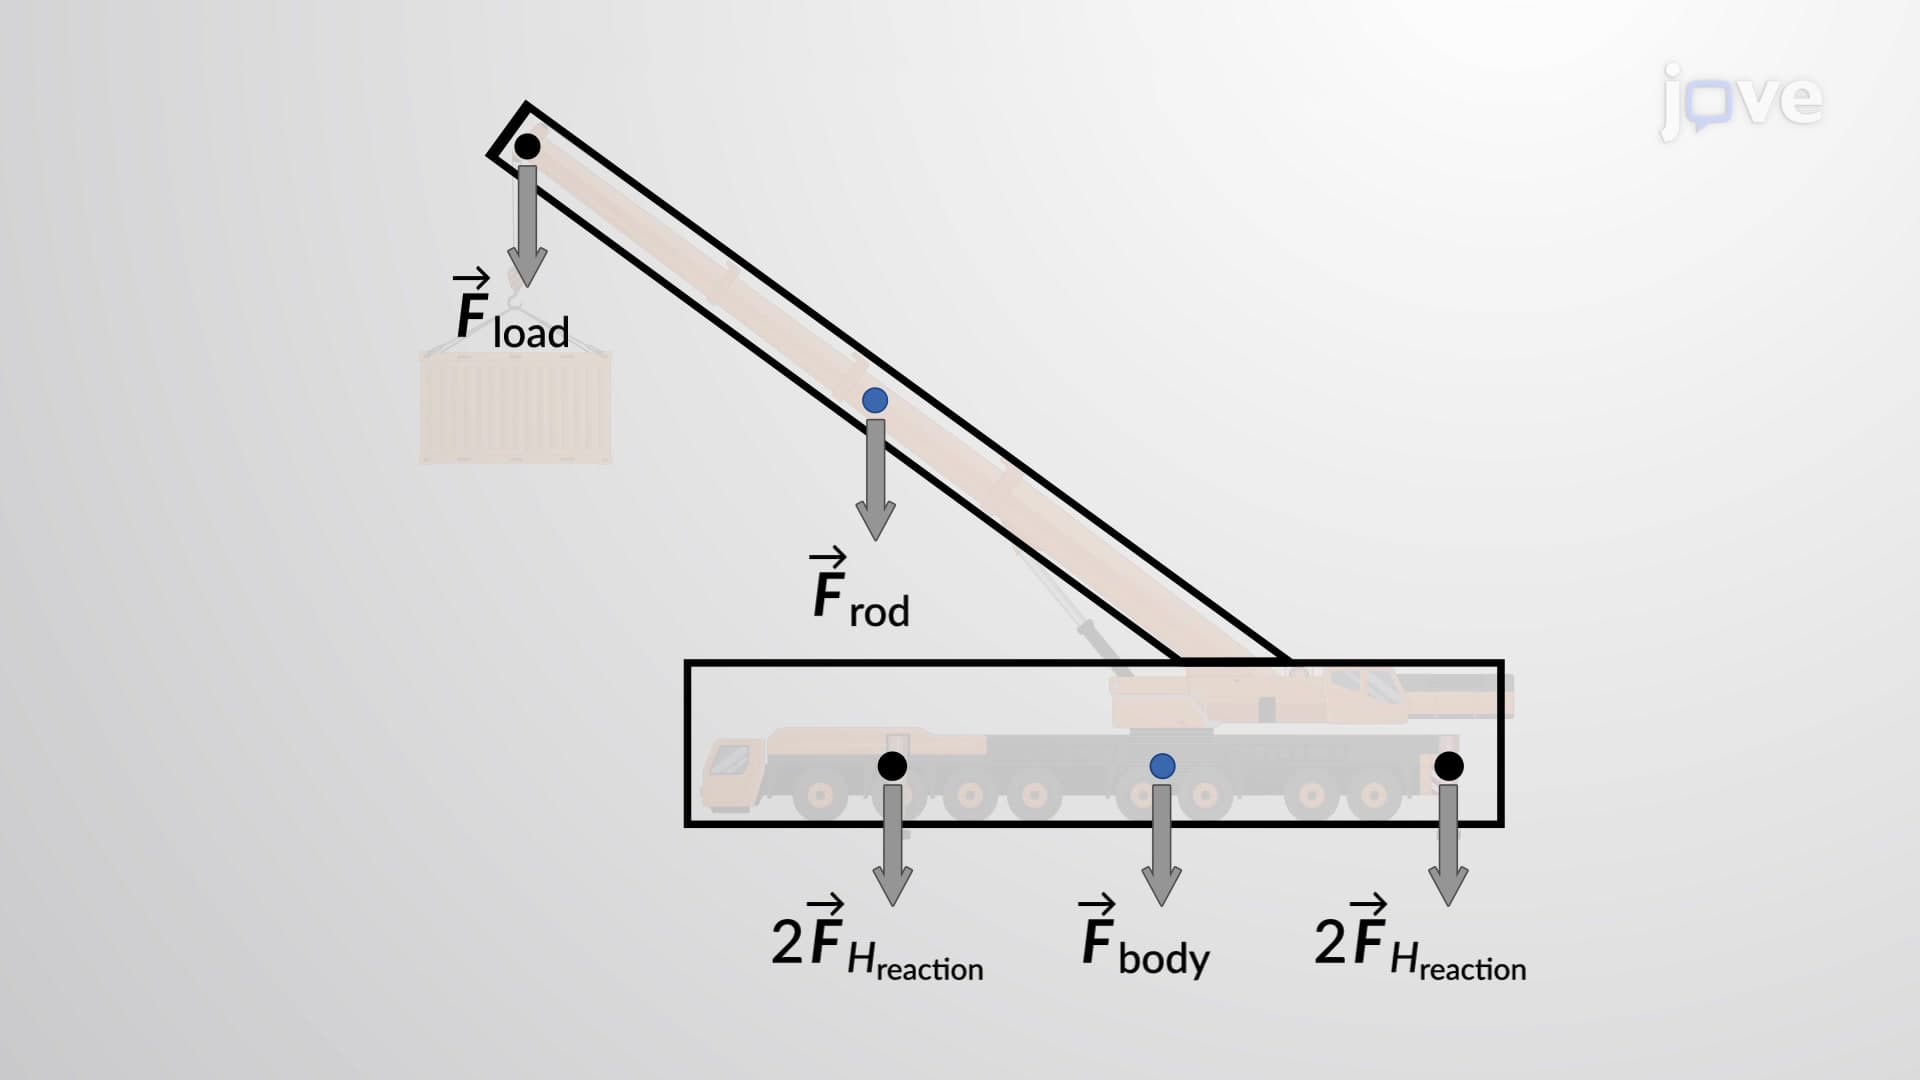
Rigid Body Equilibrium Problems - I