Related Experiment Video
Updated: Oct 22, 2026
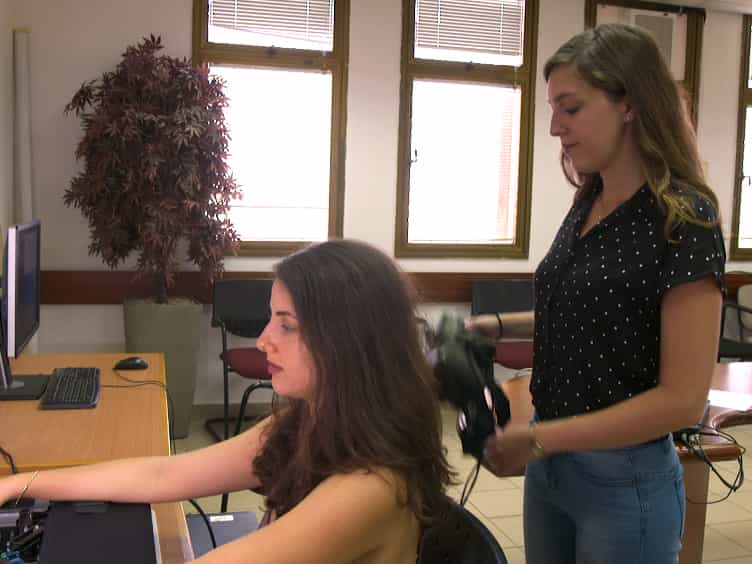
Using Virtual Reality to Transfer Motor Skill Knowledge from One Hand to Another
Published on: September 18, 2017
The Rheology Gap: A Component-Level Benchmark for VR-to-Reality Motor Skill Transfer under Linear Haptic Simulation

Abstract:
Passivity constraints bound the impedance range that force-feedback devices can stably display, so real-time haptic training defaults to linear physics-typically a mass-spring-damper (MSD) model-although materials worth training on are nonlinear and non-Newtonian. We define this discrepancy as the rheology gap and ask which motor-skill components survive a deliberately linearized rendering of an artisanal dough-stretching task. A within-instance design held the task fixed while varying VR factors across five conditions ($N=378$); real-world transfer was assessed in a separate cohort ($n=90$) evaluated on authentic dough by blinded certified judges (AVPN-derived rubric), with published rheometry as the material force reference. Relative to video instruction, VR training produced a medium real-world benefit (Cohen's $d=0.76$): procedural and spatial components transferred, whereas material-specific force modulation did not-thickness uniformity ($-$41.6%) and process efficiency ($-$45.6%), the most rheology-sensitive components, showed the largest deficits. Non-informative force feedback impaired learning, and gains persisted at 24 h. Because conditions covary on several factors, effects are reported as composite. Our central contribution is a reproducible, component-level benchmark-task protocol, objective metrics, characterized linear baseline, and published-rheometry reference-on which any future nonlinear engine (FEM, MPM, XPBD, neural physics) can be scored under identical conditions, rendering simulation fidelity falsifiable. As a first application, a simulation-stage prototype rendering the calibrated strain-stiffening law under time-domain passivity control runs stably at 1 kHz and cuts force-fidelity error from 41.0% to 24.6% NRMSE. Pending closed-loop validation of the strain-stiffening hypothesis (offline $R^{2}=0.31$), current VR is best positioned as pre-apprenticeship scaffolding, not a substitute for physical practice.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
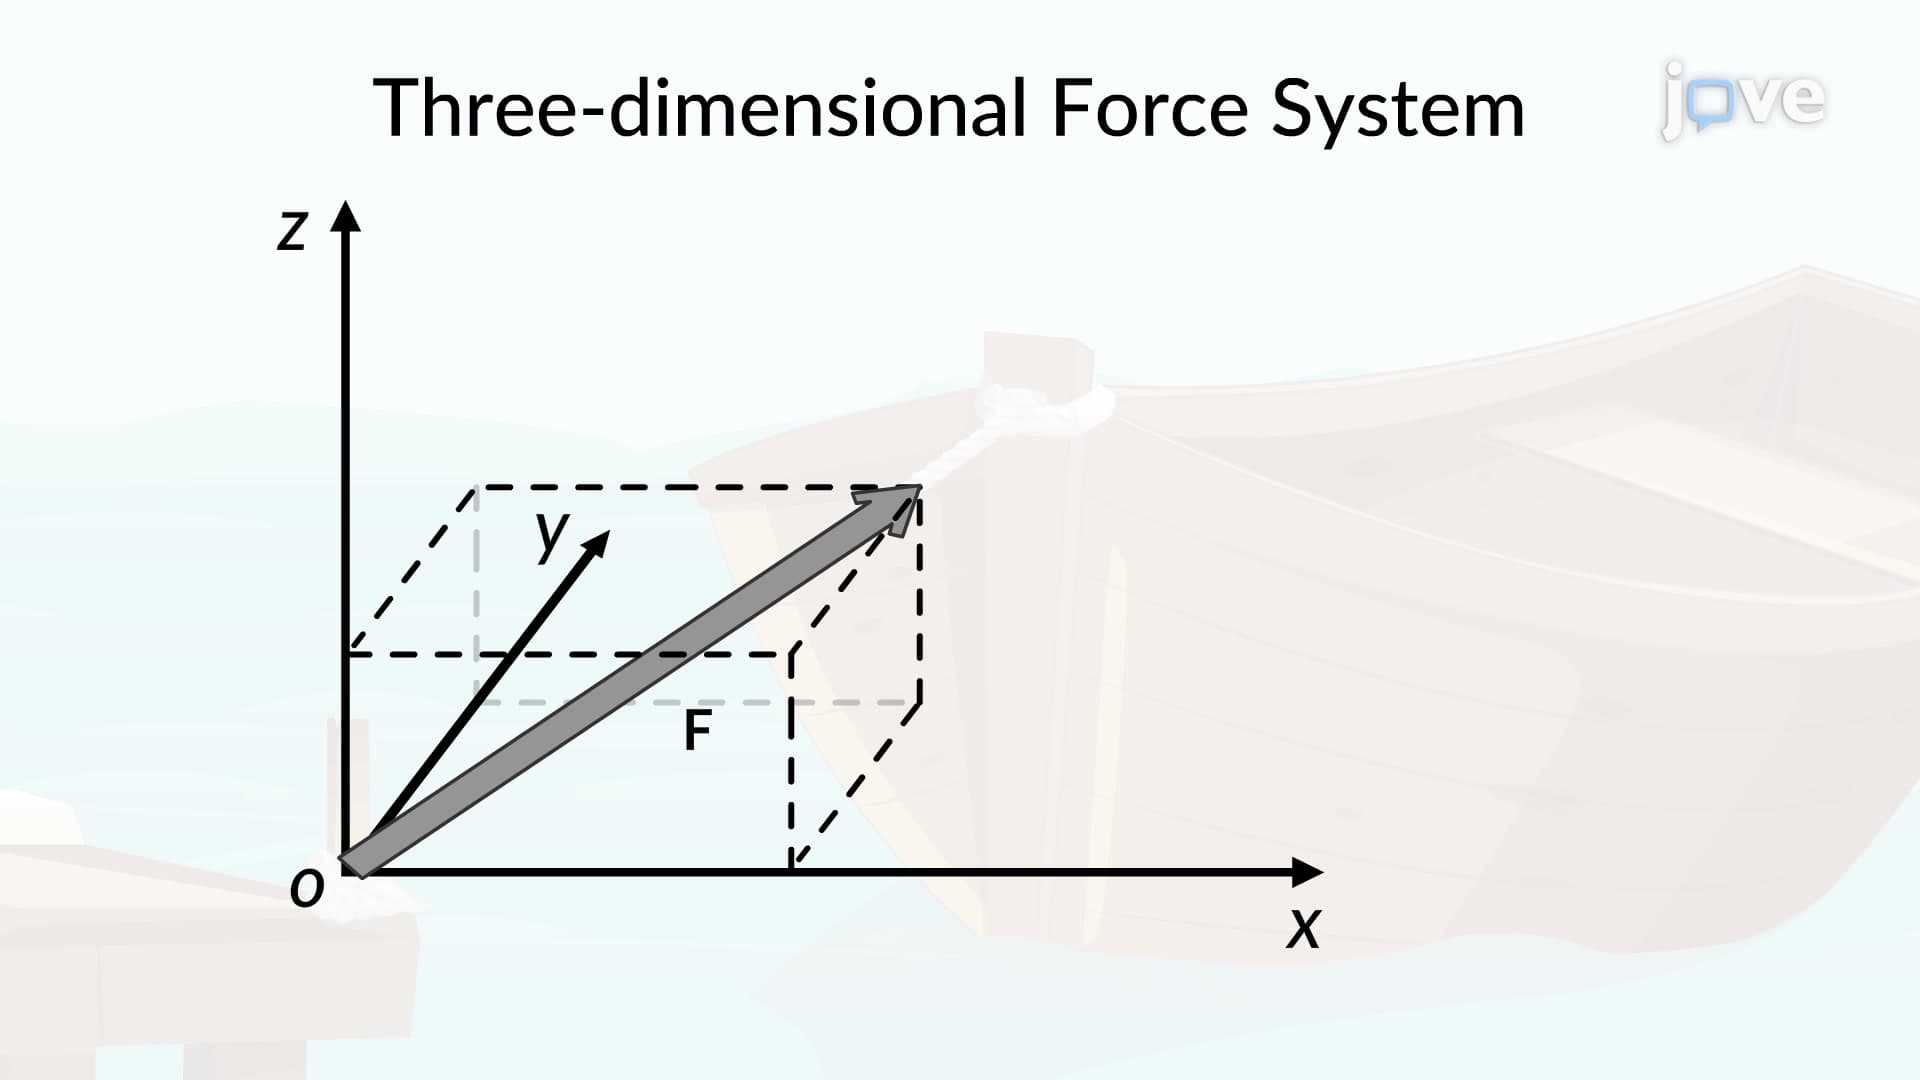
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:19
Viscosity of Fluid
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:15
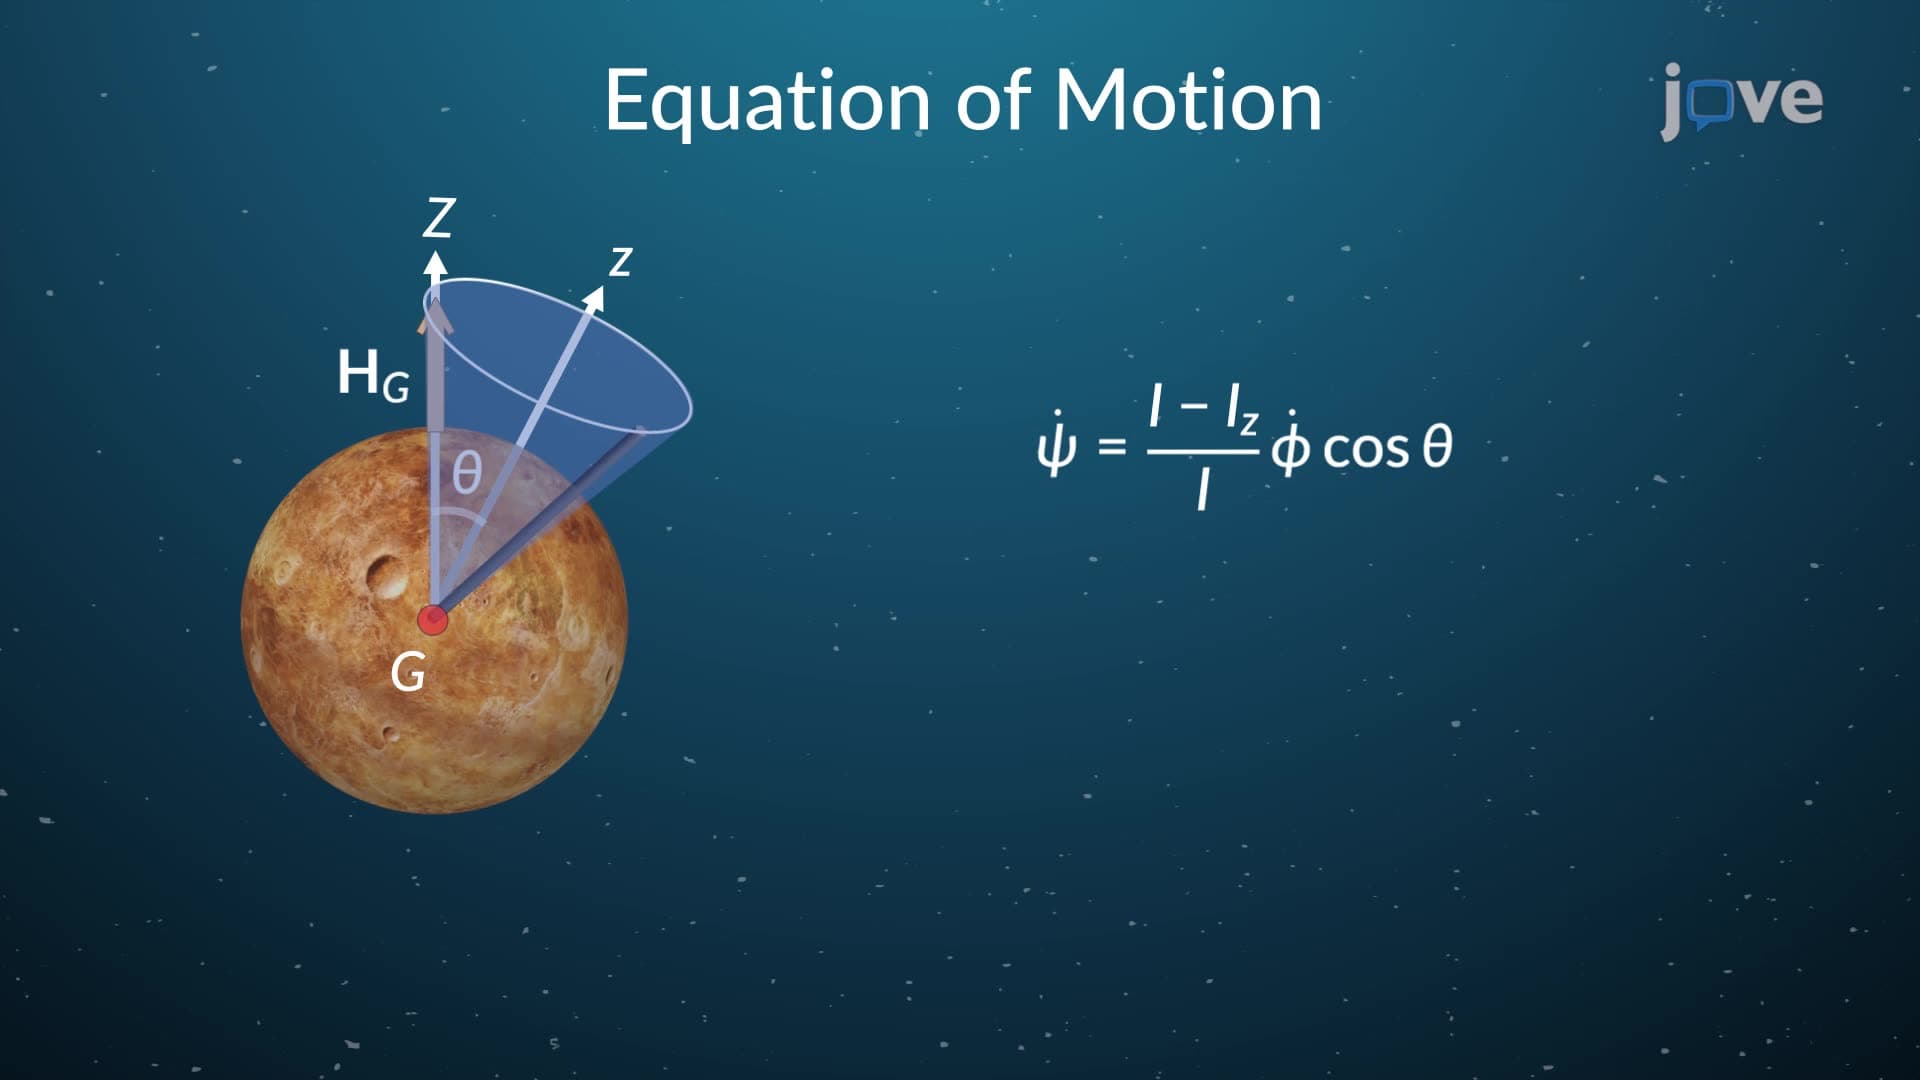
Torque Free Motion