Related Experiment Video
Updated: Oct 25, 2026
An Experimental Protocol for Assessing the Performance of New Ultrasound Probes Based on CMUT Technology in Application to Brain Imaging
Published on: September 24, 2017
CUDA (compute unified device architecture) acceleration and keypoint tracking for aero-engine blade deformation
Zelin Li1,2, Huilin Wu1,2, Chuanzhi Sun1,2
1Center of Ultra-precision Optoelectronic Instrument Engineering, Harbin Institute of Technology, Harbin 150080, China.

Abstract:
This paper presents a compute unified device architecture-accelerated visual method for aero-engine blade deformation measurement, addressing inaccurate checkerboard control-point localization and high digital image correlation latency. The approach employs Devernay-operator-based concentric circle edge extraction for precise binocular camera calibration and a parallel-optimized initial value search for real-time subpixel matching. Experiments using a binocular-stroboscopic system on a rotating blade show a maximum unidirectional displacement error of ≤2 μm. At 6000 rpm, peak deformations along the X, Y, and Z directions are 234, 258, and -193 μm, respectively, with a total maximum deformation of 486 μm.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:30
Acceleration Vectors
 01:17
Accelerating Fluids
The motion of the liquid within this infinitesimal cylinder is considered to obtain the pressure difference. Three vertical forces act on this liquid:
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:30
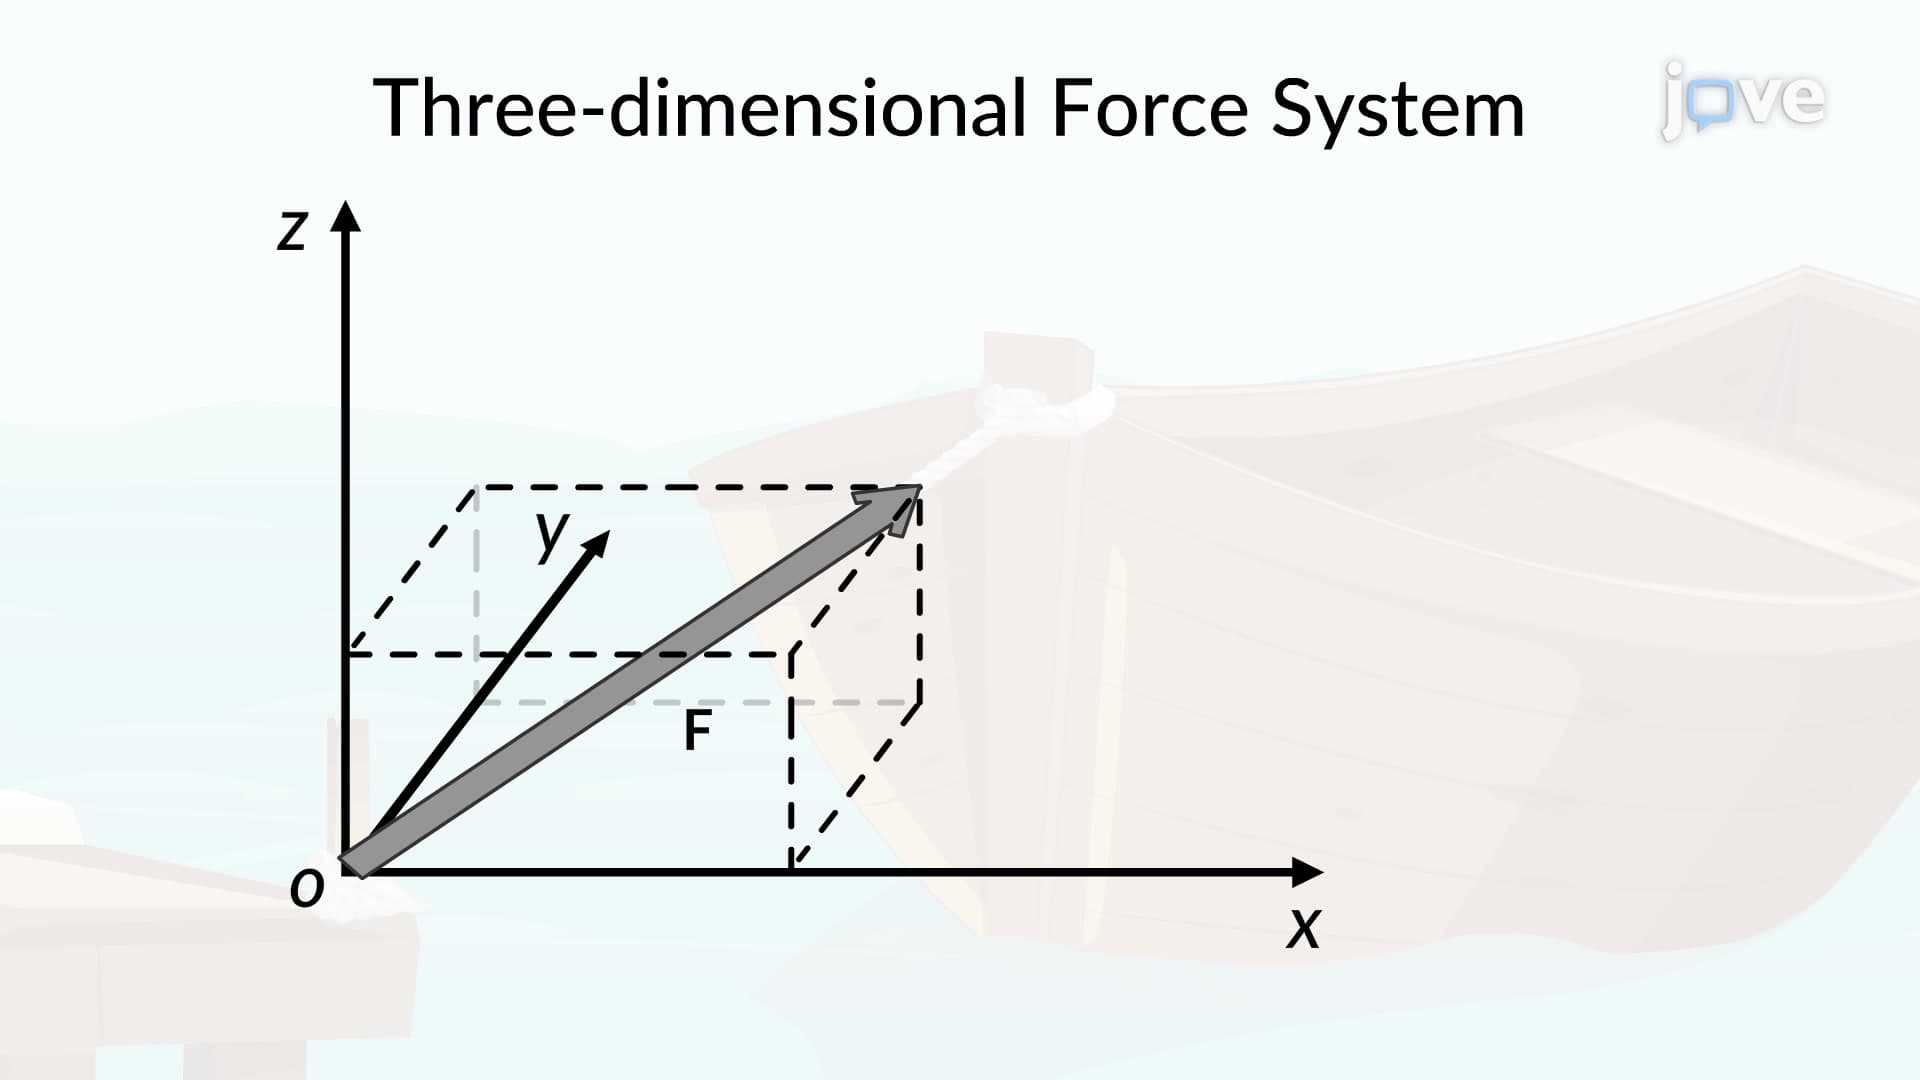
Three-Dimensional Force System