Related Experiment Video
Updated: Oct 27, 2026
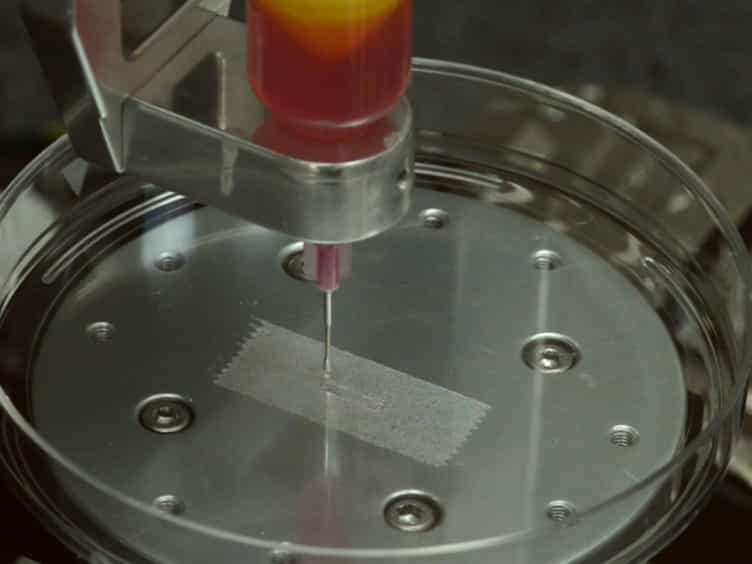
Viability of Bioprinted Cellular Constructs Using a Three Dispenser Cartesian Printer
Published on: September 22, 2015
Bioprinting-Enabled Customization of Biohybrid Actuators: Scaling Dimensions and Functional Complexity
Maede Pajouhande1, Nehar Celikkin1, Saeed Rafieyan1
1Institute of Physical Chemistry, Polish Academy of Sciences, Kasprzaka 44/52, 01-224 Warsaw, Poland.

Abstract:
Biohybrid actuators integrate living contractile cells with engineered materials, combining biological force generation with the structural and functional control offered by synthetic components. However, translating engineered muscle tissue into reproducible, high-performance biohybrid robots remains limited by tissue organization, matrix degradation, force transmission, and long-term functional stability. This review analyzes how biofabrication parameters and material properties influence tissue maturation and actuator-level performance, with particular emphasis on bioprinting. We compare muscle cell sources; extrusion-based, embedded, and light-assisted fabrication strategies; and scaffold biomaterials using reported structural and functional outcomes. We also evaluate electrical and optical activation and mechanical conditioning, distinguishing their roles in controlling contraction and promoting maturation. The comparison highlights a gap between architectural control during fabrication and reproducible robotic performance: methods that produce complex muscle constructs do not necessarily yield integrated devices with validated force transmission or locomotion. Tissue maturation, tissue-material interfaces, and nutrient transport emerge as closely coupled priorities for scaling functional constructs. We conclude with a framework for standardized benchmarking and discuss multimaterial printing, data-driven design, and feedback control as complementary routes toward more reproducible and capable biohybrid actuators.