Related Experiment Video
Updated: Oct 28, 2026
An Experiment Using Functional Near-Infrared Spectroscopy and Robot-Assisted Multi-Joint Pointing Movements of the Lower Limb
Published on: June 7, 2024
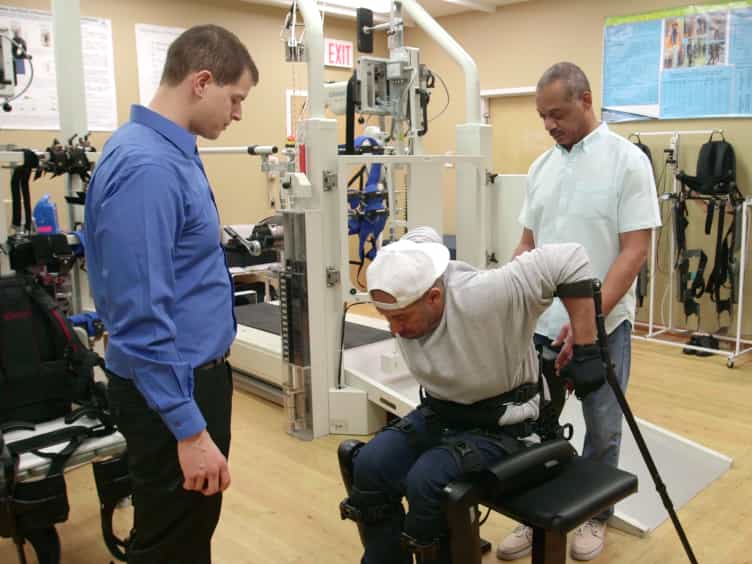
Sit-to-Stand Assistance for Patients with Parkinson's Disease Using a Lower-Limb Exoskeleton Robot
Yu-Cheng Wu1, Lo-Ping Yu2, Si-Huei Lee2
1Department of Mechatronic Engineering, National Taiwan Normal University, 162, Section 1, He-Ping East Road, Taipei 106, Taiwan.

Abstract:
Sit-to-stand (STS) transfer is fundamental to many activities of daily living, but it is difficult for individuals with motor dysfunction or impairment. This study presents an observer-based impedance-control framework for a lower-limb exoskeleton robot to assist STS transfer. To account for external disturbances, including the wearer's joint torques and model uncertainties, a nonlinear disturbance observer (NDO) is used to estimate the lumped disturbance. An impedance-control strategy based on adaptive fuzzy sliding mode control (AFSMC) is then used to regulate the human exoskeleton system by compensating for these unknown terms. STS trials were conducted in one healthy participant and three participants with Parkinson's disease (PD), with and without exoskeleton assistance, to evaluate the proposed system. Across ten trials in the healthy participant, O-AFSMC had the lowest mean hip/knee RMSE (2.1247°/2.9375°). In PD participants, assistance reduced CoP and CoM excursion at the 3-s STS condition in each individual; in the H-Y stage-2 participant, CoP excursion decreased from 25.39 to 15.18 cm and CoM excursion from 17.83 to 14.21 cm. These pilot findings support the feasibility of STS assistance with a lower-limb exoskeleton robot.