Robust Augmented-Diffusion Filtered-x Maximum Correntropy Criterion for Distributed Active Noise Control Under Impulsive Noise
Related Experiment Videos
Dongming Peng1, Yigang He1,2, Qianqian Liu3
1School of Electrical Engineering and Automation, Hefei University of Technology, Hefei 230009, China.

Abstract:
Distributed multichannel active noise control (ANC) is scalable, but filtered-x least-mean-square updates are highly sensitive to impulsive disturbances. This paper proposes a robust augmented-diffusion filtered-x maximum correntropy criterion algorithm (R-ADFxMCC). It keeps the fixed admissible combination of augmented diffusion and replaces the local squared-error update with a normalized correntropy-gated recursion, whose kernel width follows a median-absolute-deviation estimate of the local residual scale. The resulting influence function is bounded and redescending. Under the stated independence and linearization approximations, the analysis gives a combination-weight-independent mean stability condition and a local steady-state excess mean-square error approximation; a symmetry argument proves zero steady-state mean bias without requiring independence between the gate and the regressors. In 30-realization simulations with one validation protocol for all step sizes, the median steady-state gains over augmented-diffusion FxLMS are 25.79, 21.84, 13.80 and 6.46 dB for single-tone, multitone, narrowband and broadband references under localized Bernoulli-Gaussian impulses. The augmented-diffusion M-estimate algorithm reaches the same steady state within 0.45 dB at the validation-selected step sizes, but on single-tone and narrowband references, R-ADFxMCC remains stable at step sizes at which the M-estimate algorithm diverges. Tests with α-stable noise, reverberation, secondary-path errors and measured per-sample cost are also reported.
Related Concept Videos
 01:25
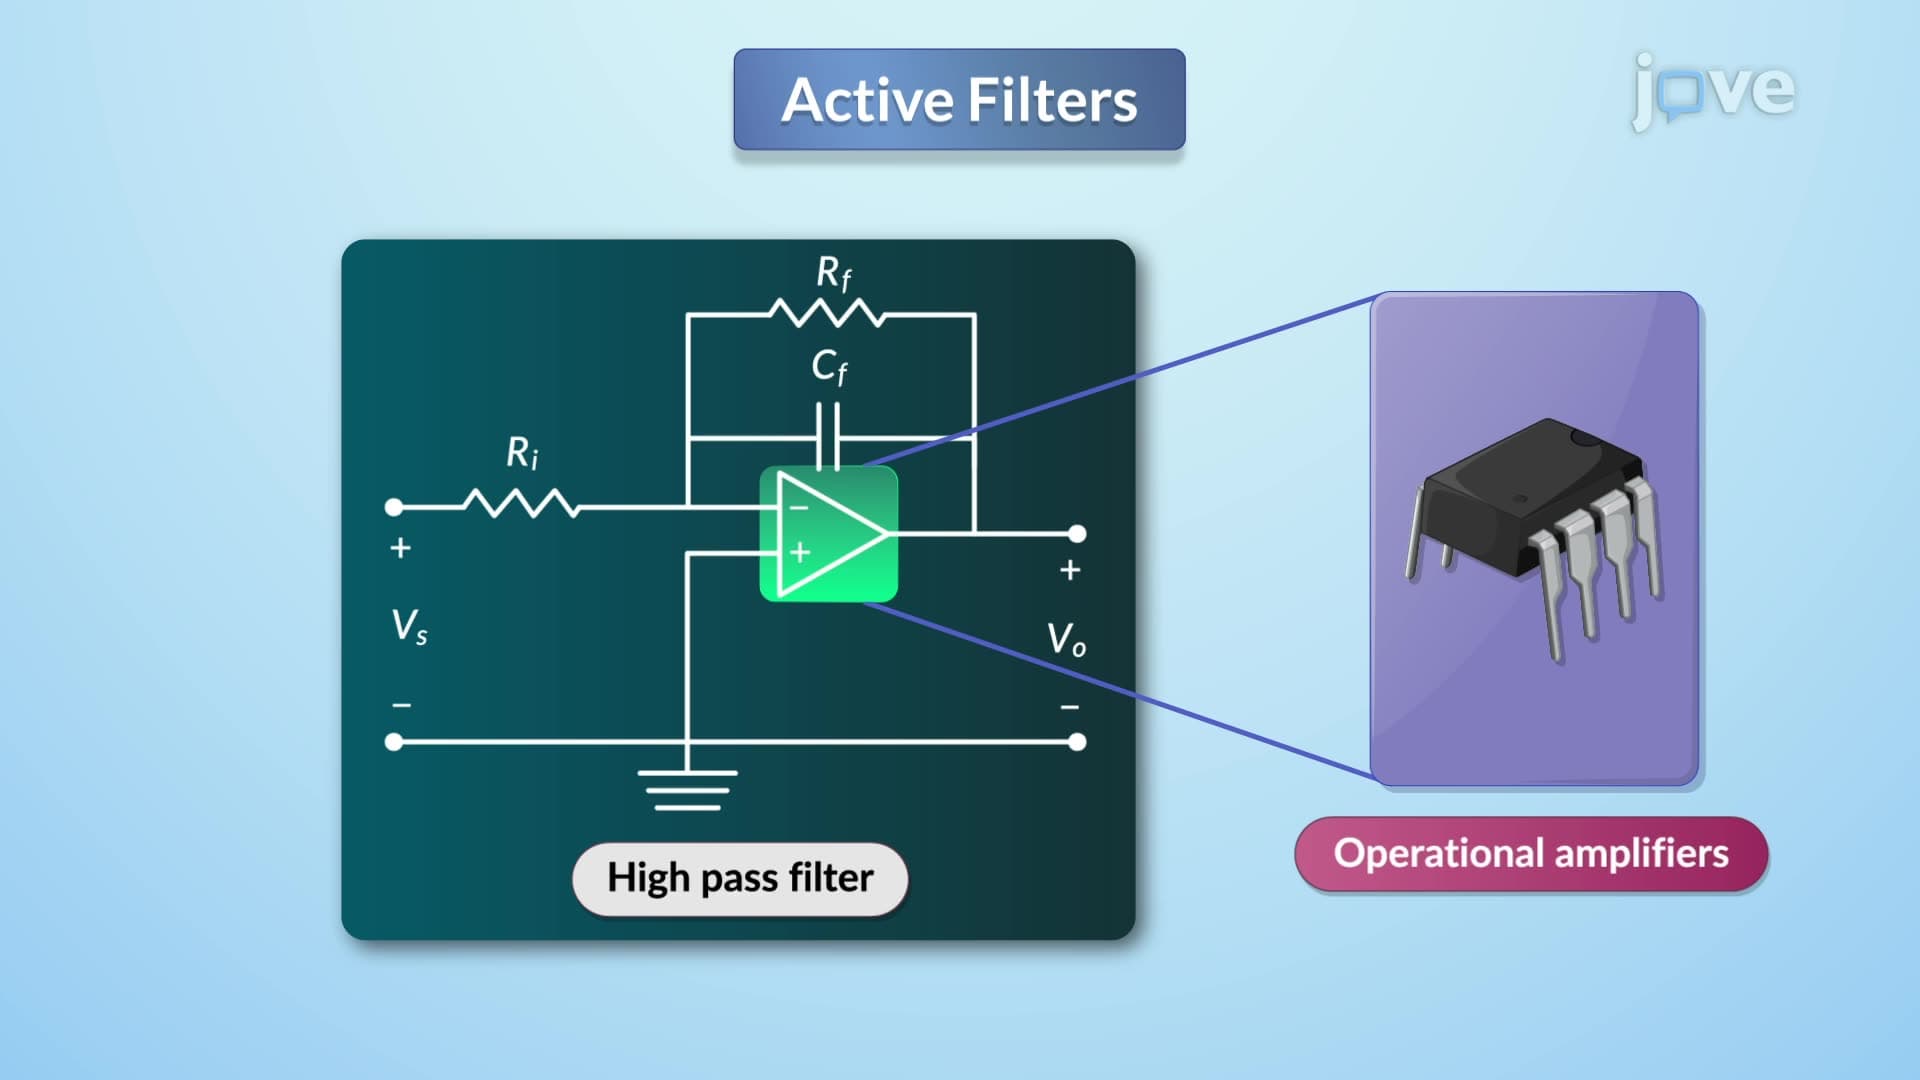
Active Filters
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the system's...
 01:27
Passive Filters
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff frequency...
 02:18
Interference and Diffraction
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:11
Sampling Continuous Time Signal
In the...