Related Experiment Video
Updated: Oct 28, 2026
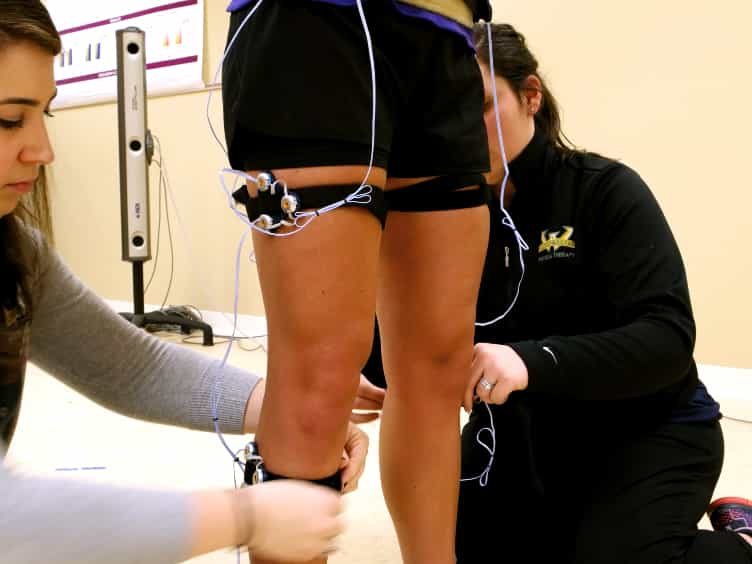
Video Movement Analysis Using Smartphones (ViMAS): A Pilot Study
Published on: March 14, 2017
Multi-View RGB Visual Sensing and Motion State Quantification of Slope Scene Visual Cues for Mobile Emergency
1College of Computer and Data Science, Fuzhou University, Fuzhou 350108, China.

Abstract:
Mobile emergency excavation motivates close-range sensing near unstable slopes. We evaluated a laboratory-scale red/green/blue (RGB) framework combining optimized YOLOv8n-Seg, ByteTrack and the Visual Geometry Grounded Transformer for instance perception, motion quantification and scene reconstruction. Synchronized frames and pixel-to-point correspondence linked instances to reconstructed geometry. Structural scaling and masked feature distillation yielded 1.03 million parameters and 2.04 billion floating-point operations. On the development validation subset, the mask mean average precision at intersection-over-union thresholds of 0.50-0.95 was 54.62%. Raspberry Pi 4B inference using Open Neural Network Exchange (ONNX) required 258.70 ms/image. Independent evaluation covered nine conditions with three separately prepared recordings each. Pooled Higher Order Tracking Accuracy and Identification F1 Score were 89.07 ± 0.17% and 92.50 ± 0.27% (mean ± sample standard deviation). The condition-wise mean velocity and slope root mean square errors ranged from 0.0092 to 0.0546 m/s and 2.0528° to 3.5596°, respectively. Against physical references, the mean relative dimensional errors ranged from 7.092% to 7.632%. Highlighted 3D instances, velocity heatmaps with motion vectors and occupancy density heatmaps supported scene interpretation. The results establish laboratory feasibility; moving-platform and field reliability require further validation.