Related Experiment Video
Updated: Oct 28, 2026
Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
Unified Model of Magnetoresistive Angular Position Sensors with Manufacturing Tolerances
Vladimir Čeperković1, Vladimir Rajović2, Jelena Elez2
1Synchrotek d.o.o., Mihajlo Pupin Blvd. 115a, 11070 Belgrade, Serbia.

Abstract:
This paper presents a unified model of magnetoresistive angular position sensors, applicable to sensors based on the three major sensor technologies: Anisotropic Magnetoresistance, Giant Magnetoresistance, and Tunnel Magnetoresistance magnetoresistive elements. Theoretical models of the three different magnetoresistive elements, including manufacturing tolerances, have been derived first. The models are then employed to derive a realistic model of a magnetoresistive measurement bridge. In order to construct a model of a magnetoresistive magnetic field direction sensor, besides bridge models, a novel model of a free ferromagnetic layer has been developed. Finally, a unified magnetoresistive angular position sensor model has been obtained by combining the magnetic field direction sensor and a simple model of a permanent magnet. The experimental results confirmed the validity of the proposed model.
Related Concept Videos
 01:11
Angular Momentum about an Arbitrary Axis
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into the angular...
 01:09
Relating Angular And Linear Quantities - I
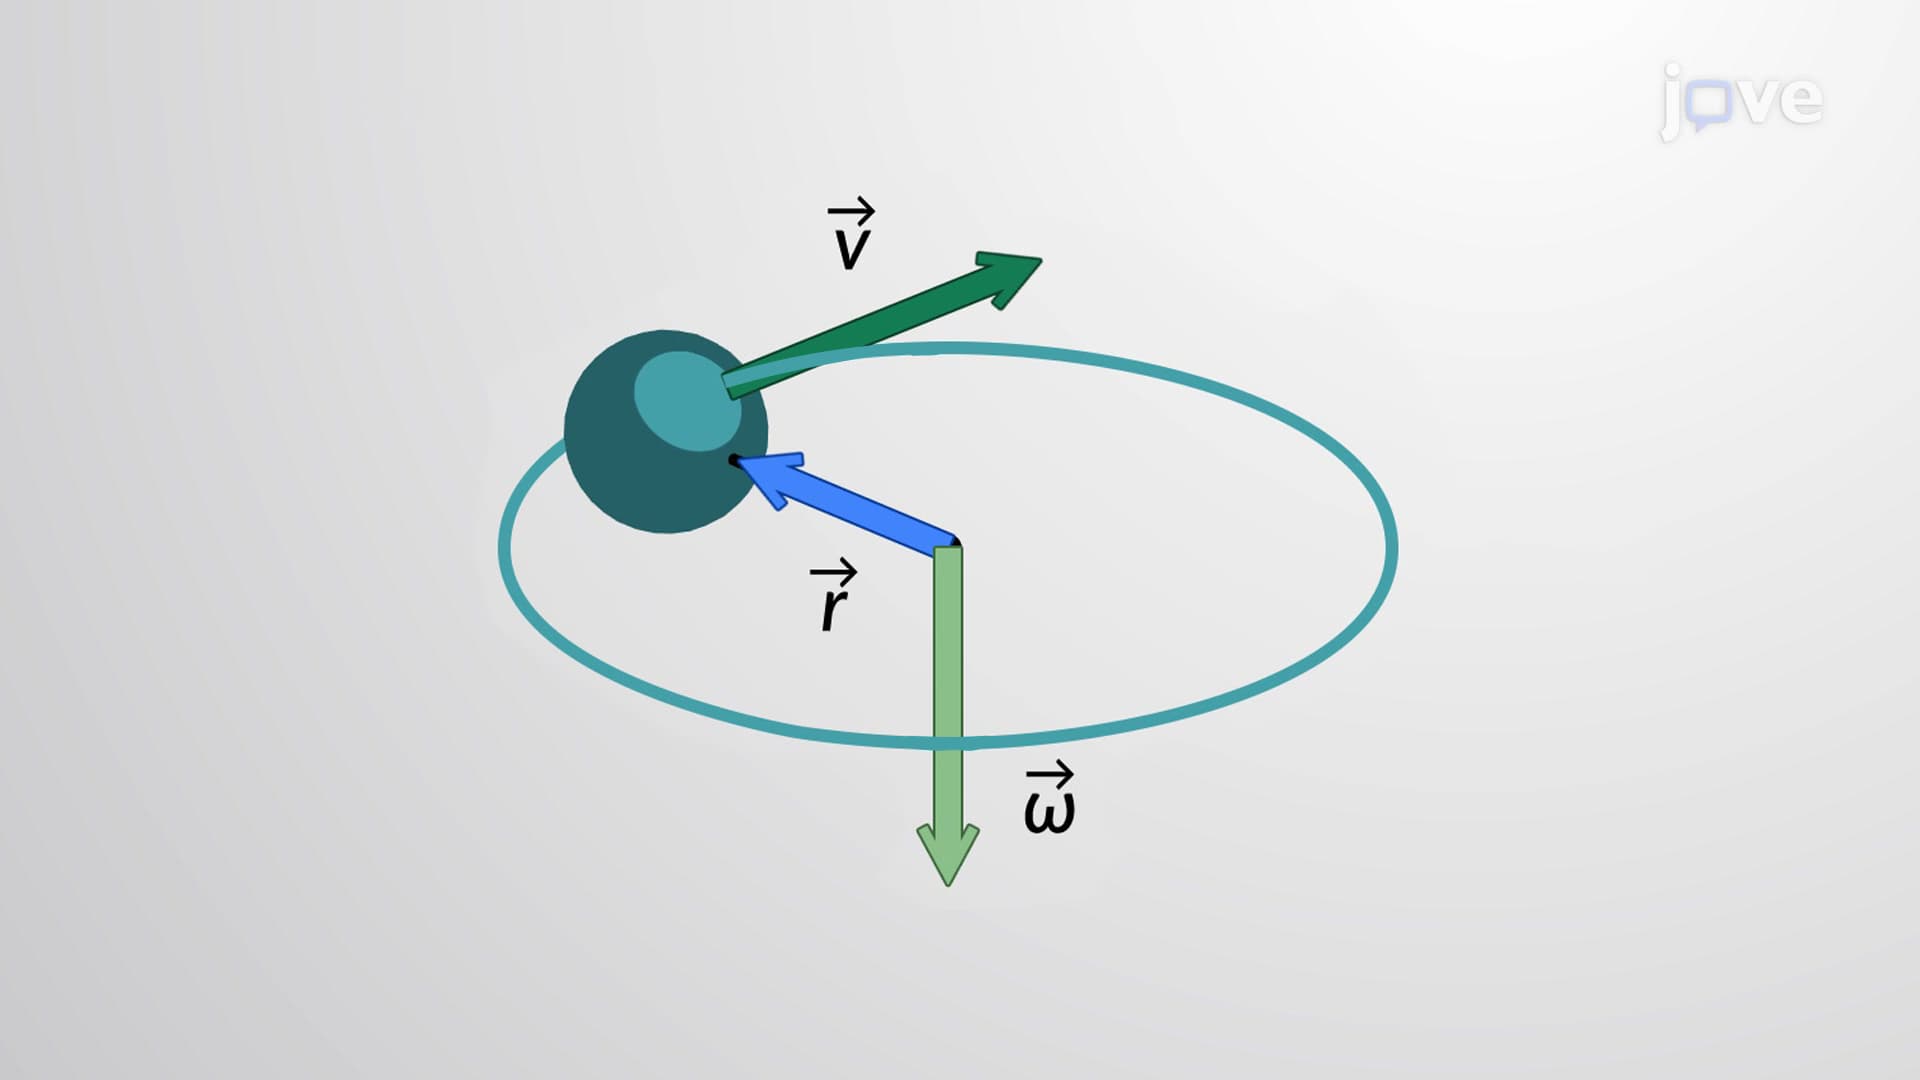
When comparing the linear and rotational variables individually, the linear variable of position has physical units of meters, whereas the angular position variable has dimensionless units of radians, as it is the ratio of two lengths. The linear velocity...
 01:13
Angle of Twist: Problem Solving