Related Experiment Videos
VIPA: View-Invariant Projector-Based Adversarial Attack

Abstract:
Projector-based adversarial attack aims to physically manipulate real-world scenes by projecting adversarial patterns, thereby causing deep image classifiers to produce incorrect predictions. However, existing stealthy projector-based adversarial attack methods model the project-and-capture process in a single and static view, limiting their view-invariant capability and practical applicability in dynamic environments. In this paper, we introduce View-Invariant Projector-Based Adversarial Attack (VIPA), a novel method designed to overcome these limitations by achieving both view-invariant and classifier-agnostic adversarial attacks in the physical world. We first leverage a view-invariant projector-camera system simulation method to model the physical interactions between projected patterns and real-world surfaces. To ensure robustness and stealthiness of the attack across different views, VIPA optimizes adversarial projections by aggregating simulated attack losses from multiple views. This joint optimization across diverse views helps maintain robustness regardless of the viewpoints. Finally, the optimized patterns are physically projected into real-world scenes, where they successfully fool various classifiers from different viewpoints, thereby enabling robust and practical view-invariant adversarial attacks. Our experiments in both targeted and untargeted attacks demonstrate that VIPA consistently achieves higher attack success rates than existing methods, while also enhancing stealthiness and ensuring minimal perceptual degradation across all tested views.
Related Concept Videos
 01:19
Masking and Demasking Agents
There are many masking agents, such as cyanide, fluoride, triethanolamine, thiourea, and 2,3-bis(sulfanyl)propan-1-ol (formerly 2,3-dimercapto-1-propanol), with the masking agent chosen based on the metal...
 01:28
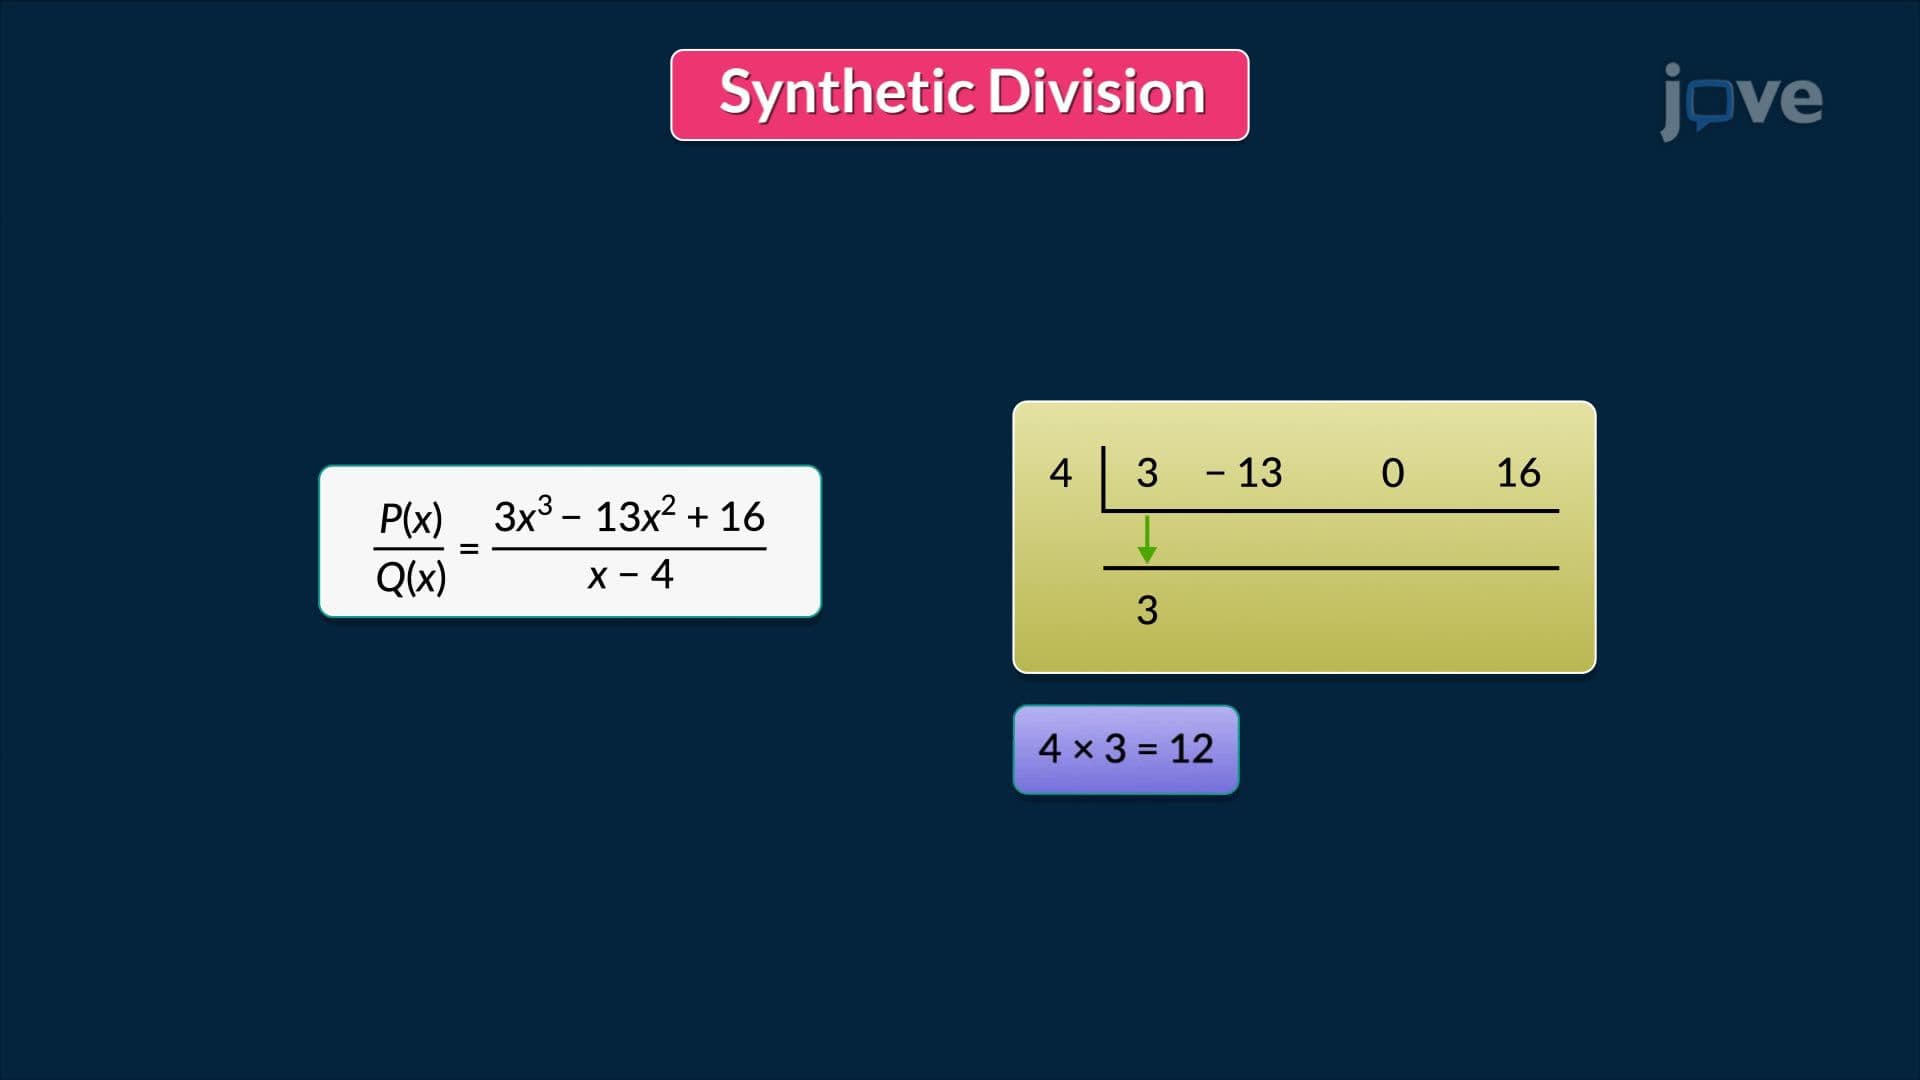
Synthetic Disvision of Polynomials
 01:06
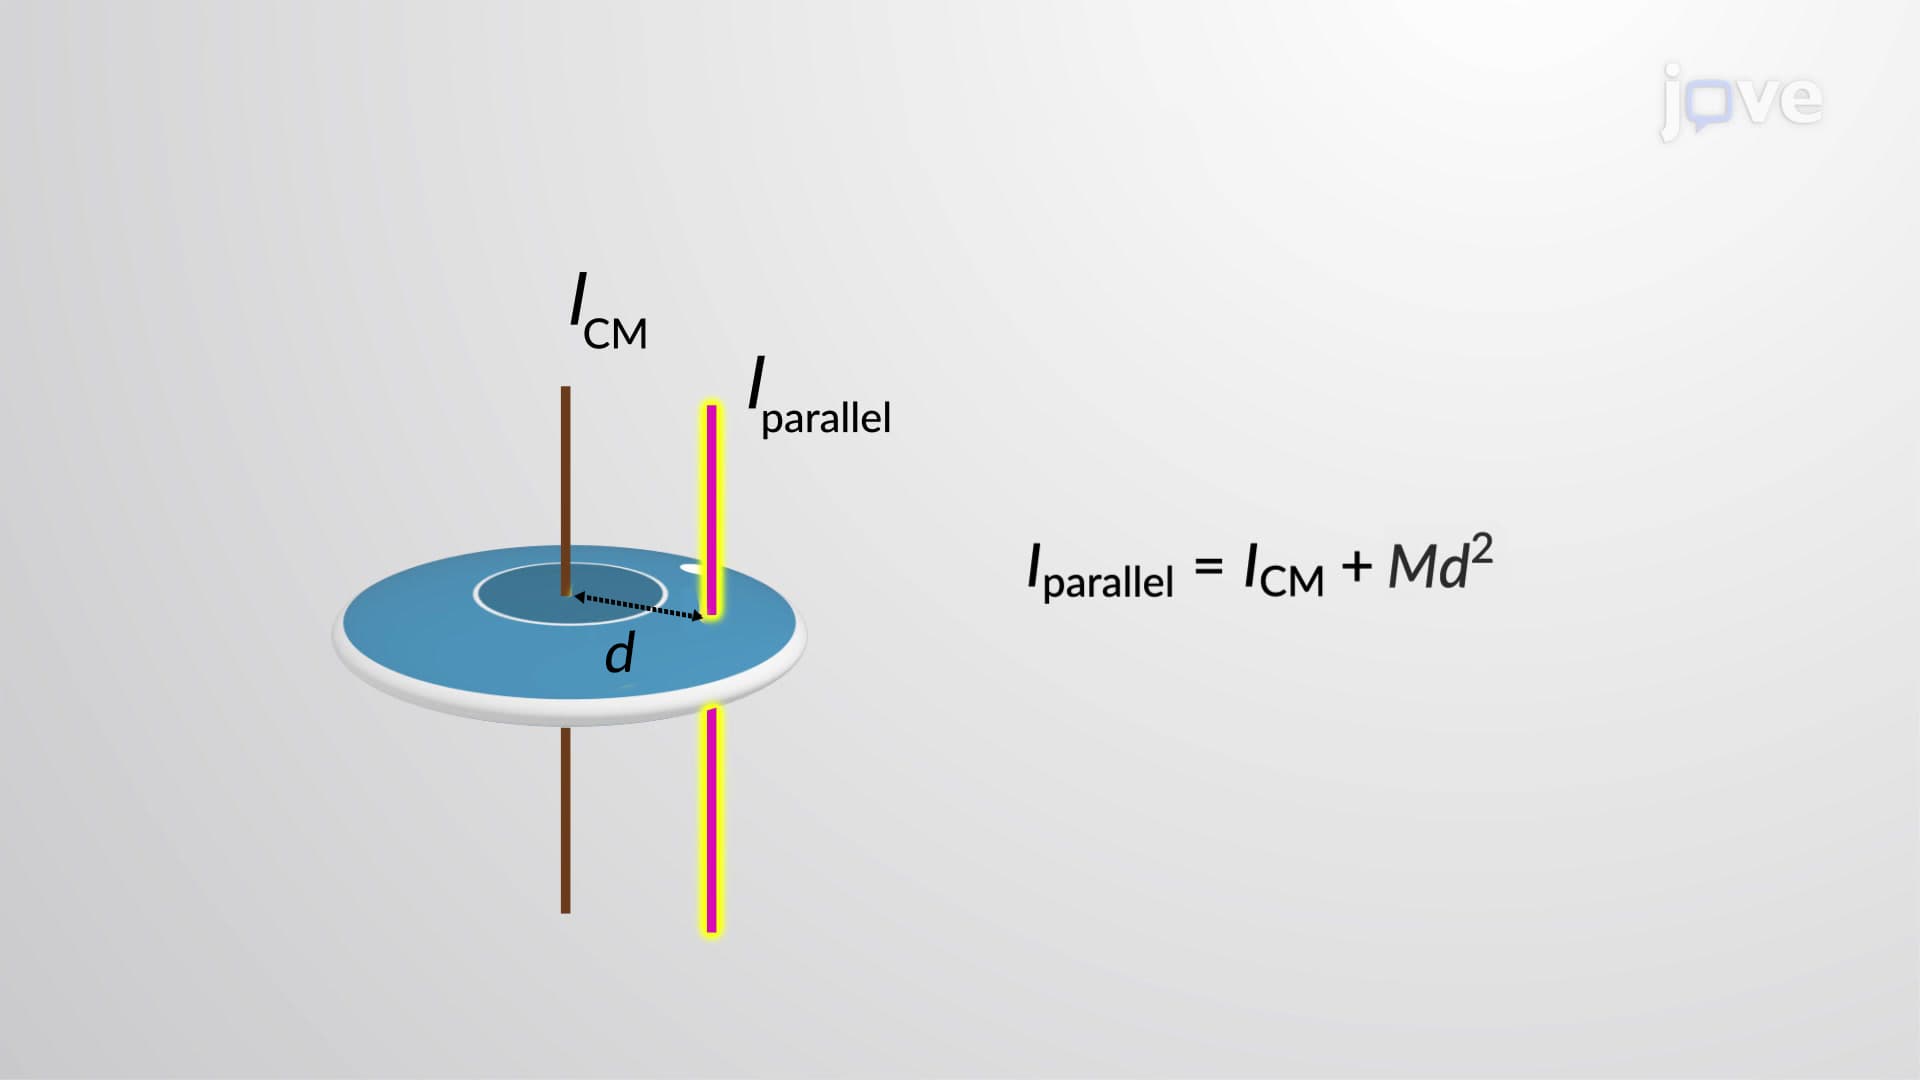
Parallel-axis Theorem
 01:24
Theorem of Pappus
 01:16
Perpendicular-Axis Theorem
Consider a circular disc of mass M and radius R lying along an x-y plane. The origin lies at the center of the disc, and the z-axis is perpendicular to the disc's plane. All three axes coincide at the disc's center. The moment of inertia of this...
 02:07
Blind Procedures