Related Experiment Video
Updated: Oct 29, 2026
Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
In Sight of Insights: Virtual Representation of Boxing for Interactive Viewpoint in Tactical Analysis through 3D

Abstract:
Combat sports such as boxing require rapid tactical decision-making and precise spatio-temporal awareness, yet current analysis primarily relies on video replays and statistical charts. Fixed viewpoints and occlusion constrain video replays, while statistical data are displayed separately, requiring users to mentally correlate information across sources. Although prior sports analytics research has explored event detection, action recognition, and video overlays, few systems support spatially navigable motion reconstruction with integrated tactical annotations for real combat-sport matches. To address this gap, we conducted a formative study with professional boxing coaches and developed In Sight of Insights, a desktop immersive analytics system that reconstructs athlete motion from sparse multi-view video and embeds match events within a unified 3D virtual environment. By coupling contextual information with reconstructed motion, the system enables free-viewpoint tactical observation while preserving links to source video evidence. We evaluated our system through two user studies with professional athletes and experienced spectators. The results provide preliminary evidence that Free-viewpoint Virtual Representation can improve tactical observation accuracy and support comparable analytical efficiency relative to a video-based workflow with access to the same annotated match data. Participants also reported that free viewpoint perspectives and integrated contextual visualization enhanced tactical understanding. These findings position reconstructed 3D environments with embedded analytics as a promising approach for combat-sport tactical analysis, while highlighting practical constraints around annotation effort, capture setup, and evaluation scale.
Related Concept Videos
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
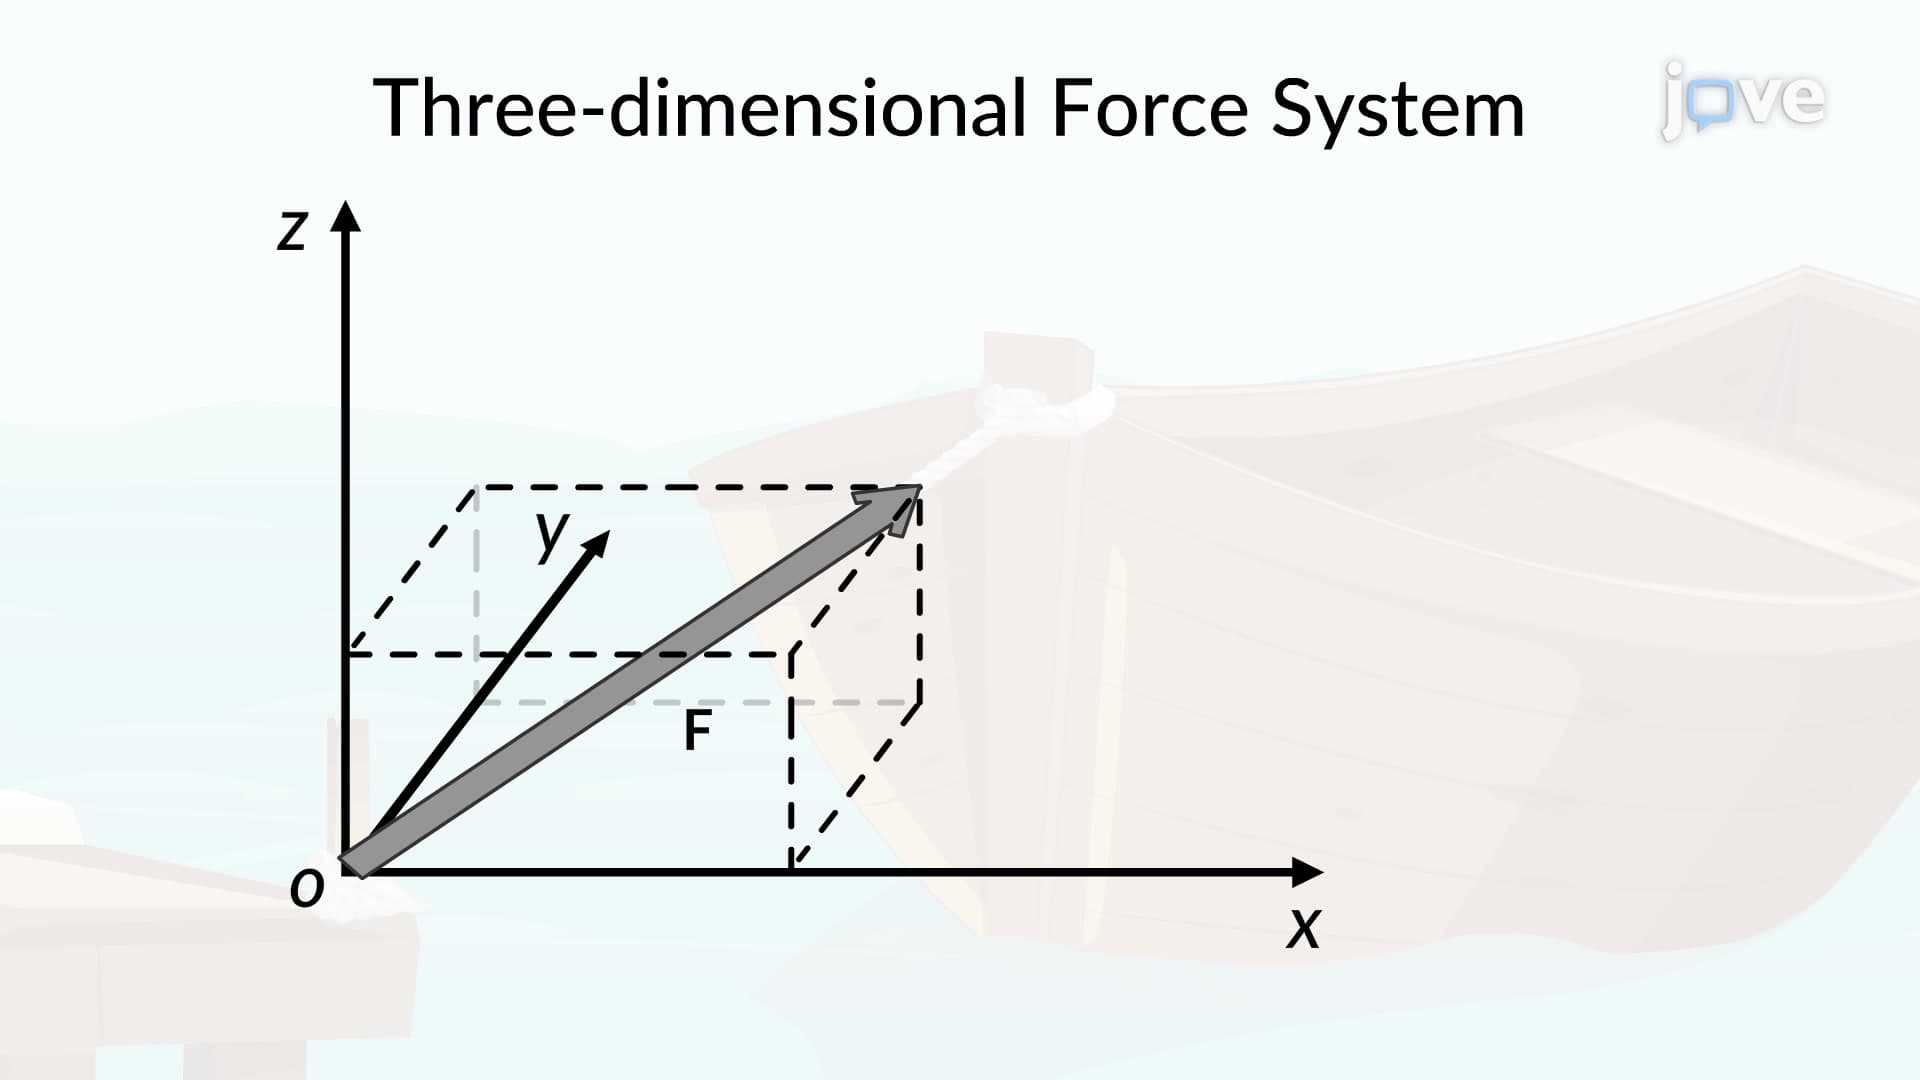
Three-Dimensional Force System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:34
Velocity and Position by Graphical Method