Lighting and clothing effects on Theia3D markerless joint-angle waveforms during walking
Related Experiment Video
Updated: Oct 30, 2026
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
Annika Langenohl1, Lutz Vogt2, Fabian Horst3
1Department of Sports Medicine and Exercise Physiology, Institute of Sport Sciences, Goethe University Frankfurt, Ginnheimer Landstraße 39, Frankfurt am Main, 60487, Germany; Department of Training and Movement Science, Institute of Sport Sciences, Johannes Gutenberg-University Mainz, Albert Schweitzer Straße 22, Mainz, 55128, Germany.

Abstract:
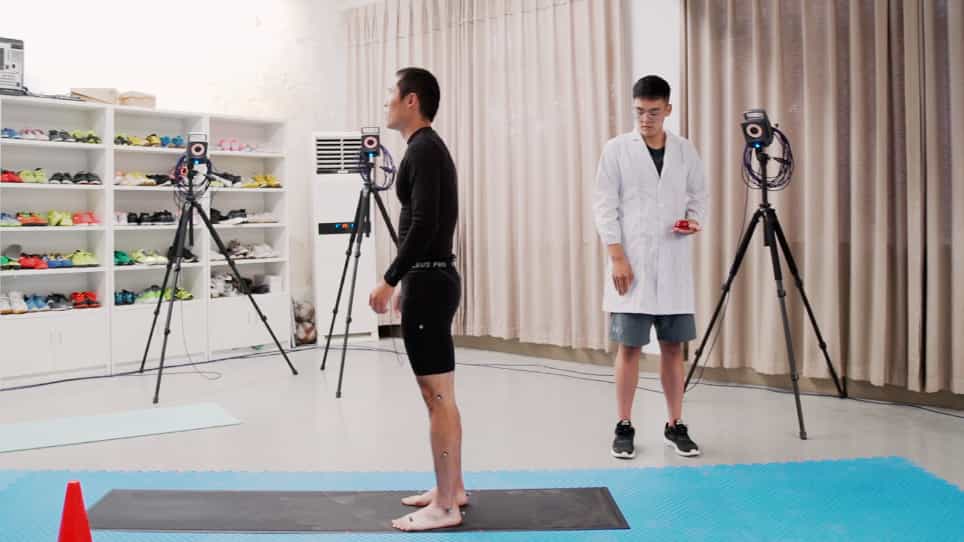
Markerless motion capture may enable three-dimensional gait analysis outside dedicated laboratory settings, but the resulting kinematics may depend on acquisition conditions such as lighting and clothing. This study investigated pose-estimation feasibility, waveform consistency, and absolute waveform differences in Theia3D-derived joint-angle waveforms under systematically varied lighting-clothing combinations in an indoor laboratory environment. Twenty healthy adults performed overground walking trials under 15 acquisition conditions combining five lighting and three clothing conditions. Video recordings from eight cameras (1,920 × 1,080 pixels, 85 Hz) were analyzed using Theia3D to derive lower- and upper-body joint-angle waveforms in the sagittal, frontal, and transverse planes. Waveform consistency across acquisition conditions was quantified using the intraclass correlation coefficient (ICC(C,1)), and absolute waveform differences were quantified using root mean square difference (RMSD). Joint-angle waveforms were generated for all participants in 11 of the 15 acquisition conditions, with reduced feasibility confined to extreme acquisition conditions. Across retained conditions, waveform consistency and absolute differences were joint- and plane-specific. Sagittal-plane lower-body joint angles showed high waveform consistency, with ICC(C,1) values of 0.983-0.998 and mean pairwise RMSDs of 1.24°-1.80°, whereas transverse-plane angles showed more variable consistency, with ICC(C,1) values of 0.505-0.986 and mean pairwise RMSDs of 1.37°-5.45°, particularly for the shoulder and elbow. These findings show that acquisition-condition effects on Theia3D-derived joint-angle waveforms are joint- and plane-specific and that feasibility is maintained across most of the tested lighting-clothing combinations. Clothing and lighting conditions should therefore be kept as consistent as practicable across comparative and repeated measurements.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...