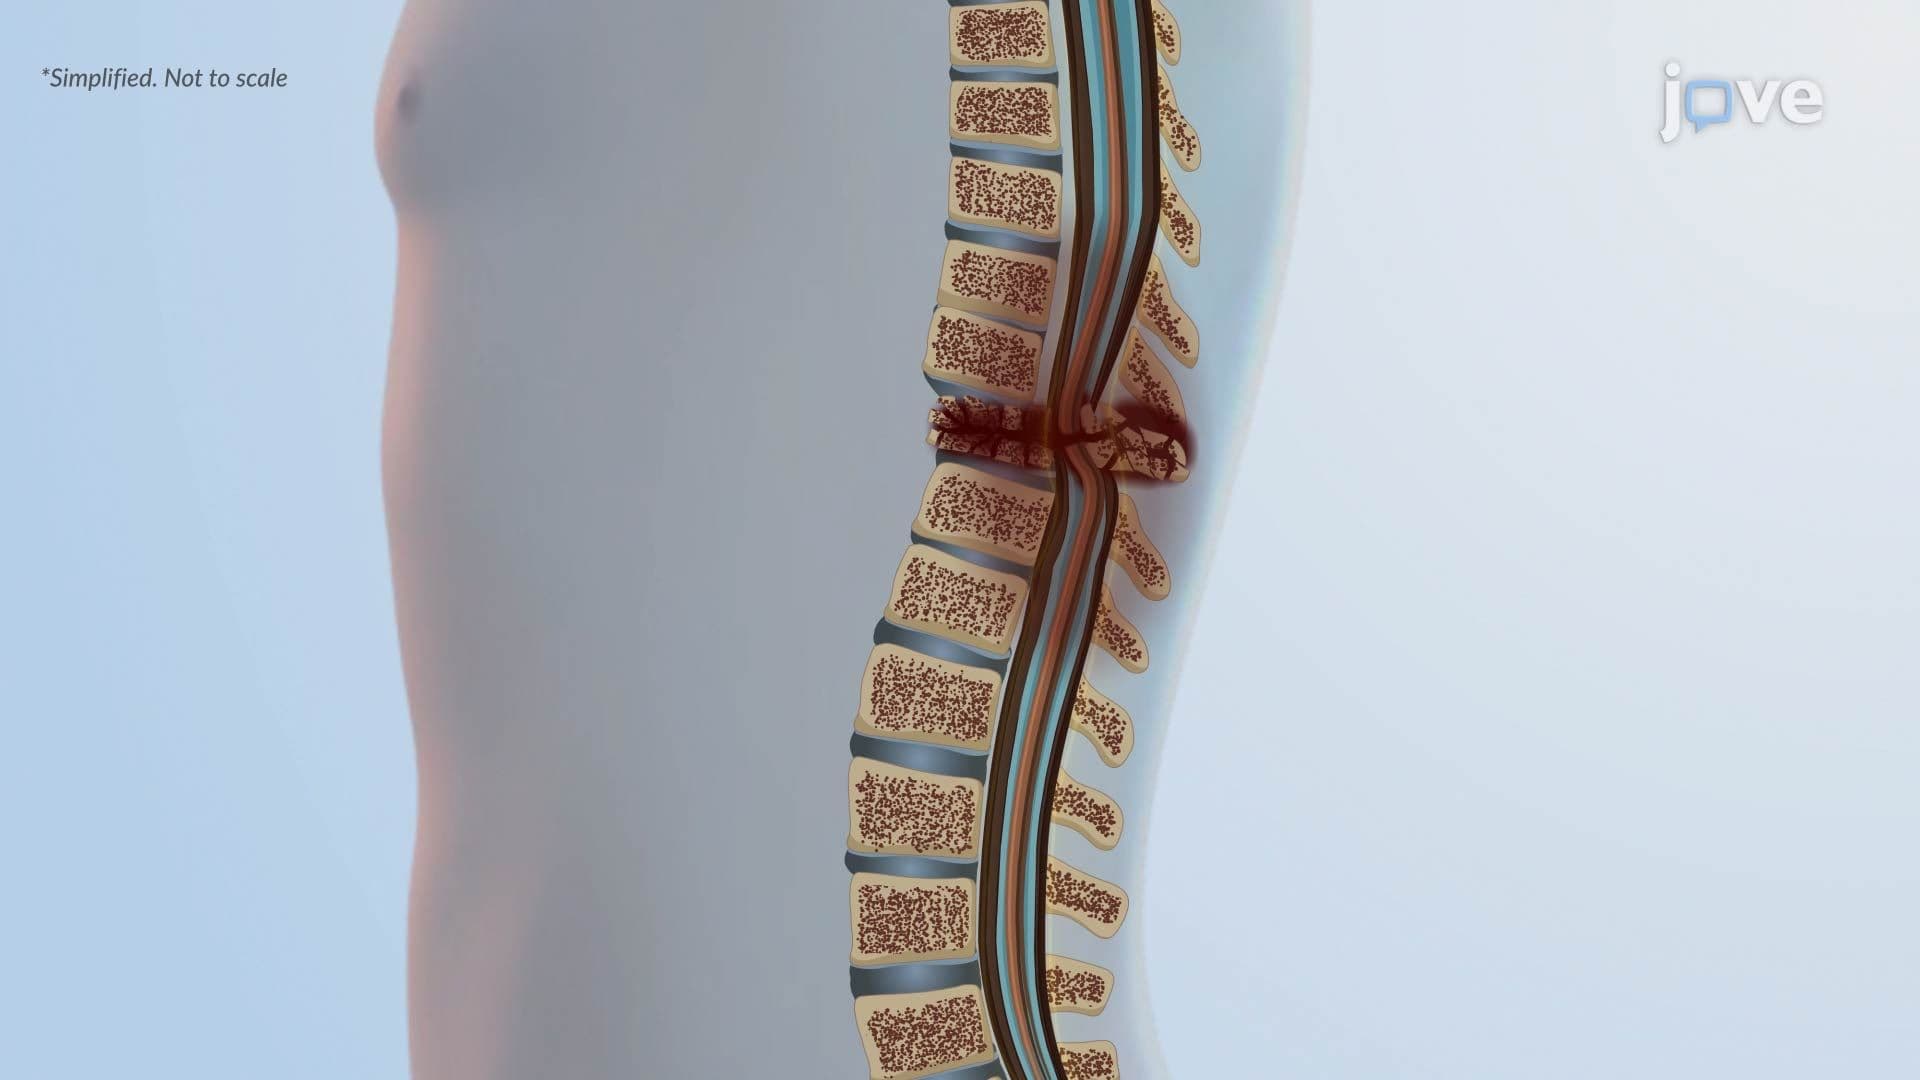
Closed-loop neuroprosthetic control through spared neural activity enables proportional foot movements after spinal cord injury
Related Experiment Video
Updated: Oct 31, 2026
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Vlad Cnejevici1, Matthias Ponfick2, Dietmar Fey3
1Department Artificial Intelligence in Biomedical Engineering, Friedrich-Alexander-Universität Erlangen-Nürnberg, Nürnberger Strasse 74, Erlangen, Bavaria, 91052, Germany.

Objective:
Loss of voluntary foot movement after spinal cord injury (SCI) can significantly limit independent mobility and quality of life. To improve motor output after injury, functional electrical stimulation (FES) is used to deliver stimulation pulses through the skin to affected muscles. While commercial FES systems typically use motion-based triggers, prior research shows that spared movement intent can be decoded after SCI using surface electromyography (EMG). Our aim is to assess how well spared neural signals of the lower limb after SCI can be decoded and used to control electrical stimulation for restoring foot movement.
Approach:
We developed a wearable machine-learning-powered neuroprosthetic that records EMG from the affected lower limb using a 32-channel electrode bracelet and enables closed-loop control of an FES device for foot movement restoration.
Main Results:
Five participants with SCI used the predicted control signal to follow trajectories on a screen with their foot and achieve distinct motor activation patterns for foot flexion, extension, and inversion or eversion. Three of these participants also achieved 2 proportional activation levels during foot flexion/extension with >70% overall accuracy. To validate how these neural signals can be used for closed-loop neuroprosthetic control, two participants used their decoded activity to control an FES device and stimulate their affected foot. This resulted in an increased foot flexion range in every stimulated contraction for both participants, on average 33.6% and 40% of a functional healthy range, respectively (p < 0.001). One of the participants also achieved voluntary proportional control of up to 6 stimulation levels during foot flexion/extension.
Significance:
These results suggest that wearable EMG decoding coupled with FES systems provides a scalable strategy for closed-loop neuroprosthetic control supporting voluntary foot movement.
More Related Videos
 08:55
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
 06:58
A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015