Reactive safety-critical scenario generation for autonomous driving via interaction-adaptive diffusion
Related Experiment Video
Updated: Oct 31, 2026
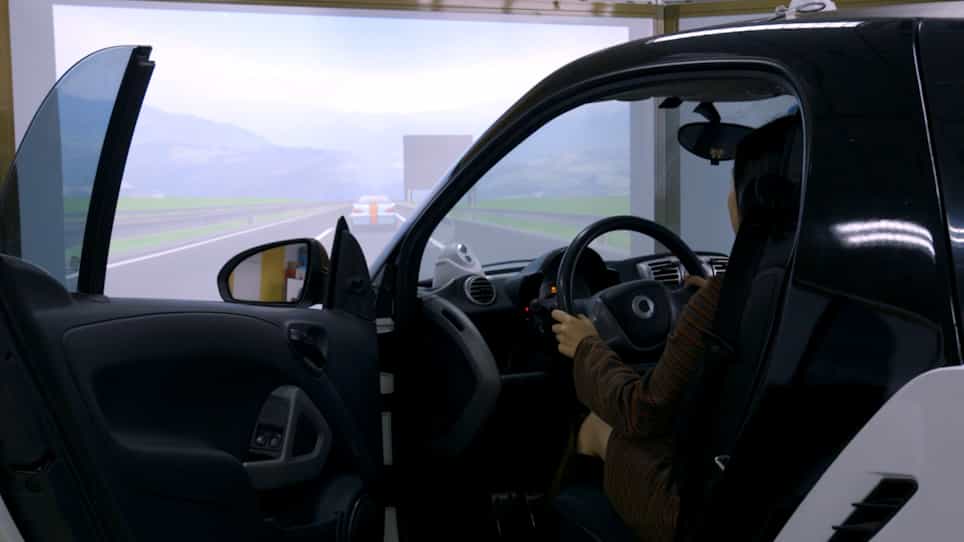
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Jialei Nie1, Hengyang Sun1, Chujun Xia1
1College of Automotive and Energy Engineering, Tongji University, Shanghai 200092, China.

Abstract:
Safety-critical scenario generation is essential for testing automated driving systems under rare but consequential traffic interactions. Although existing methods have advanced this task, they still have limited capability to adapt the generated behavior of the adversarial vehicle (ADV) to evolving ego-ADV interactions, yielding non-reactive cases or hard-collision outcomes that limit the generation of sustained critical interactions. We propose Reactive Interaction-Guided Diffusion (RIGD), an interaction-adaptive diffusion framework for safety-critical scenario generation. RIGD uses interaction-driven adaptive truncated diffusion to refine a prediction-derived high-risk prior according to the current conflict condition. It further introduces reactive balance guidance to adjust adversarial trajectories during denoising, producing challenging and responsive critical interactions. Closed-loop evaluation in the Waymax simulator demonstrates that RIGD increases the effective critical-event rate and strengthens reactive ADV responses while maintaining competitive behavioral fidelity. Averaged over four baselines and three ego-motion settings, RIGD achieves relative improvements of 31.4% and 31.7% in effective critical-event rate and reaction gain, and relative reductions of 33.9% and 8.6% in hard-collision rate and acceleration distribution distance, respectively.