Conditional diffusion-based inverse kinematics for redundant 7-DOF manipulators with differentiable refinement
Related Experiment Video
Updated: Nov 2, 2026

Operation of the Collaborative Composite Manufacturing (CCM) System
Published on: October 1, 2019
Lesia Hentosh1, Yaroslav Hladun1, Ivan Tsmots1
1Department of Artificial Intelligence Systems, Lviv Polytechnic National University, Lviv, Ukraine.

Background:
Inverse kinematics of redundant manipulators is a multi-solution problem, since one end-effector pose may correspond to multiple admissible joint configurations. Classical numerical solvers and regression-based neural models usually return a single joint configuration and therefore do not explicitly represent the inverse-kinematic solution manifold. Existing generative solvers based on normalizing flows produce multiple solutions, but they require invertible network architectures and do not include an explicit task-space correction stage. This study aimed to develop a hybrid generative-kinematic method for inverse kinematics of a redundant 7-DOF manipulator that can generate multiple admissible configurations for a given target pose.
Methods:
A hybrid method, DiffusionIK, was developed by combining conditional diffusion-based generation, classifier-free guidance, DDIM sampling, and differentiable forward-kinematics refinement. A ResMLP denoiser is trained in the normalized joint space using procedurally generated training pairs obtained from the forward kinematics of the xArm manipulator. For each target pose, the diffusion model generated multiple candidate joint configurations, and the refinement stage subsequently reduced the task-space residual for each candidate. Numerical experiments were performed on 500 reachable target poses with 50 generated candidates per pose. Performance was evaluated using position and orientation success thresholds of 1 mm and 1°, respectively, together with the preservation of joint-space variability after refinement.
Results:
DiffusionIK reached 99.40% success after 200 refinement steps and 100.00% after 500 steps under 1 mm and 1° thresholds, with a mean joint-space variability of 9.77 rad. In a unified benchmark against damped least squares, KDL, direct regression, and a normalizing-flow baseline, DiffusionIK with refinement achieved 99.80% success on 500 unseen poses and 98.40% near singularities, matching the strongest numerical solver while returning 50 diverse solutions per pose.
Conclusion:
The proposed DiffusionIK method provides an effective formulation of redundant inverse kinematics as conditional generation followed by local kinematic correction. By combining diffusion-based candidate generation with differentiable forward-kinematics refinement, the method represents the multi-solution nature of redundant manipulators and achieves high task-space accuracy while preserving configuration diversity. Unlike normalizing-flow-based solvers, DiffusionIK imposes no invertibility constraints on the denoiser and combines generation with differentiable forward-kinematics refinement, which provides sub-millimetre and sub-degree accuracy together with configuration diversity.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
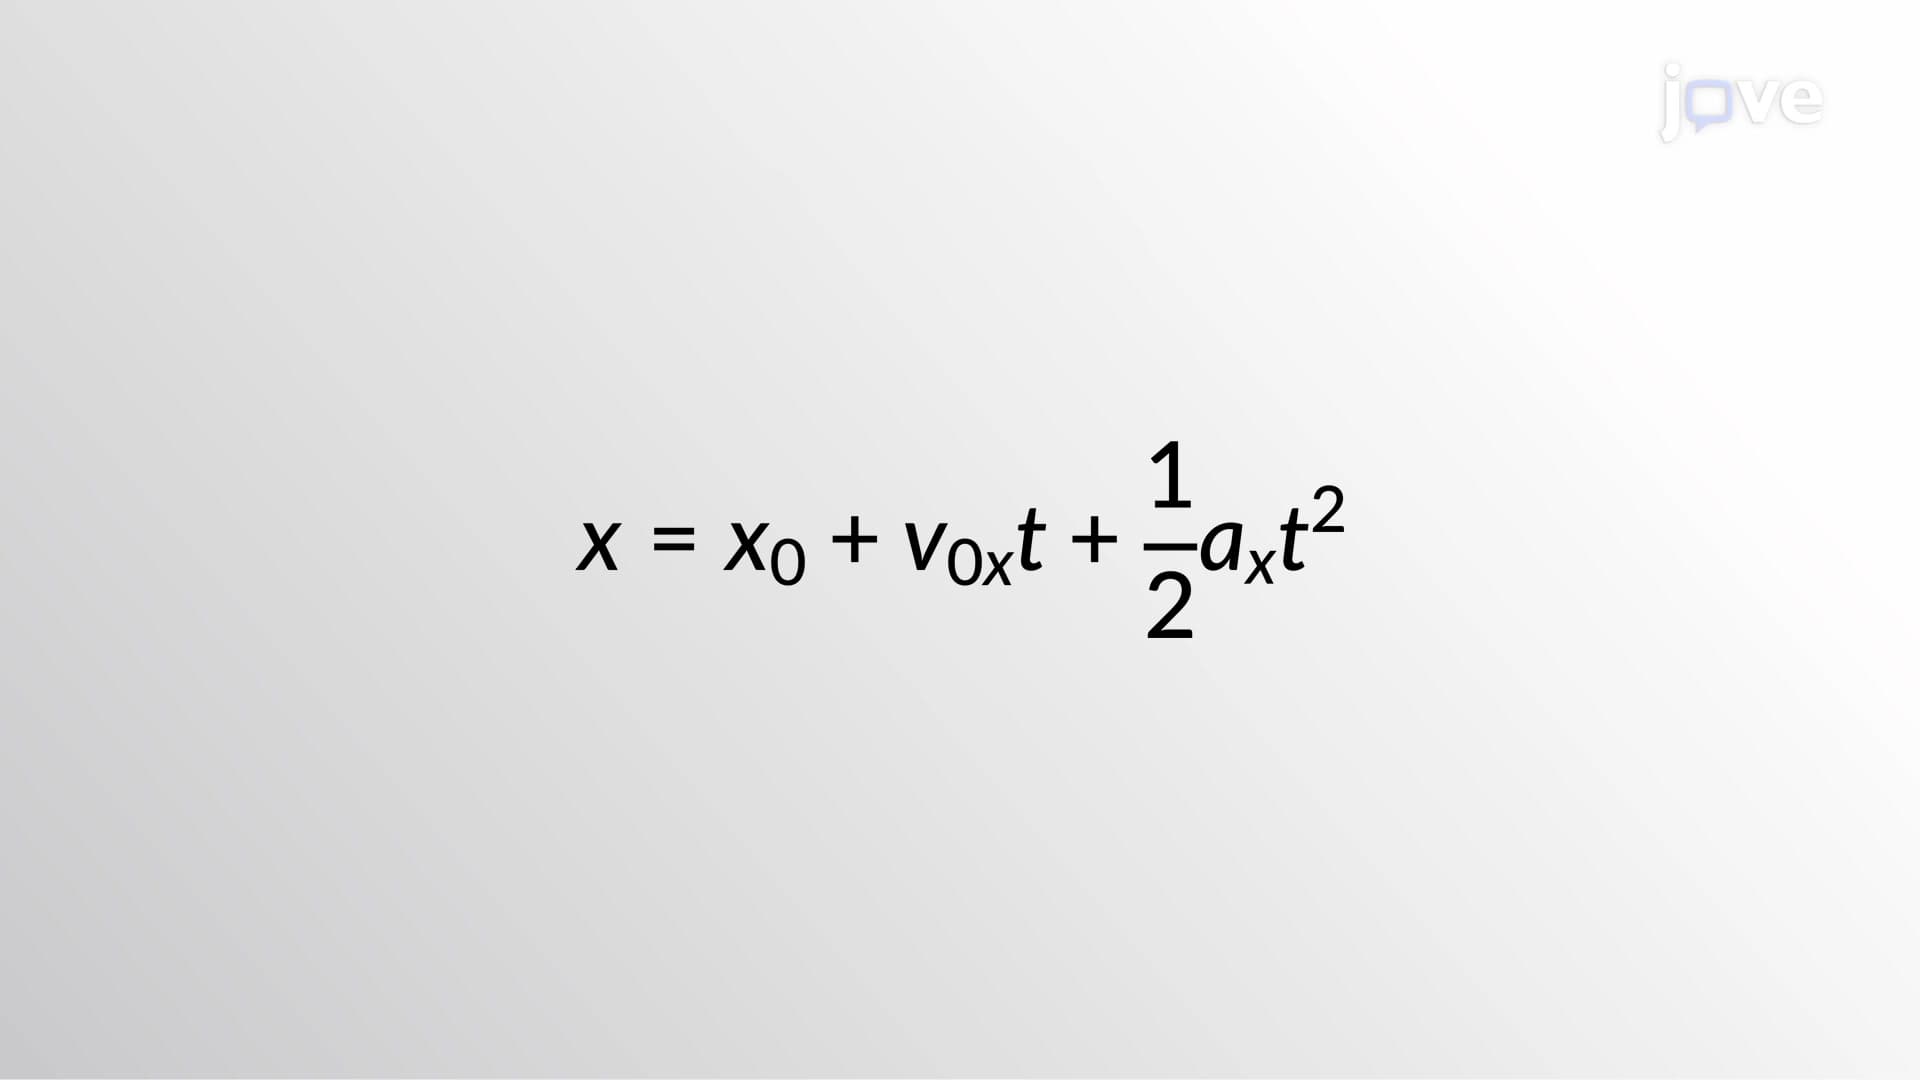 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
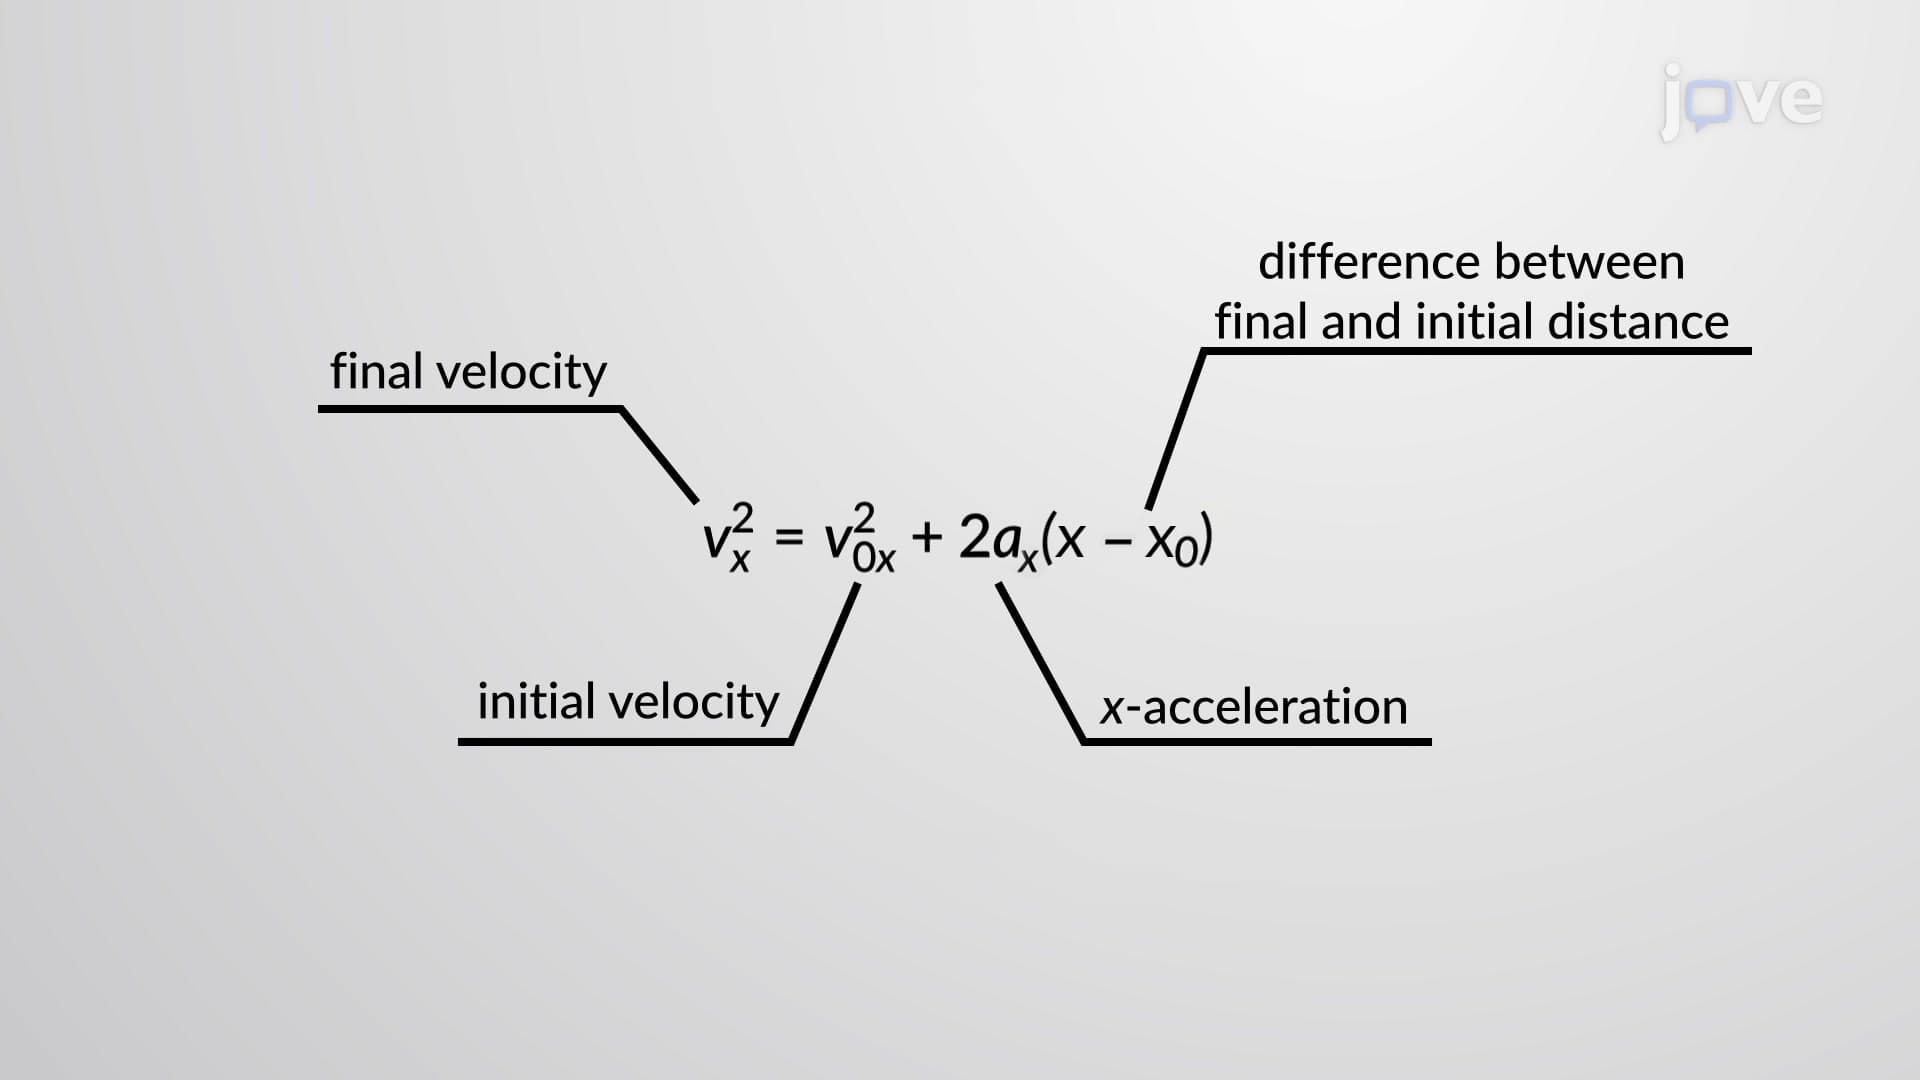
Kinematic Equations: Problem Solving
 01:18
Kinematic Equations - III
Using the kinematic equations,...
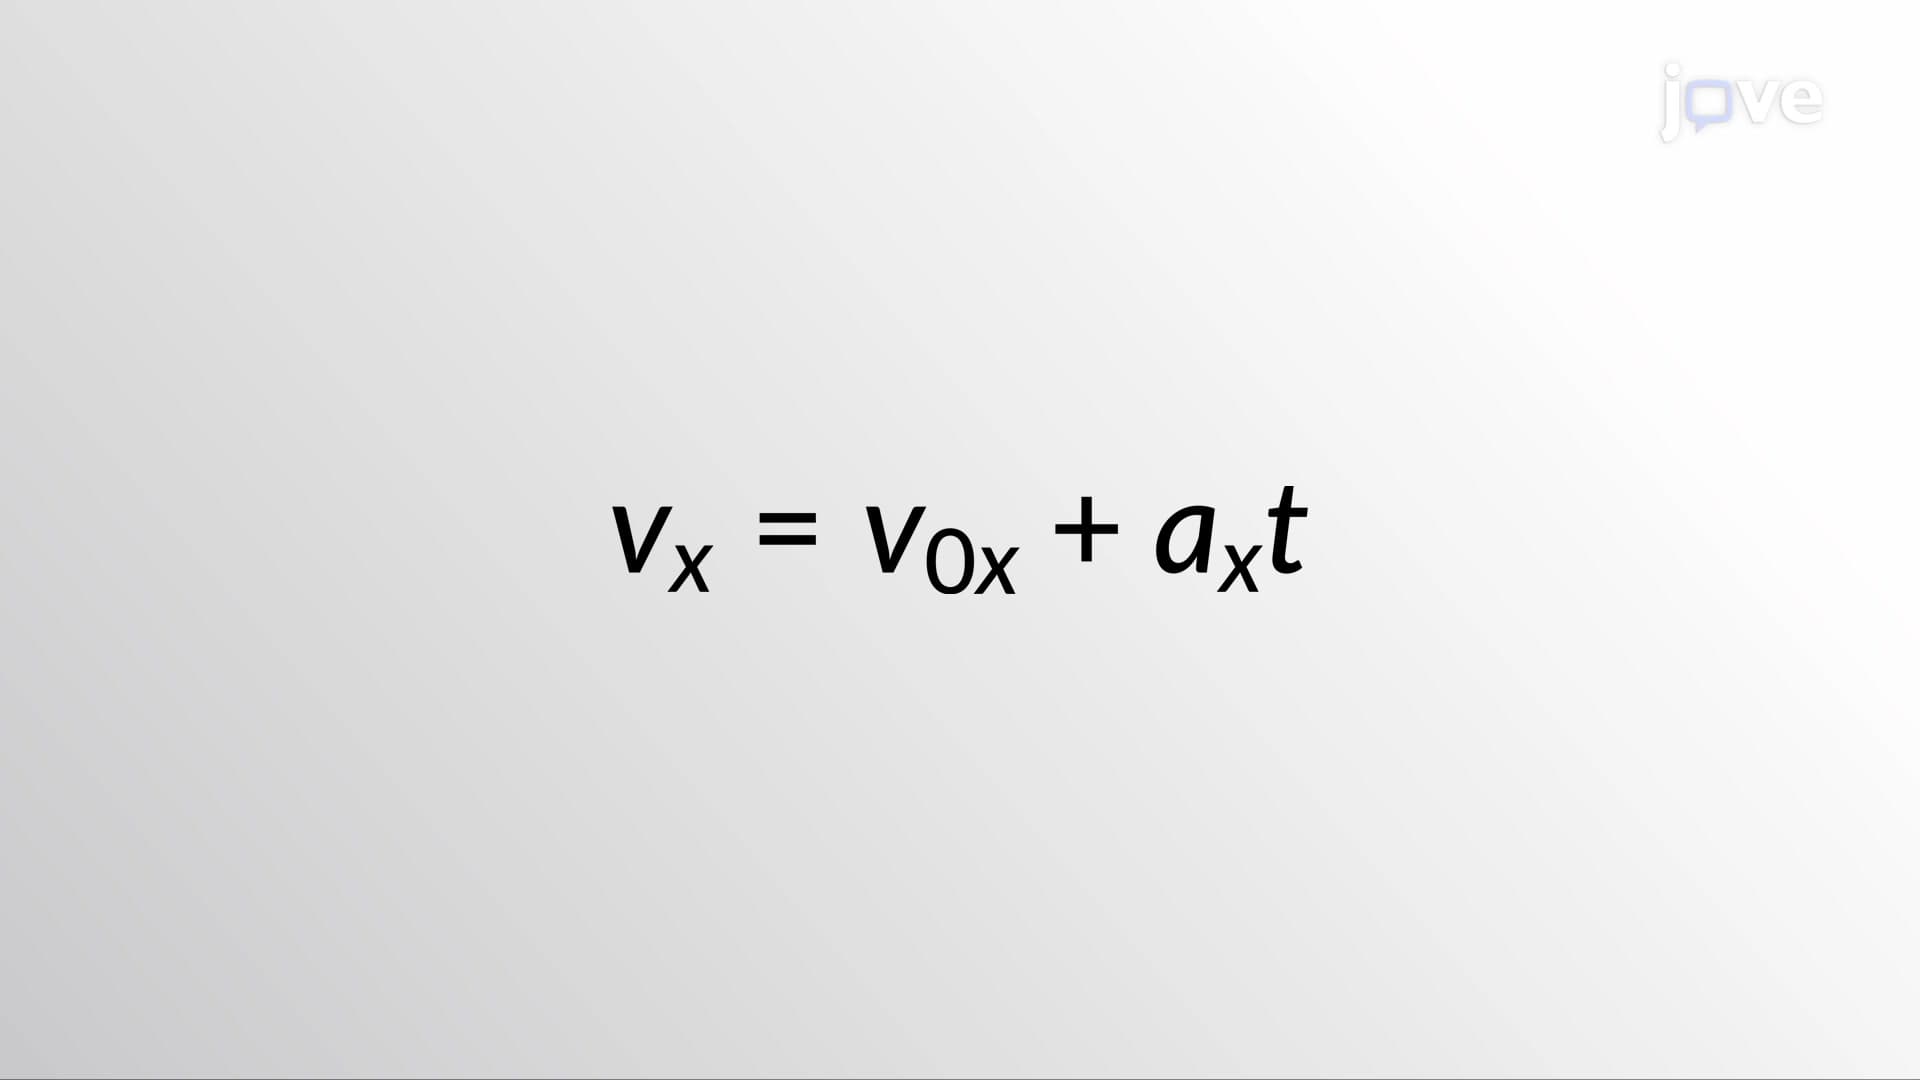 01:26
Kinematic Equations - I